Related Experiment Video
Updated: Aug 17, 2026

Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
Effect of rotational invariance on the monostatic characteristics of matched bodies
Cesar Monzon1, Louis N Medgyesi-Mitschang, Donald W Forester
1SFA, Department NRL, Largo, Maryland 20774, USA.

Abstract:
It is shown analytically and numerically that a matched epsilon = mu reciprocal object with rotational symmetry will not produce any backscattering when illuminated along the axis of symmetry unless the body is invariant un der a rotation by 180 degrees. The purpose of this work is to generalize the monostatic theorem of Weston to arbitrary rotational symmetry, thereby providing a basic rule for scattering by complex bodies. The theory is illustrated by application to a few selected scatterers.
Related Concept Videos
 01:11
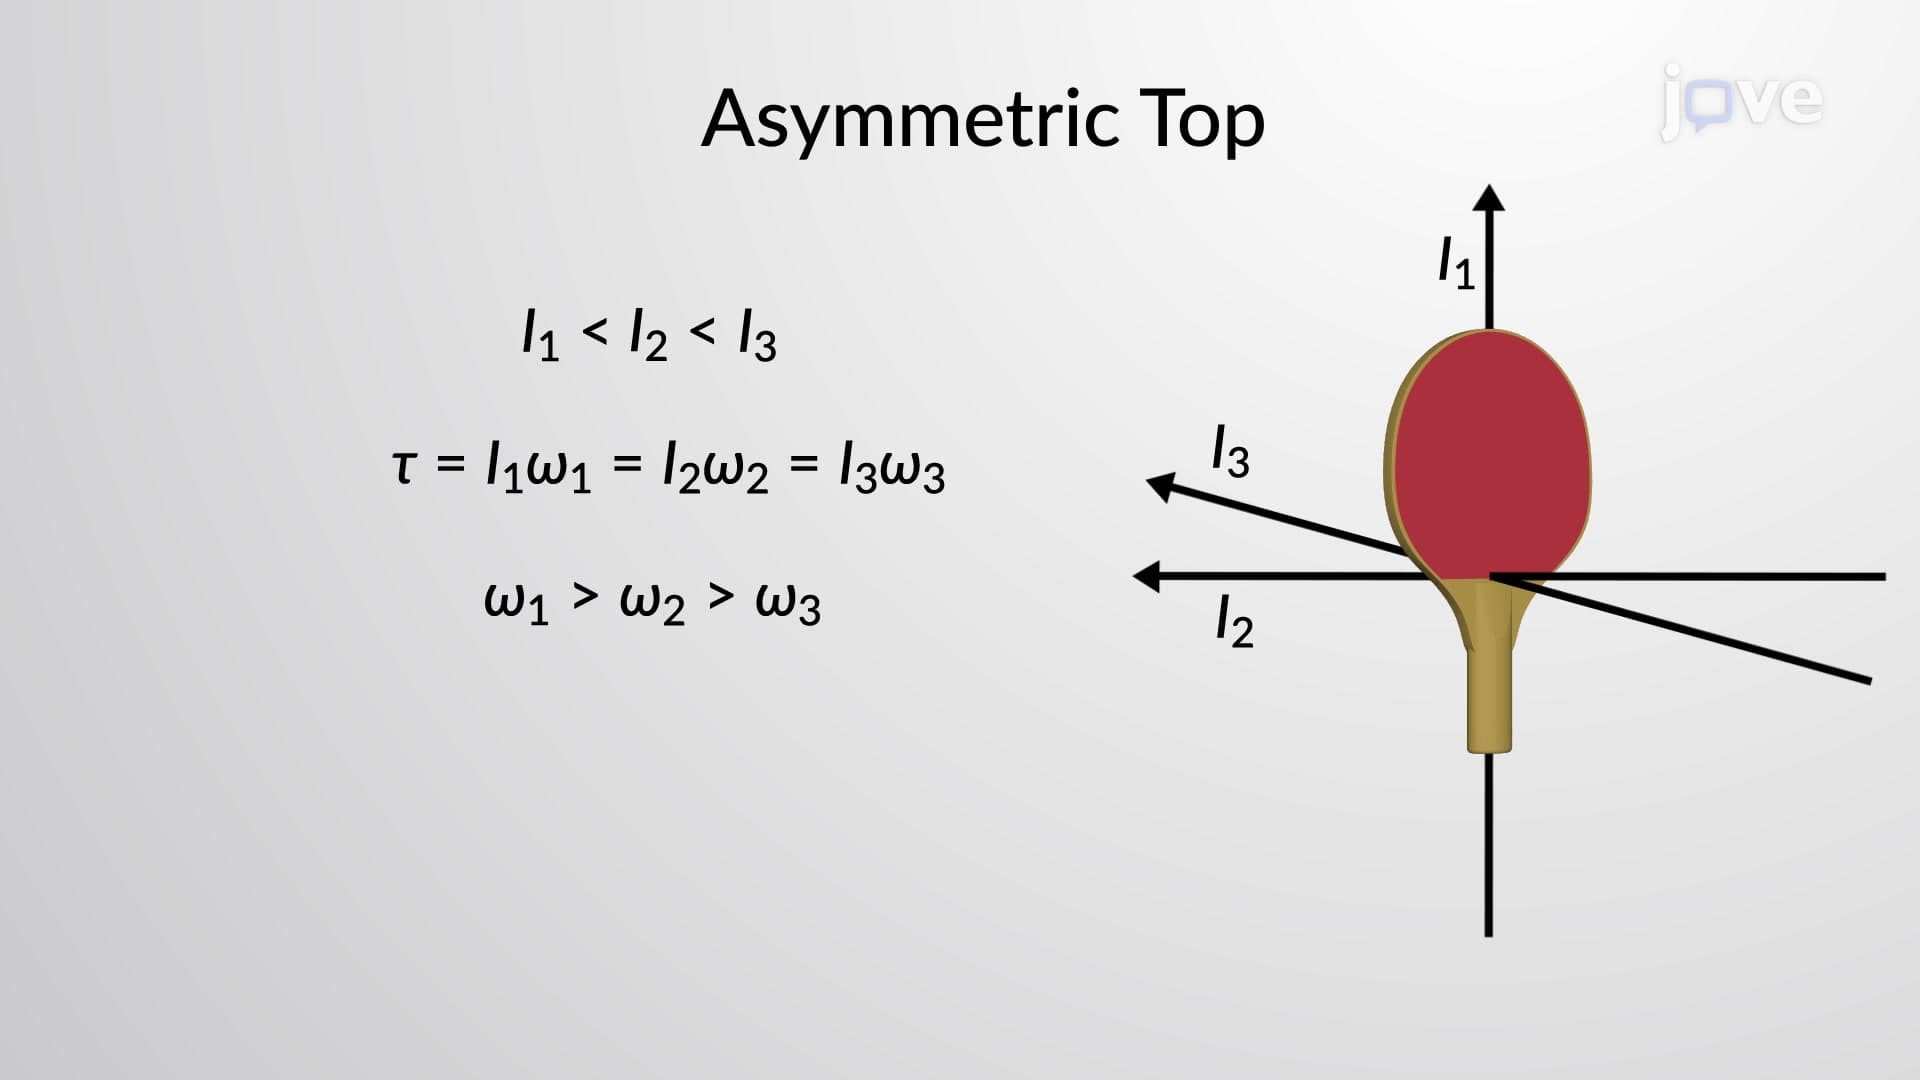
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:14
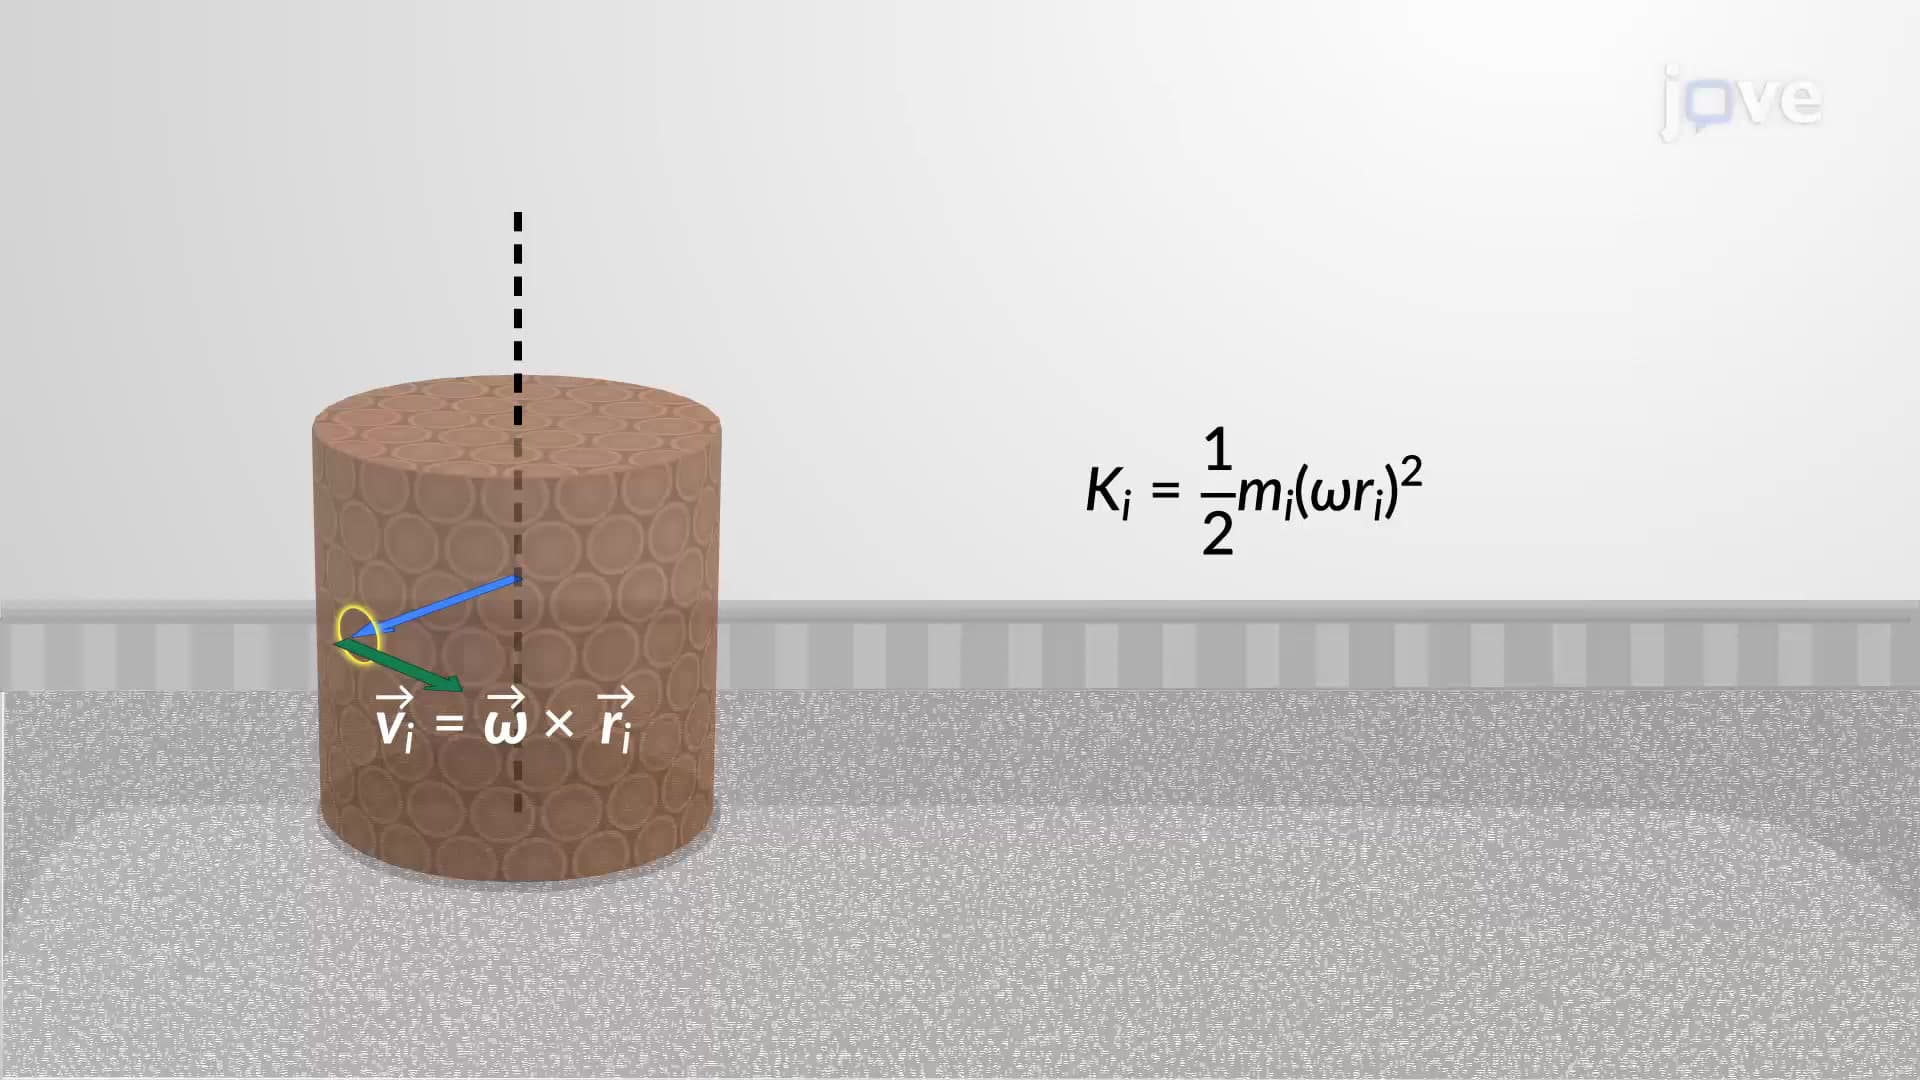
Moment of Inertia
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
 01:19
Euler Equations of Motion
 01:22
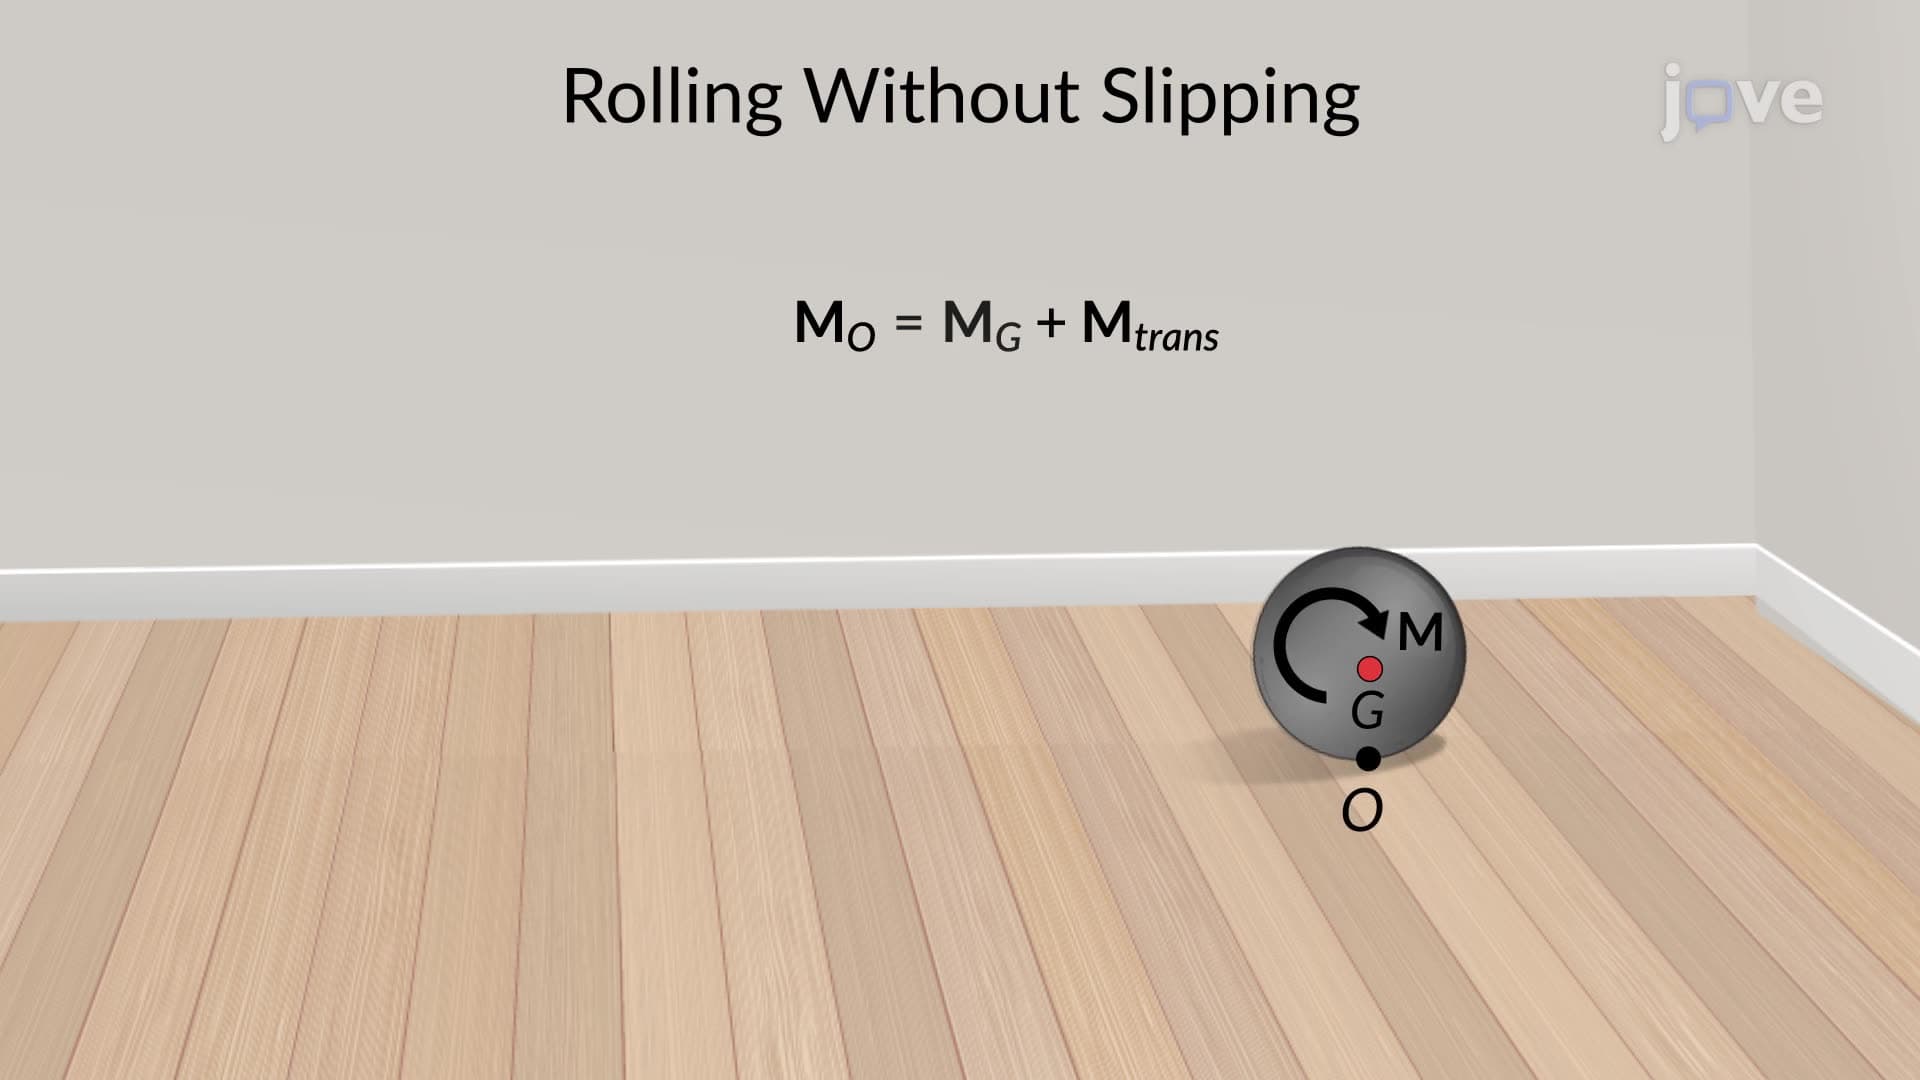
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the product of the...
 00:52
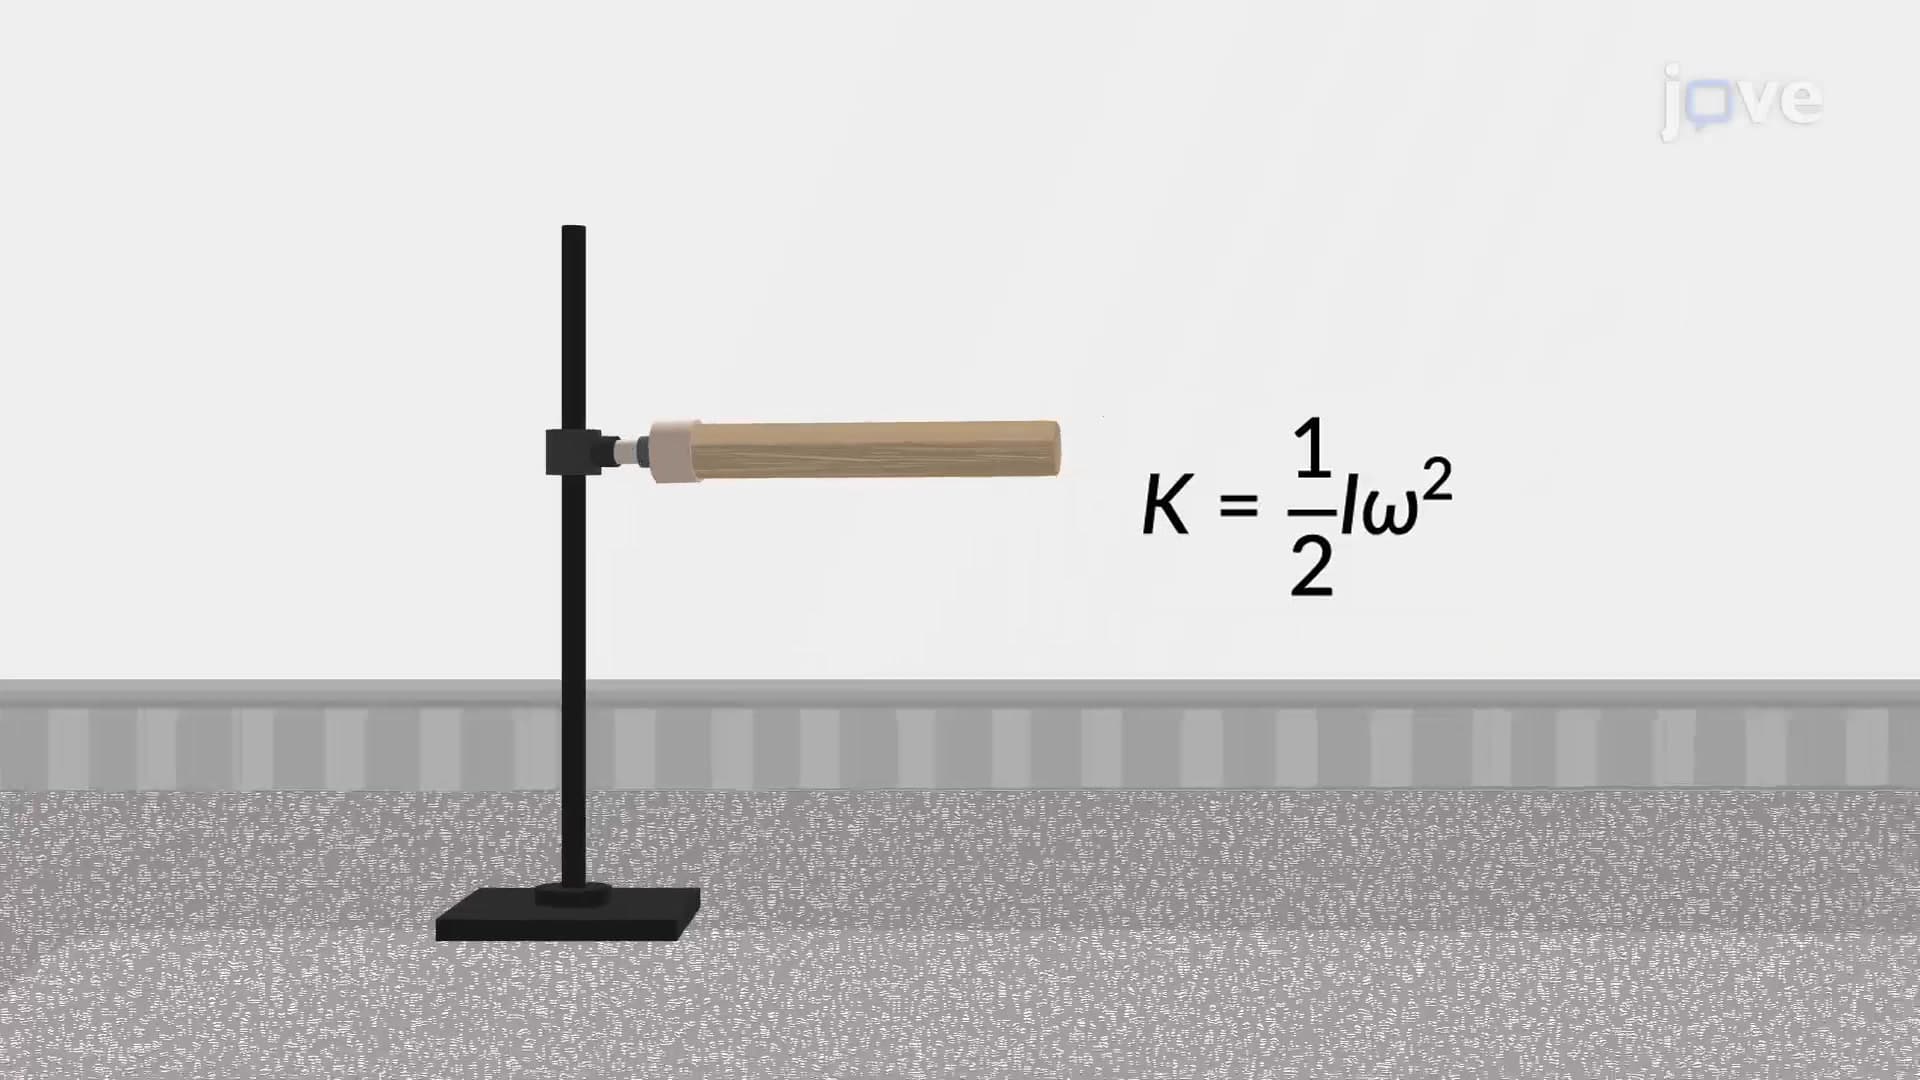
Moment of Inertia and Rotational Kinetic Energy
This relationship between the rotational kinetic energy of a body and its angular speed implies that for the same angular speed, the rotational kinetic energy is greater if its moment of inertia is greater. Thus, more work needs to be done on the body to change its rotational kinetic energy and rotate it at a specific angular speed. Hence, the moment of inertia quantifies the...
 01:05
Static Equilibrium - I