Interlimb and within limb force coordination in static bimanual manipulation task
Related Experiment Video
Updated: Aug 16, 2026
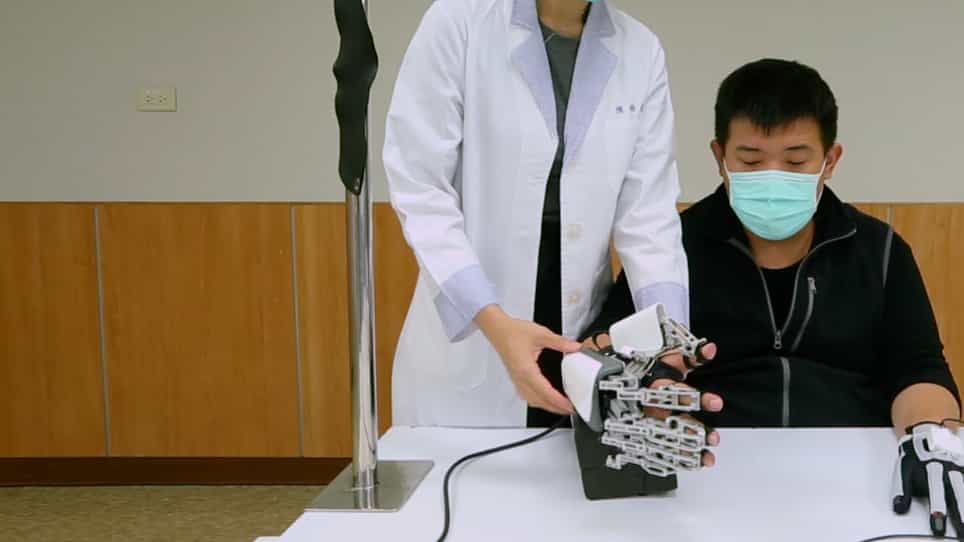
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Slobodan Jaric1, Jeffrey J Collins, Rahul Marwaha
1Department of Health, Nutrition, and Exercise Sciences, Human Performance Lab, University of Delaware, 547 S. College Av., Newark, DE 19716, USA. jaric@udel.edu

Abstract:
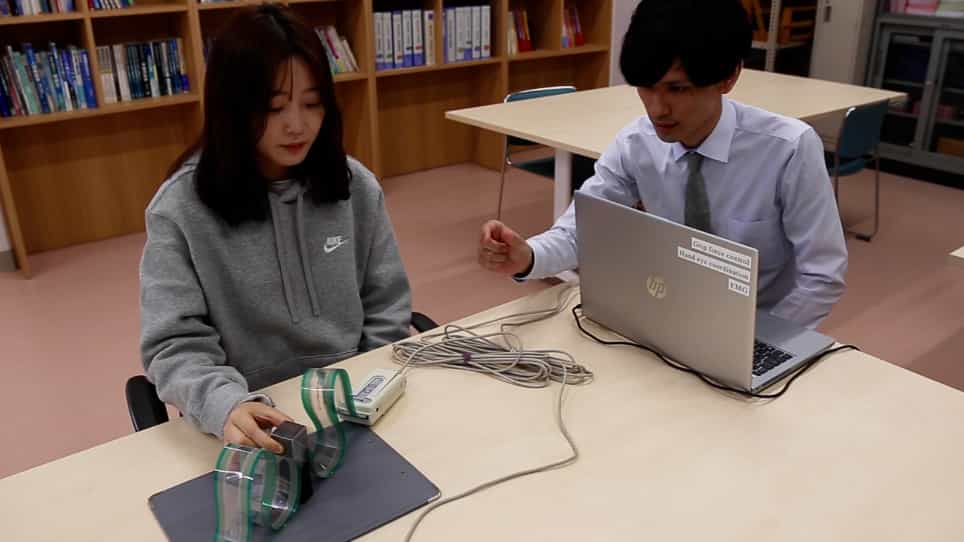
The aim of the study was to compare the coordination of hand grip (G) and load force (a force that tends to cause slippage of a grasped object; L) in static bimanual manipulation tasks with the same data obtained from the similar dynamic tasks. Based on the previous findings obtained from dynamic tasks, it was hypothesized that an increase in the rate of L change would be predominantly associated with a decrease in the coordination of the within limb forces (coordination of G and L of each hand as assessed through the correlation coefficients), while a decrease in coordination of interlimb forces (between two G and two L) will be less pronounced. Regarding the pattern of modulation of G, the same increase in L frequency was also expected to be associated with a decrease in G gain and an increase in G offset (as assessed by slope and intercept of the regression lines obtained from G to L diagrams, respectively), as well as with an increase in average G/L ratio. Subjects exerted oscillatory isometric L profiles by simultaneous pulling out two handles of an externally fixed device under an exceptionally wide range of L frequencies (0.67-3.33 Hz). The results demonstrated relatively high correlation coefficients between both the interlimb and within limb forces that were only moderately affected under sub-maximal L frequencies. Furthermore, the hypothesized changes in G gain and offset appeared only under the highest L frequency, while the G/L ratio remained unaffected. We conclude that, when compared with the dynamic tasks based on the unconstrained movements of hand-held objects that produce similar pattern of L change, the static manipulation tasks demonstrate a consistent and highly coordinated pattern of bilateral G and L under a wide range of frequencies. However, the neural mechanisms that play a role in the revealed differences need further elucidation.
Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...