Interaction model between elastic objects for haptic feedback considering collisions of soft tissue
Related Experiment Video
Updated: Aug 15, 2026

Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Yoshihiro Kuroda1, Megumi Nakao, Tomohiro Kuroda
1Graduate School of Medicine, Kyoto University, Yoshida-Konoe-cho, Sakyo, Kyoto 606-8501, Japan. ykuroda@kuhp.kyoto-u.ac.jp

Abstract:
The simulation of organ-organ interaction is indispensable for practical and advanced medical VR simulator such as open surgery and indirect palpation. This paper describes a method to represent real-time interaction between elastic objects for accurate force feedback in medical VR simulation. The proposed model defines boundary deformation of colliding elements based on temporary surface forces calculated by temporary deformation. The model produces accurate deformation and force feedback considering collisions of objects as well as prevents unrealistic overlap of objects. A prototype simulator of rectal palpation is constructed on general desktop PC with a haptic device, PHANToM. The system allows users to feel different stiffness of a rear elastic object located behind another elastic object. The results of experiments confirmed the method expresses organ-organ interaction in real-time and produces realistic and perceivable force feedback.
Related Concept Videos
 01:00
Elastic Collisions: Introduction
 01:15
Elastic Collisions: Case Study
 01:04
Types Of Collisions - I
 01:19
Types of Collisions - II
 01:30
Impact
When particles with different initial velocities collide, they induce deformation by applying equal and opposite impulses. At the point of maximum deformation, the particles move together with...
 01:12
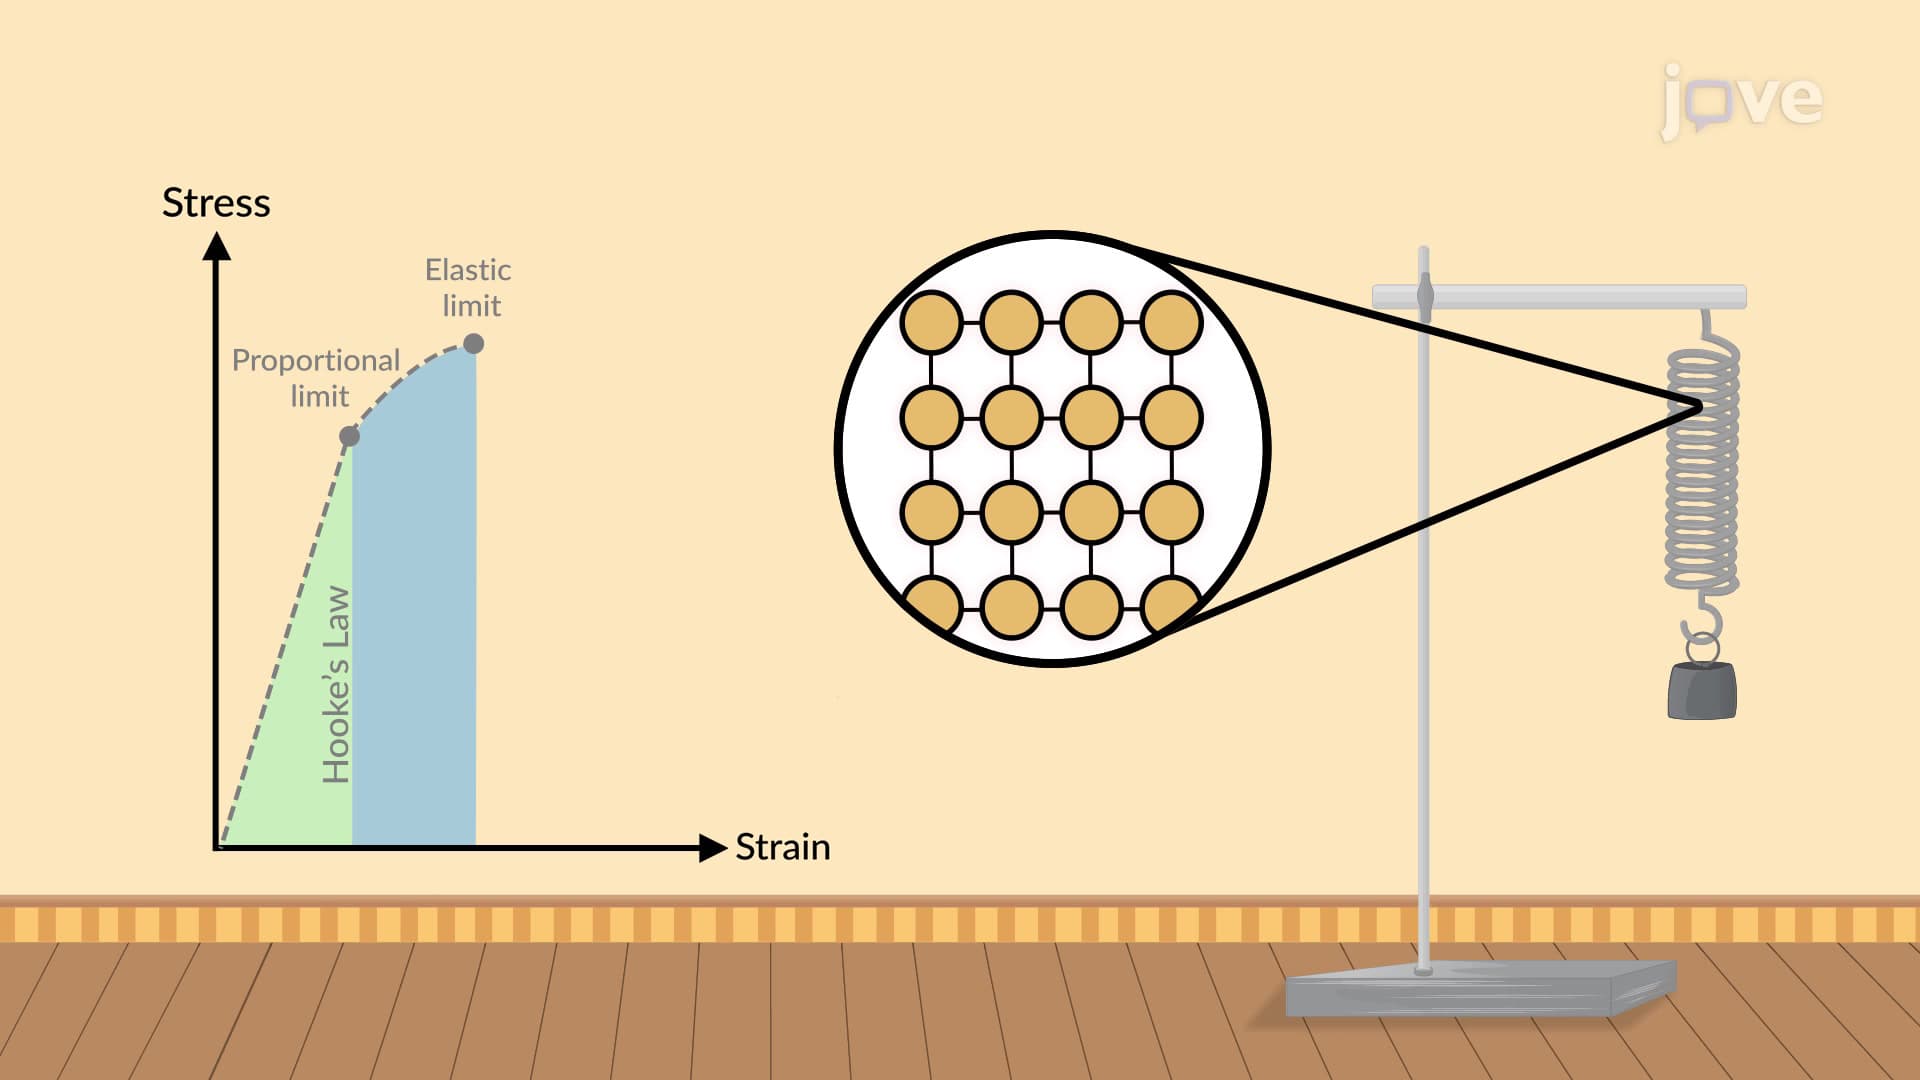
Elasticity
The elasticity of an object can be described by a stress-strain curve, which represents the relationship between stress...