Related Experiment Video
Updated: Aug 15, 2026


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
A control theory approach to the analysis and synthesis of the experimentally observed motion primitives
Francesco Nori1, Ruggero Frezza
1Department of Information Engineering, Universitá degli Studi di Padova, 35131 Padova, Italy. iron@dei.unipd.it

Abstract:
Recent experiments on frogs and rats, have led to the hypothesis that sensory-motor systems are organized into a finite number of linearly combinable modules; each module generates a motor command that drives the system to a predefined equilibrium. Surprisingly, in spite of the infiniteness of different movements that can be realized, there seems to be only a handful of these modules. The structure can be thought of as a vocabulary of "elementary control actions". Admissible controls, which in principle belong to an infinite dimensional space, are reduced to the linear vector space spanned by these elementary controls. In the present paper we address some theoretical questions that arise naturally once a similar structure is applied to the control of nonlinear kinematic chains. First of all, we show how to choose the modules so that the system does not loose its capability of generating a "complete" set of movements. Secondly, we realize a "complete" vocabulary with a minimal number of elementary control actions. Subsequently, we show how to modify the control scheme so as to compensate for parametric changes in the system to be controlled. Remarkably, we construct a set of modules with the property of being invariant with respect to the parameters that model the growth of an individual. Robustness against uncertainties is also considered showing how to optimally choose the modules equilibria so as to compensate for errors affecting the system. Finally, the motion primitive paradigm is extended to locomotion and a related formalization of internal (proprioceptive) and external (exteroceptive) variables is given.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:20
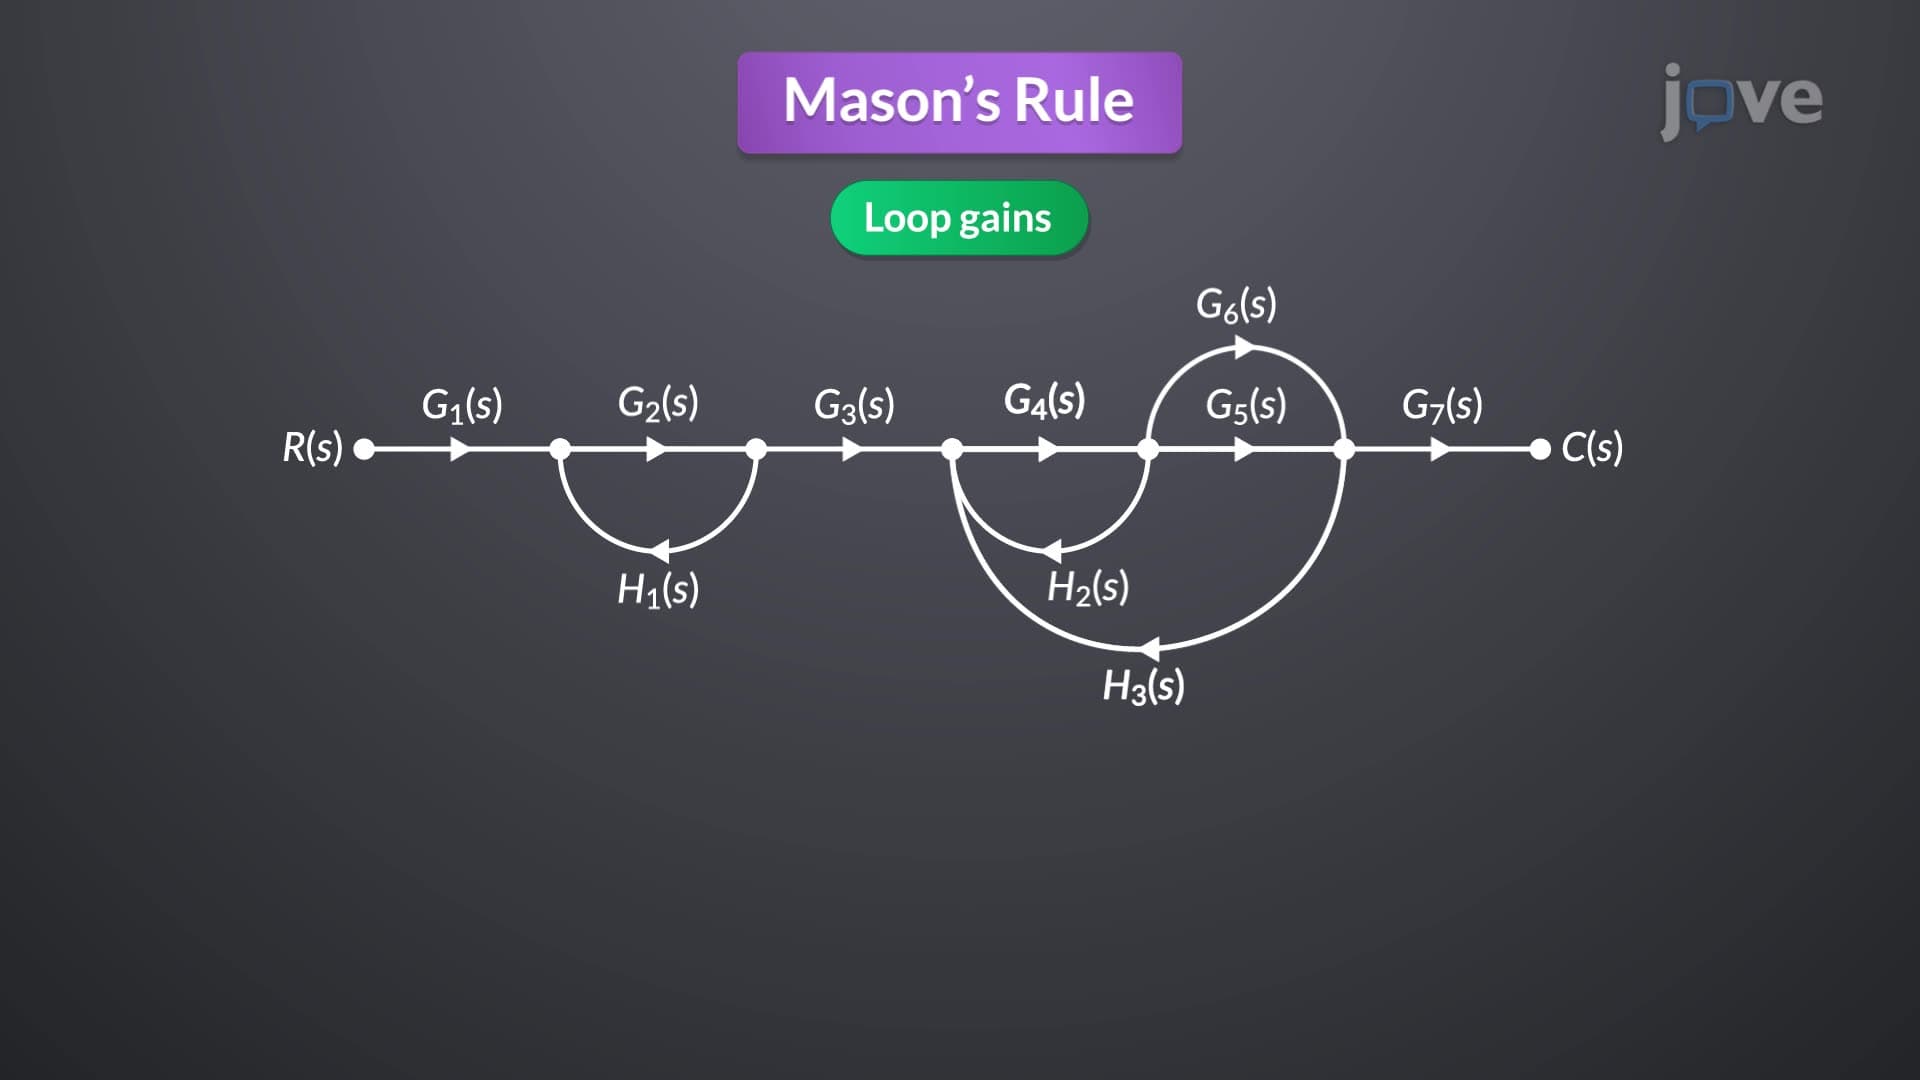
Mason's Rule
Loop gain is determined by identifying and tracing a path from a node back to itself. This involves computing the product of branch gains along the loop. Each loop's gain is crucial for further...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...