Direct volumetric rendering based on point primitives in OpenGL

André Luiz Miranda da Rosa1, Ilana de Almeida Souza, Adilson Yuuji Hira

  • 1EPUSP - Escola Politécnica da USP - Engenharia Elétrica - LSI (Laboratório de Sistemas Integráveis, São Paulo-SP-Brasil. amiranda@lsi.usp.br

Related Concept Videos

Theorems of Pappus and Guldinus: Problem Solving01:12

Theorems of Pappus and Guldinus: Problem Solving
Pappus and Guldinus's theorems are powerful mathematical principles that are used for finding the surface area and volume of composite shapes. For example, consider a cylindrical storage tank with a conical top. Finding the surface area or volume can be challenging for such complex shapes. These theorems are particularly useful in calculating the volume and surface area of such systems. Here, the cylindrical storage tank with a conical top can be broken down into two simple shapes: a cylinder...
Volumes of Solids of Revolution01:29

Volumes of Solids of Revolution

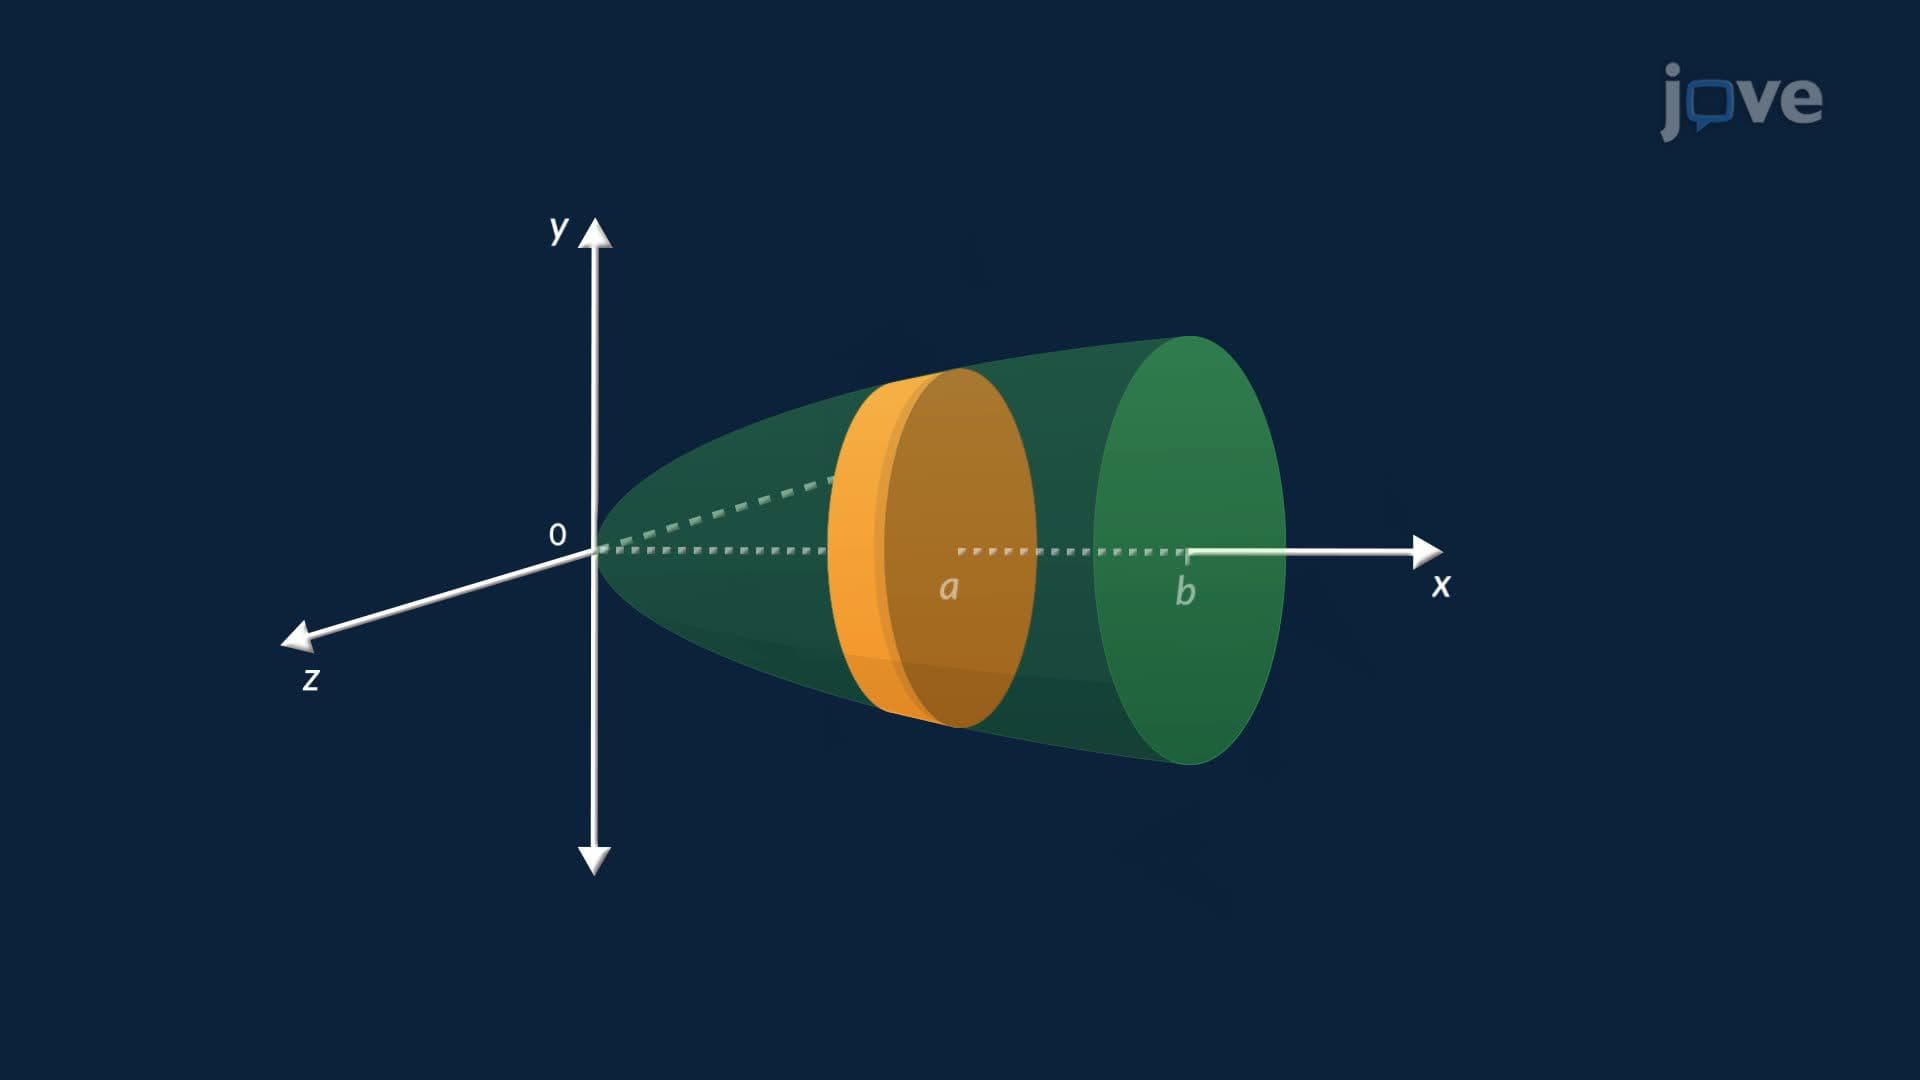
Volumes of irregularly shaped objects can be systematically determined using the concept of solids of revolution. This approach begins with a region defined by a curve in a two-dimensional plane. When this region is rotated about a fixed line, known as the axis of revolution, it generates a three-dimensional object with rotational symmetry. Such objects frequently arise in mathematical modeling, physics, and engineering applications.When the region being rotated lies directly against the axis...
Divergence Theorem in 3D Space01:20

Divergence Theorem in 3D Space

In vector calculus, flux measures the total flow of a vector field through a surface. For a closed surface in three-dimensional space, this means measuring how much of the field passes outward through every point on the boundary. Directly calculating this flux can be difficult when the surface has a complicated or irregular shape. The Divergence Theorem provides a powerful alternative by relating surface flux to behavior inside the enclosed region.The Divergence Theorem states that the outward...
Parametric Surfaces01:30

Parametric Surfaces

A parametric surface in three-dimensional space is defined through a vector-valued function\begin{equation*}\mathbf{r}(u, v) = x(u, v)\mathbf{i} + y(u, v)\mathbf{j} + z(u, v)\mathbf{k}\end{equation*}where u and v are parameters within a specified domain D in the uv-plane. The functions x(u, v), y(u, v), and z(u, v) define the coordinates of points on the surface. As u and v vary over D, the position vector r(u, v) traces a continuous surface in space. This parametric representation is essential...
Finding Volume Using Cross-Sectional Area01:25

Finding Volume Using Cross-Sectional Area
For solids whose cross-sectional areas vary in a predictable way, volume can be determined by integrating these areas along an axis perpendicular to the slices. This approach is particularly useful for polyhedral solids, where classical geometric formulas may not be immediately applicable. A tetrahedron provides a clear example of how cross-sectional integration can be applied to a three-dimensional object with continuously changing geometry.Consider a tetrahedron with height h and a base that...
Cylinders in Three-Dimensional Space01:28

Cylinders in Three-Dimensional Space

A cylindrical surface is generated when a two-dimensional profile curve is translated along a straight line in three-dimensional space. The translated copies of the curve form a surface composed of parallel rulings, each oriented in the same fixed direction. This construction allows many three-dimensional forms to be described using relatively simple planar equations.In Cartesian coordinates, a cylindrical surface is often recognized by an equation that omits one of the three variables. For...