Related Experiment Video
Updated: Aug 13, 2026
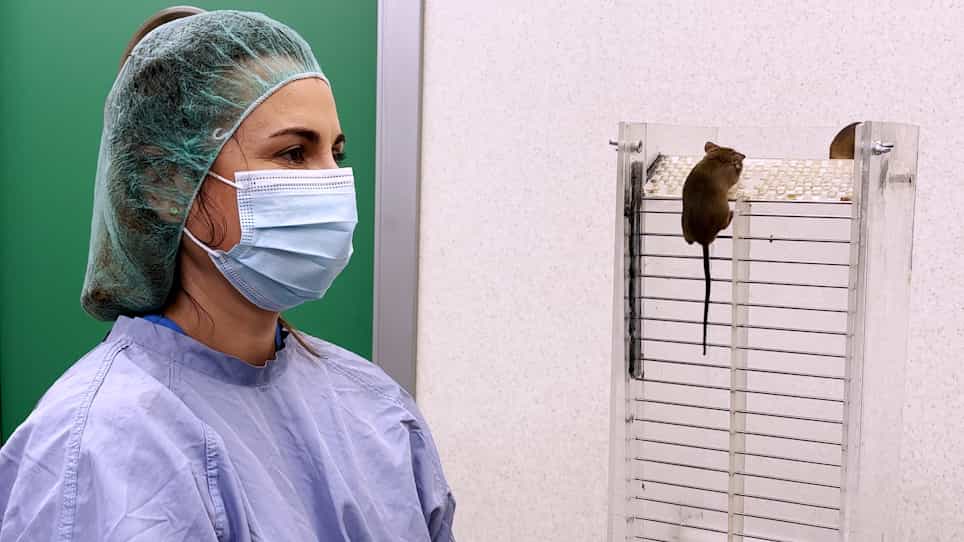

Versatility of Protocols for Resistance Training and Assessment Using Static and Dynamic Ladders in Animal Models
Published on: December 17, 2021
Kinematics of vertical climbing in lorises and Cheirogaleus medius
1Duke University Medical Center, Department of Biological Anthropology and Anatomy, Box 3170, DUMC, Sands Bldg., Durham, NC 27710, USA. jbh6@duke.edu

Abstract:
The type of climbing exhibited by apes and atelines is argued to have been important in the evolution of specialized locomotion, such as suspensory locomotion and bipedalism. However, little is known about the mechanics of climbing in primates. Previous work shows that Asian apes and atelines use larger joint excursions and longer strides than African apes and the Japanese macaque, respectively. This study expands knowledge of climbing mechanics by providing the first quantitative kinematic data for vertical climbing in four prosimian species: three lorisid species (Loris tardigradus, Nycticebus coucang, and Nycticebus pygmaeus) that share with apes and atelines morphological traits arguably related to climbing, and a more generalized quadruped, Cheirogaleus medius. Subjects were videotaped as they climbed up a wooden pole. Kinematic values, such as step length and limb excursions, were calculated and compared between species. The results of this study show that lorises, like Asian apes and spider monkeys, use relatively larger joint excursions and longer steps than does C. medius during climbing. These data lend further support to the idea that some primate species (e.g., lorises, atelines, and apes) are more specialized kinematically and morphologically for climbing than others. Pilot data suggest that such kinematic differences in climbing style across broad phylogenetic groups may relate to the energetics of climbing. Such data may be important for understanding the morphological and kinematic adaptations to climbing exhibited by some primates.

Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:23
Vertical Curve: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...