Related Experiment Video
Updated: Aug 7, 2026

Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
An oscillatory neural model of multiple object tracking
Yakov Kazanovich1, Roman Borisyuk
1Institute of Mathematical Problems in Biology, Russian Academy of Sciences Pushchino, Moscow Region, 142290, Russia. yakov_k@impb.psn.ru

Abstract:
An oscillatory neural network model of multiple object tracking is described. The model works with a set of identical visual objects moving around the screen. At the initial stage, the model selects into the focus of attention a subset of objects initially marked as targets. Other objects are used as distractors. The model aims to preserve the initial separation between targets and distractors while objects are moving. This is achieved by a proper interplay of synchronizing and desynchronizing interactions in a multilayer network, where each layer is responsible for tracking a single target. The results of the model simulation are presented and compared with experimental data. In agreement with experimental evidence, simulations with a larger number of targets have shown higher error rates. Also, the functioning of the model in the case of temporarily overlapping objects is presented.
More Related Videos
 07:34
Utilizing vmTracking to Improve the Accuracy of Multi-Animal Pose Estimation in Rodent Social Behavior Studies
Published on: November 7, 2025
 07:24
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Related Concept Videos
 01:26
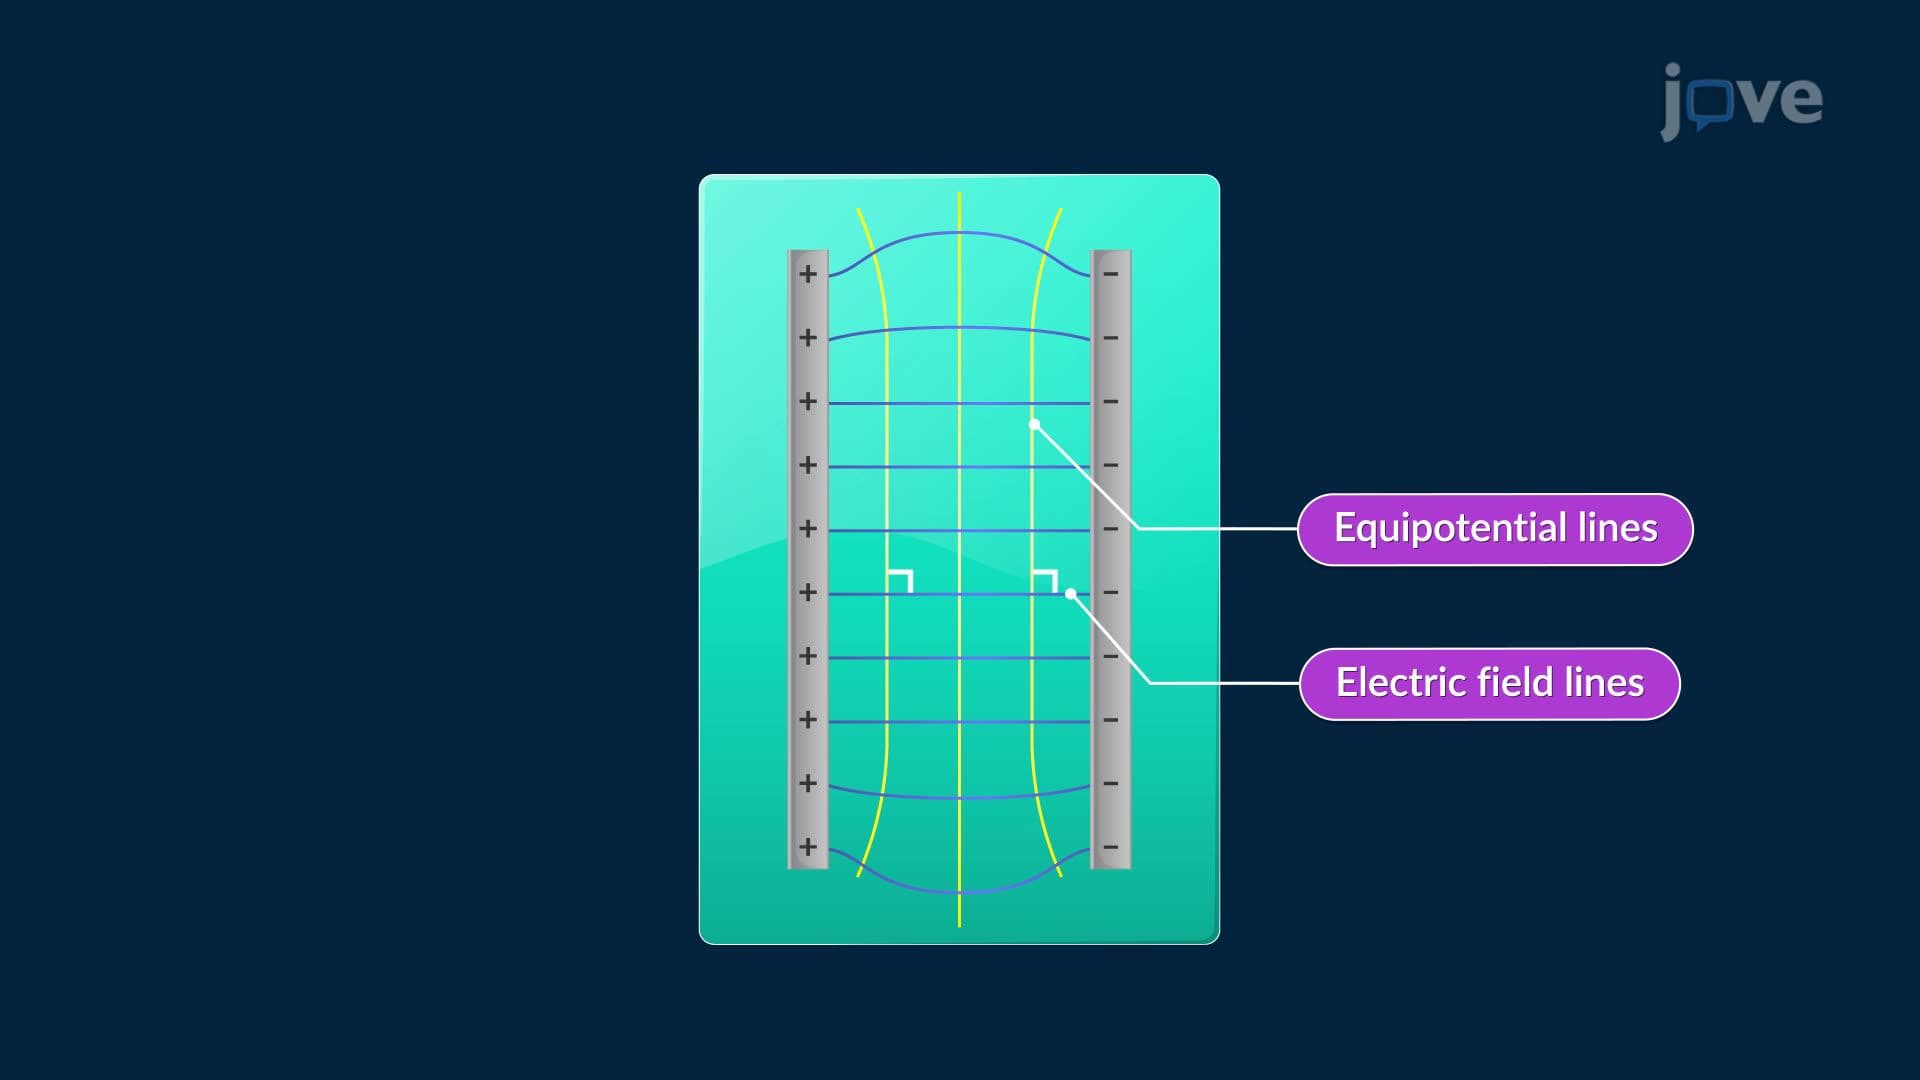
Orthogonal Trajectories
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...