Related Experiment Video
Updated: Aug 6, 2026


Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
A control scheme for stable force-reflecting teleoperation over IP networks

Abstract:
The problem of force-reflecting teleoperation over Internet protocol networks is addressed. The existence of time-varying communication delay and the possibility of data losses are taken into consideration. Since significant data loss may result in discontinuity of the reference trajectory transmitted through the communication channel, the proposed control scheme includes a filter that provides a smooth approximation of a possibly discontinuous reference trajectory. The stability of the overall system is guaranteed by a version of the input-to-output stable small-gain theorem for functional differential equations. If the communication delay in the forward channel is an "approximately smooth" function of time, the proposed scheme guarantees that the slave manipulator tracks the delayed trajectory of the master within a prescribed small error.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:30
Three-Dimensional Force System
 01:21
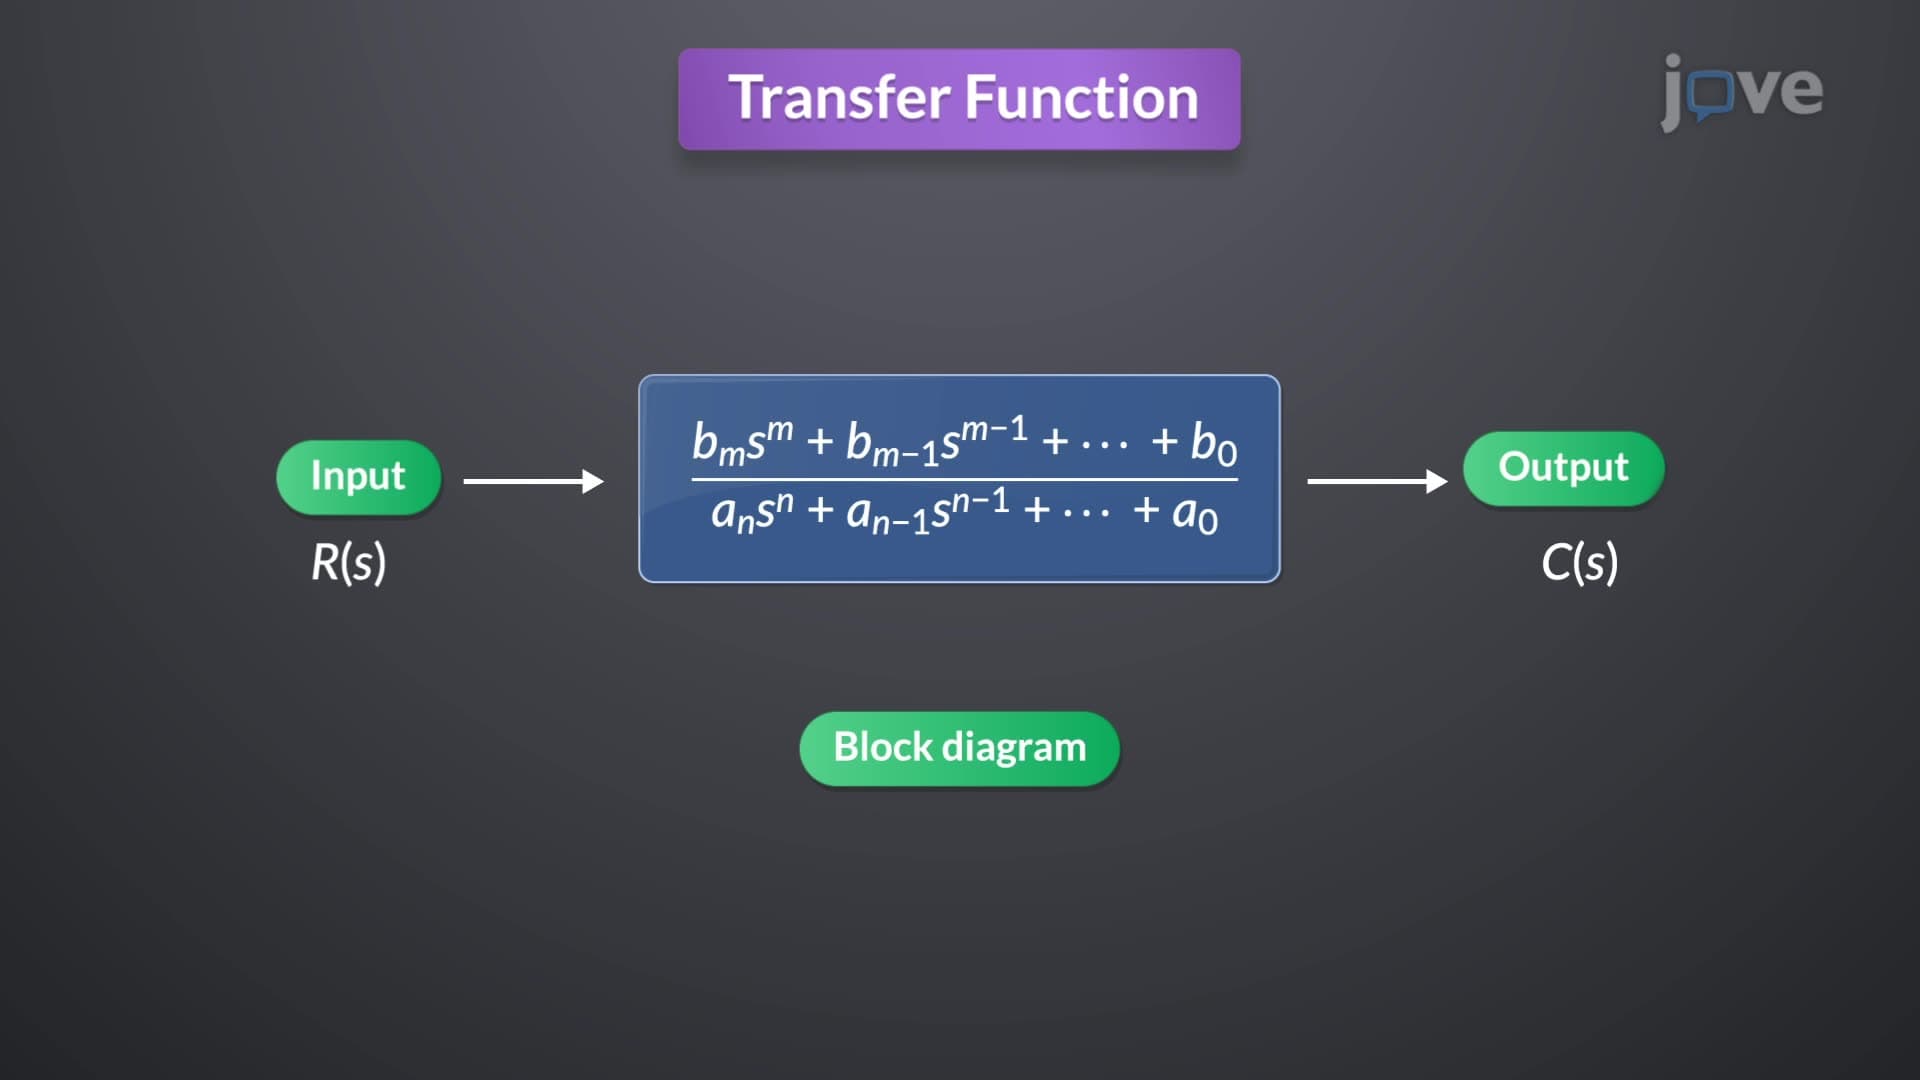
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:10
Control Systems
At the heart...