Related Experiment Video
Updated: Aug 6, 2026

Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
A nonlinear approach to tracking slow-time-scale changes in movement kinematics
Jonathan B Dingwell1, Domenic F Napolitano, David Chelidze
1Nonlinear Biodynamics Laboratory, Department of Kinesiology, University of Texas at Austin, 1 University Station, D3700, Austin, TX 78712, USA. jdingwell@mail.utexas.edu

Abstract:
Degenerative processes like repetitive strain injuries (RSIs) cause normal movement patterns to change slowly over time. Accurately tracking how these disease/injury processes evolve over time and predicting their future progression could allow early intervention and prevent further deterioration. However, these processes often cannot be measured directly and first-principles models of these processes and how they affect movement control are highly complex and difficult to derive analytically. This study was conducted to determine if algorithms developed to track damage accumulation in mechanical systems without requiring first-principles models or direct measurements of the damage itself could also track a similar "hidden" process in a biomechanical context. Five healthy adults walked on a motorized treadmill at their preferred speed, while the treadmill inclination angle was slowly increased from 0 degrees (level) to approximately +8 degrees . Sagittal plane kinematics for the left hip, knee, and ankle joints were computed. The treadmill inclination angle was independently recorded and defined the "damage" to be tracked. Scalar tracking metrics were computed from the lower extremity walking kinematics. These metrics exhibited strong cubic relationships with treadmill inclination (88.9%
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:15
Kinematic Equations: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
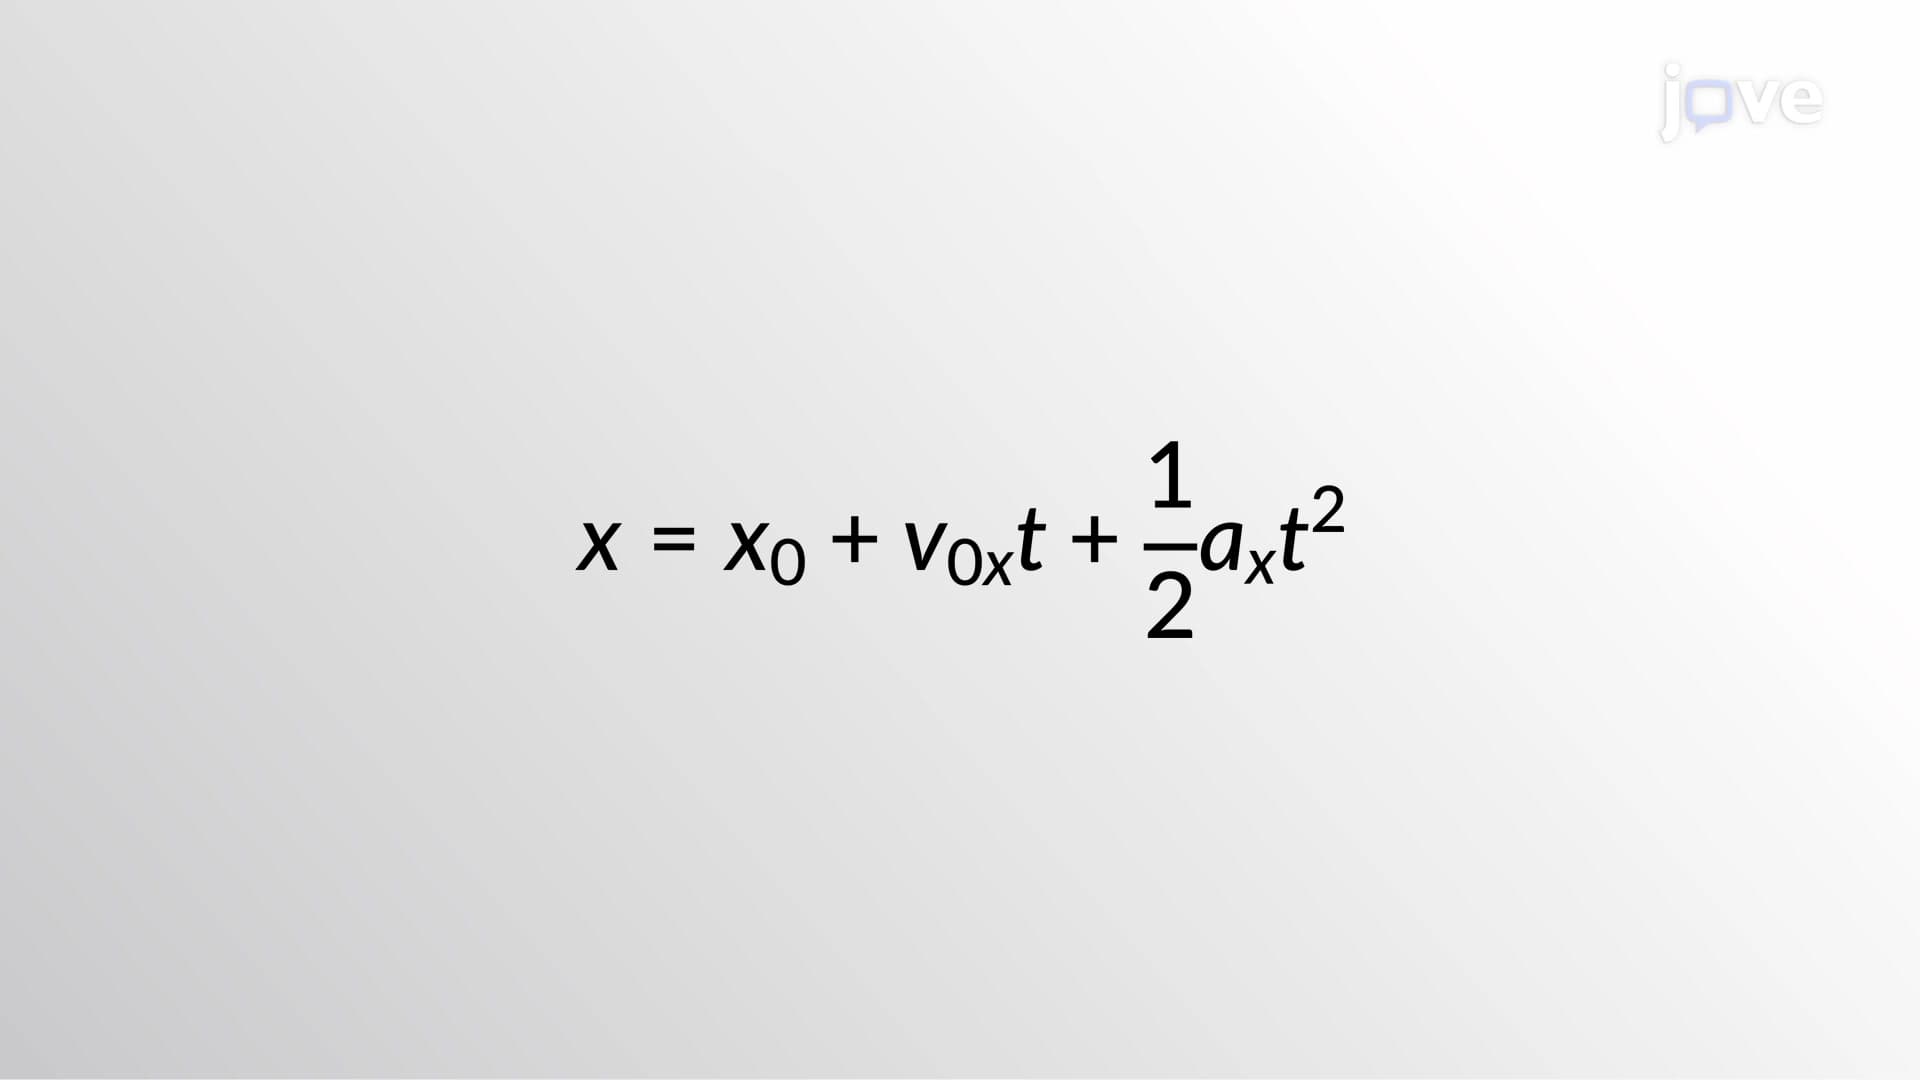 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:18
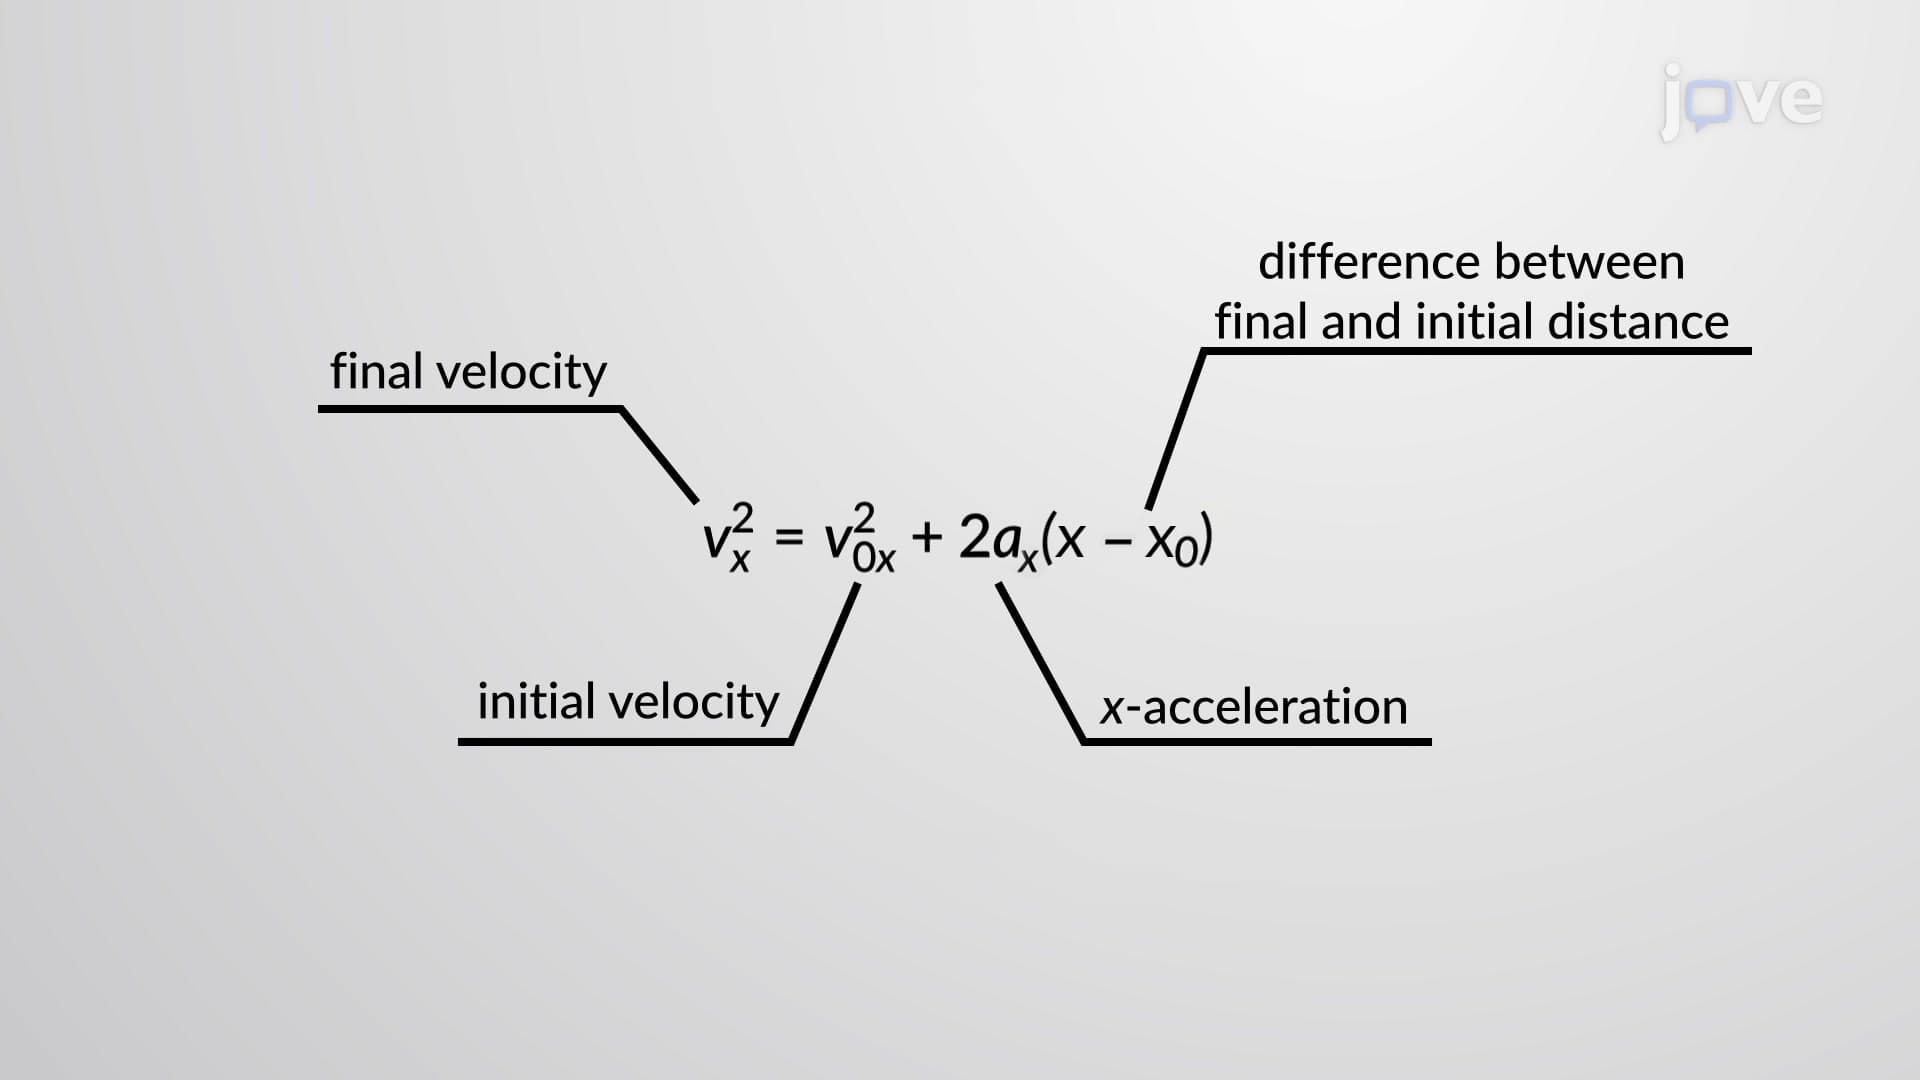
Kinematic Equations - III
Using the kinematic equations,...