Related Experiment Video
Updated: Jul 19, 2026
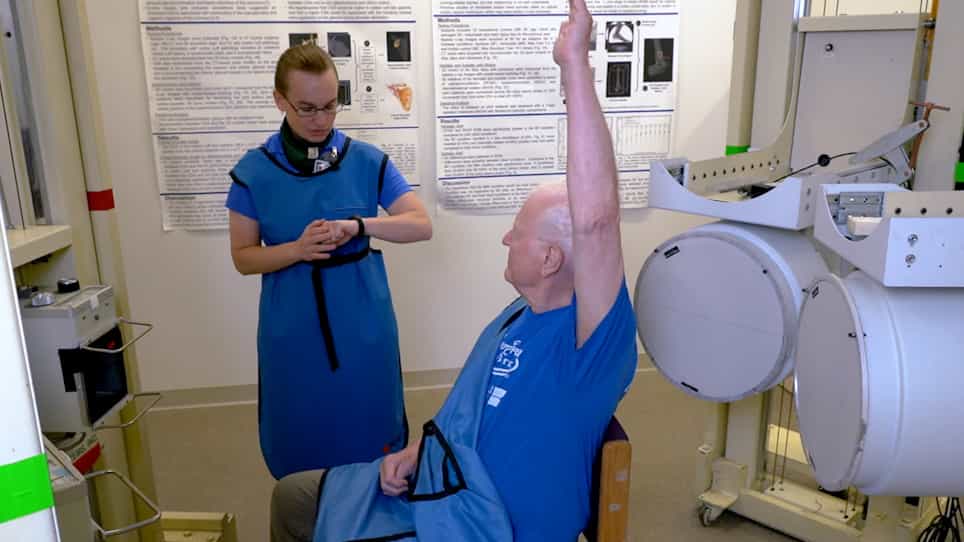

Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Kinematic invariants during cyclical arm movements
1Movement Control and Biomechanics Lab, Department of Kinesiology, Arizona State University, Tempe, AZ, 85287-0404, USA. natalia.dounskaia@asu.edu

Abstract:
It has been observed that the motion of the arm end-point (the hand, fingertip or the tip of a pen) is characterized by a number of regularities (kinematic invariants). Trajectory is usually straight, and the velocity profile has a bell shape during point-to-point movements. During drawing movements, a two-thirds power law predicts the dependence of the end-point velocity on the trajectory curvature. Although various principles of movement organization have been discussed as possible origins of these kinematic invariants, the nature of these movement trajectory characteristics remains an open question. A kinematic model of cyclical arm movements derived in the present study analytically demonstrates that all three kinematic invariants can be predicted from a two-joint approximation of the kinematic structure of the arm and from sinusoidal joint motions. With this approach, explicit expressions for two kinematic invariants, the two-thirds power law during drawing movements and the velocity profile during point-to-point movements are obtained as functions of arm segment lengths and joint motion parameters. Additionally, less recognized kinematic invariants are also derived from the model. The obtained analytical expressions are further validated with experimental data. The high accuracy of the predictions confirms practical utility of the model, showing that the model is relevant to human performance over a wide range of movements. The results create a basis for the consolidation of various existing interpretations of kinematic invariants. In particular, optimal control is discussed as a plausible source of invariant characteristics of joint motions and movement trajectories.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
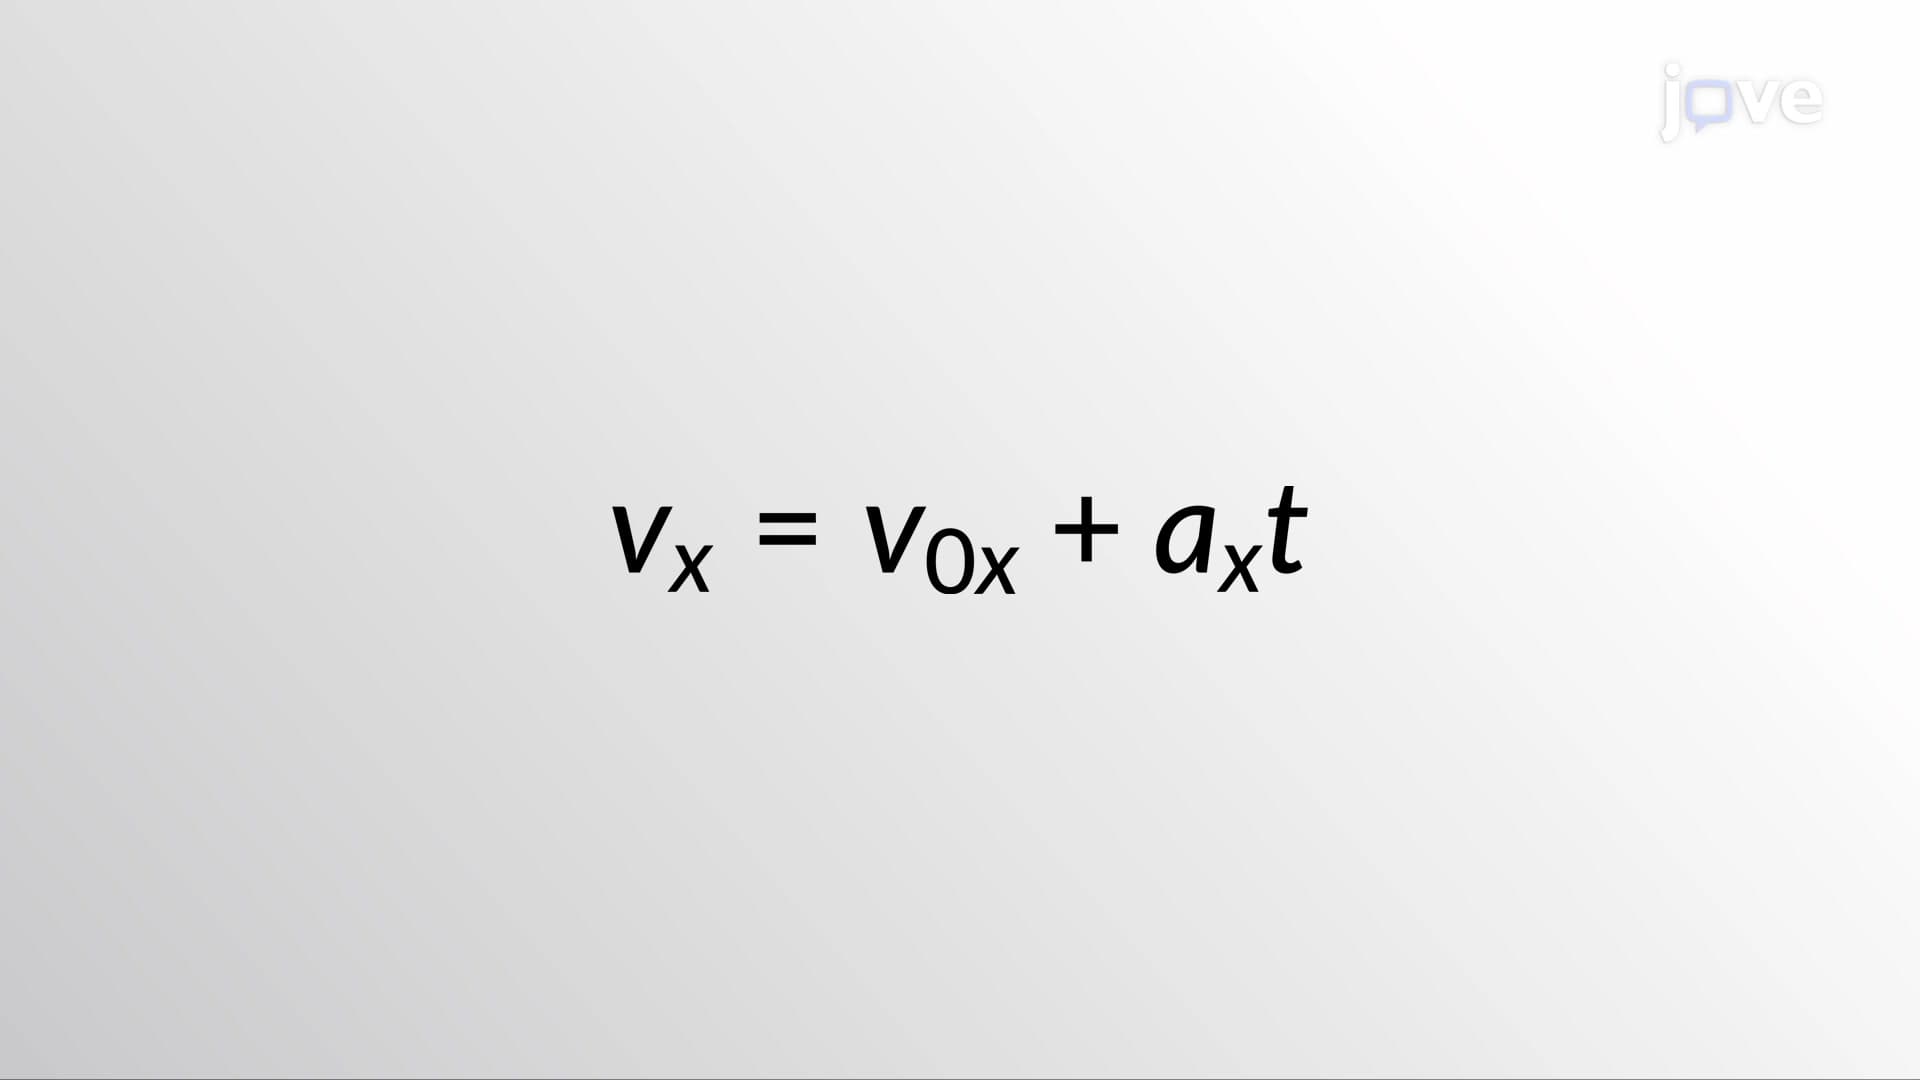 01:26
Kinematic Equations - I
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:16
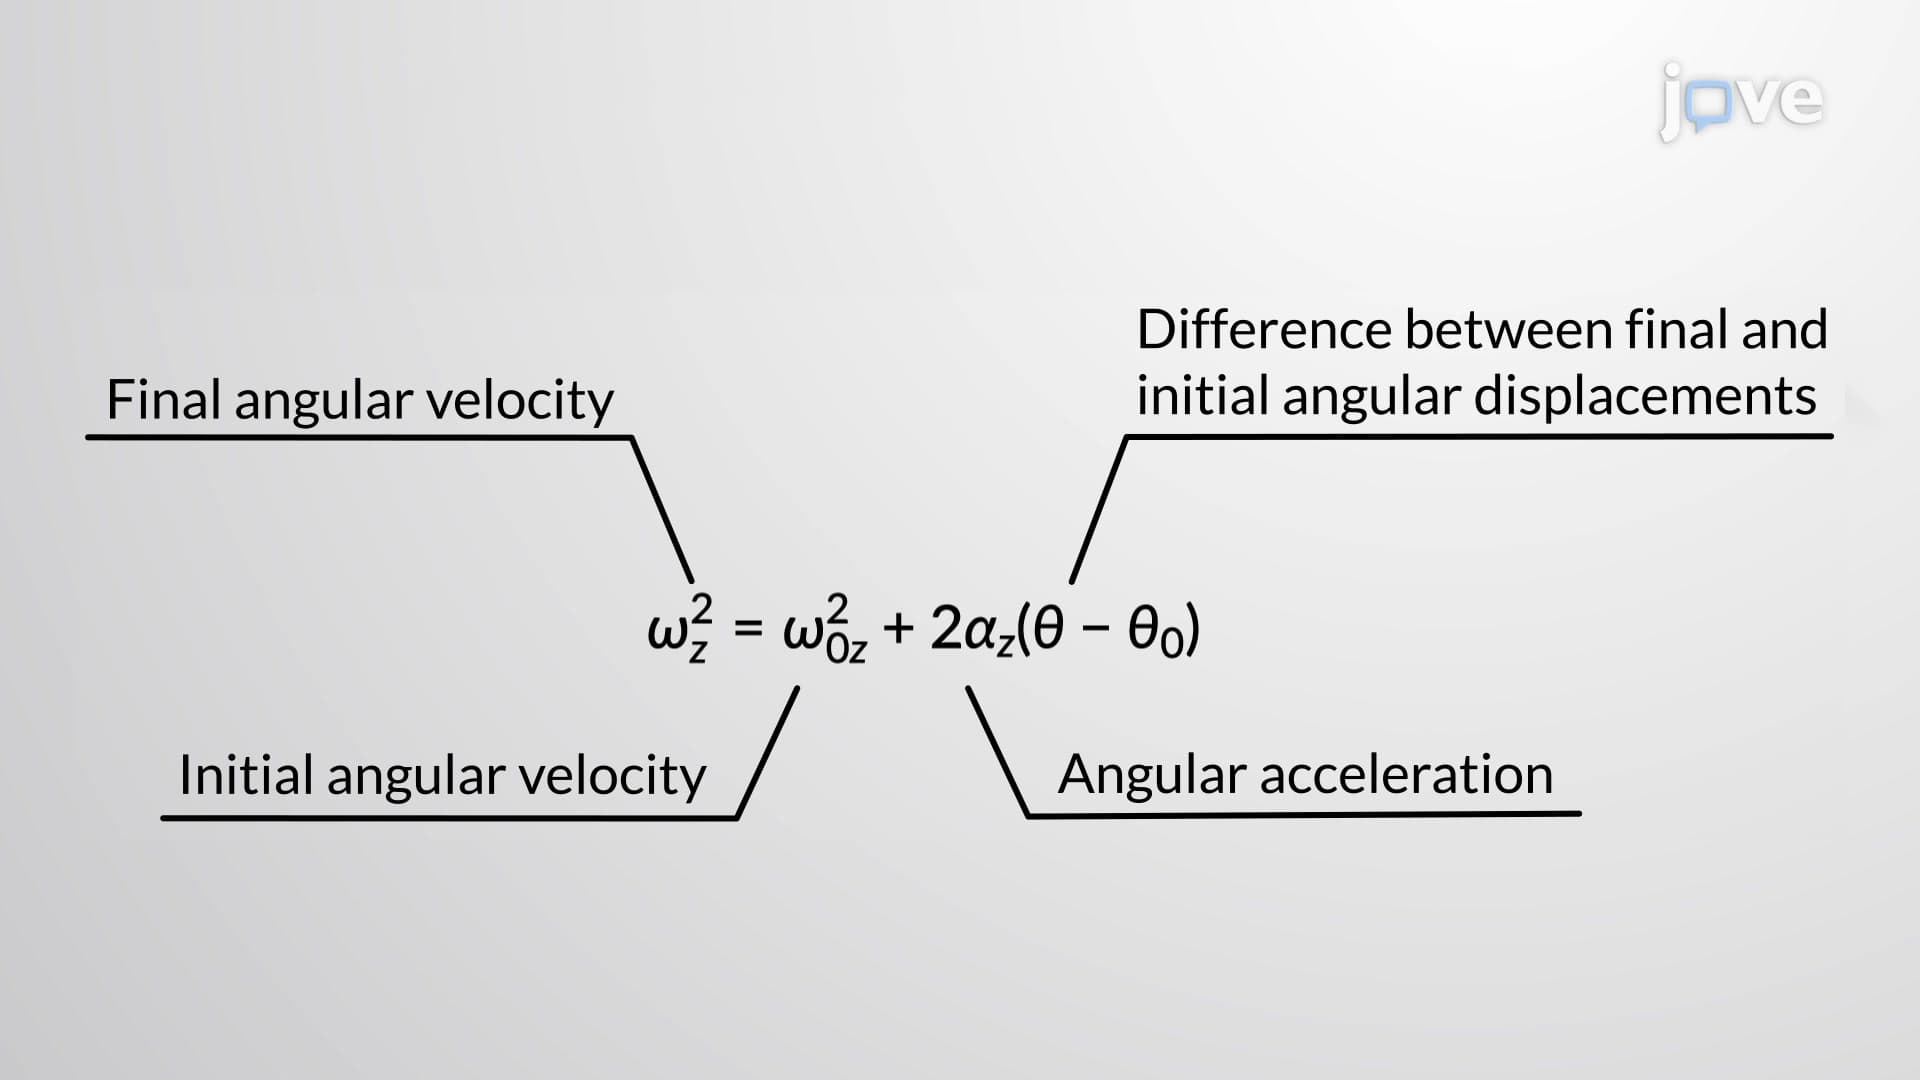
Rotation with Constant Angular Acceleration - II
The first...