Related Experiment Video
Updated: Jul 18, 2026

Three-Dimensional Mapping of the Rotation of Interactive Virtual Objects with Eye-Tracking Data
Published on: October 18, 2024
Gaze-centered updating of remembered visual space during active whole-body translations
Stan Van Pelt1, W Pieter Medendorp
1Nijmegen Institute for Cognition and Information, Radboud University Nijmegen, NL-6500 HE Nijmegen, The Netherlands. s.vanpelt@nici.ru.nl

Abstract:
Various cortical and sub-cortical brain structures update the gaze-centered coordinates of remembered stimuli to maintain an accurate representation of visual space across eyes rotations and to produce suitable motor plans. A major challenge for the computations by these structures is updating across eye translations. When the eyes translate, objects in front of and behind the eyes' fixation point shift in opposite directions on the retina due to motion parallax. It is not known if the brain uses gaze coordinates to compute parallax in the translational updating of remembered space or if it uses gaze-independent coordinates to maintain spatial constancy across translational motion. We tested this by having subjects view targets, flashed in darkness in front of or behind fixation, then translate their body sideways, and subsequently reach to the memorized target. Reach responses showed parallax-sensitive updating errors: errors increased with depth from fixation and reversed in lateral direction for targets presented at opposite depths from fixation. In a series of control experiments, we ruled out possible biasing factors such as the presence of a fixation light during the translation, the eyes accompanying the hand to the target, and the presence of visual feedback about hand position. Quantitative geometrical analysis confirmed that updating errors were better described by using gaze-centered than gaze-independent coordinates. We conclude that spatial updating for translational motion operates in gaze-centered coordinates. Neural network simulations are presented suggesting that the brain relies on ego-velocity signals and stereoscopic depth and direction information in spatial updating during self-motion.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:03
Inertial Frames of Reference
 01:27
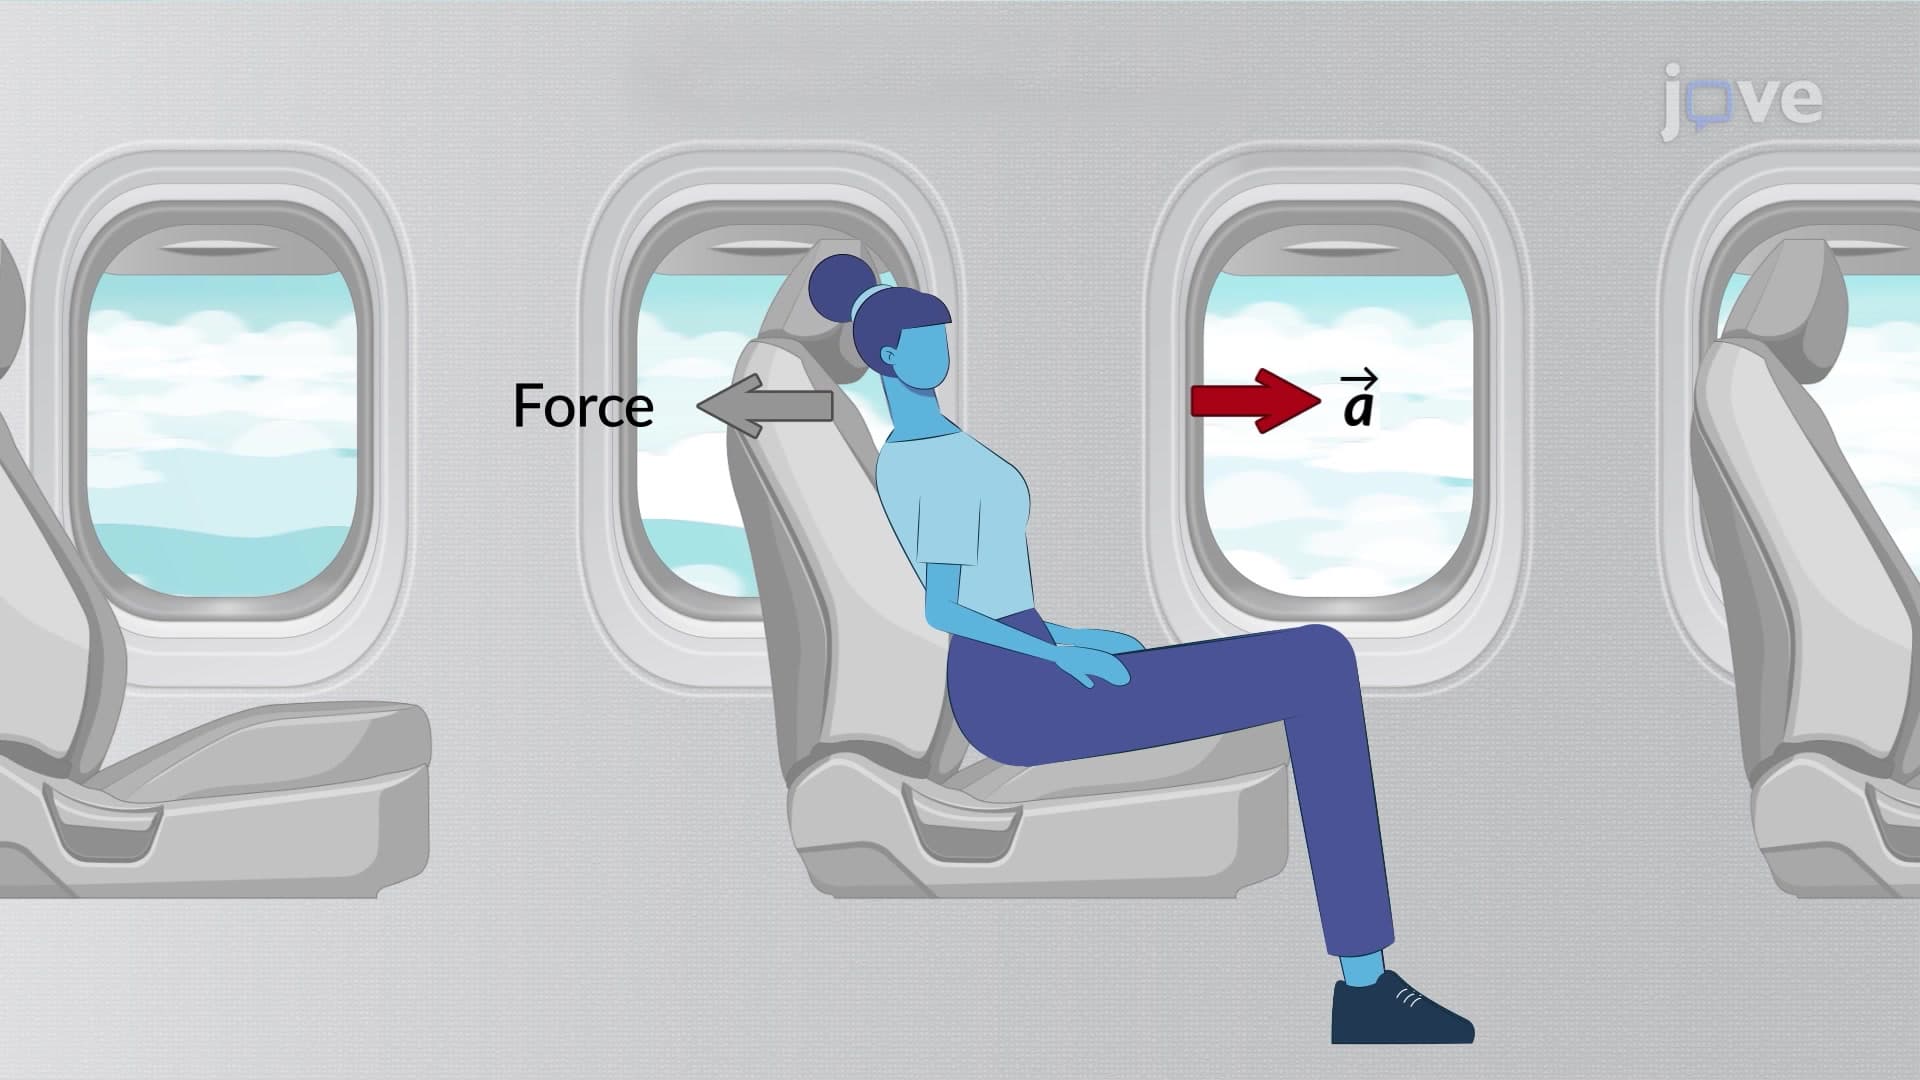
Non-inertial Frames of Reference
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
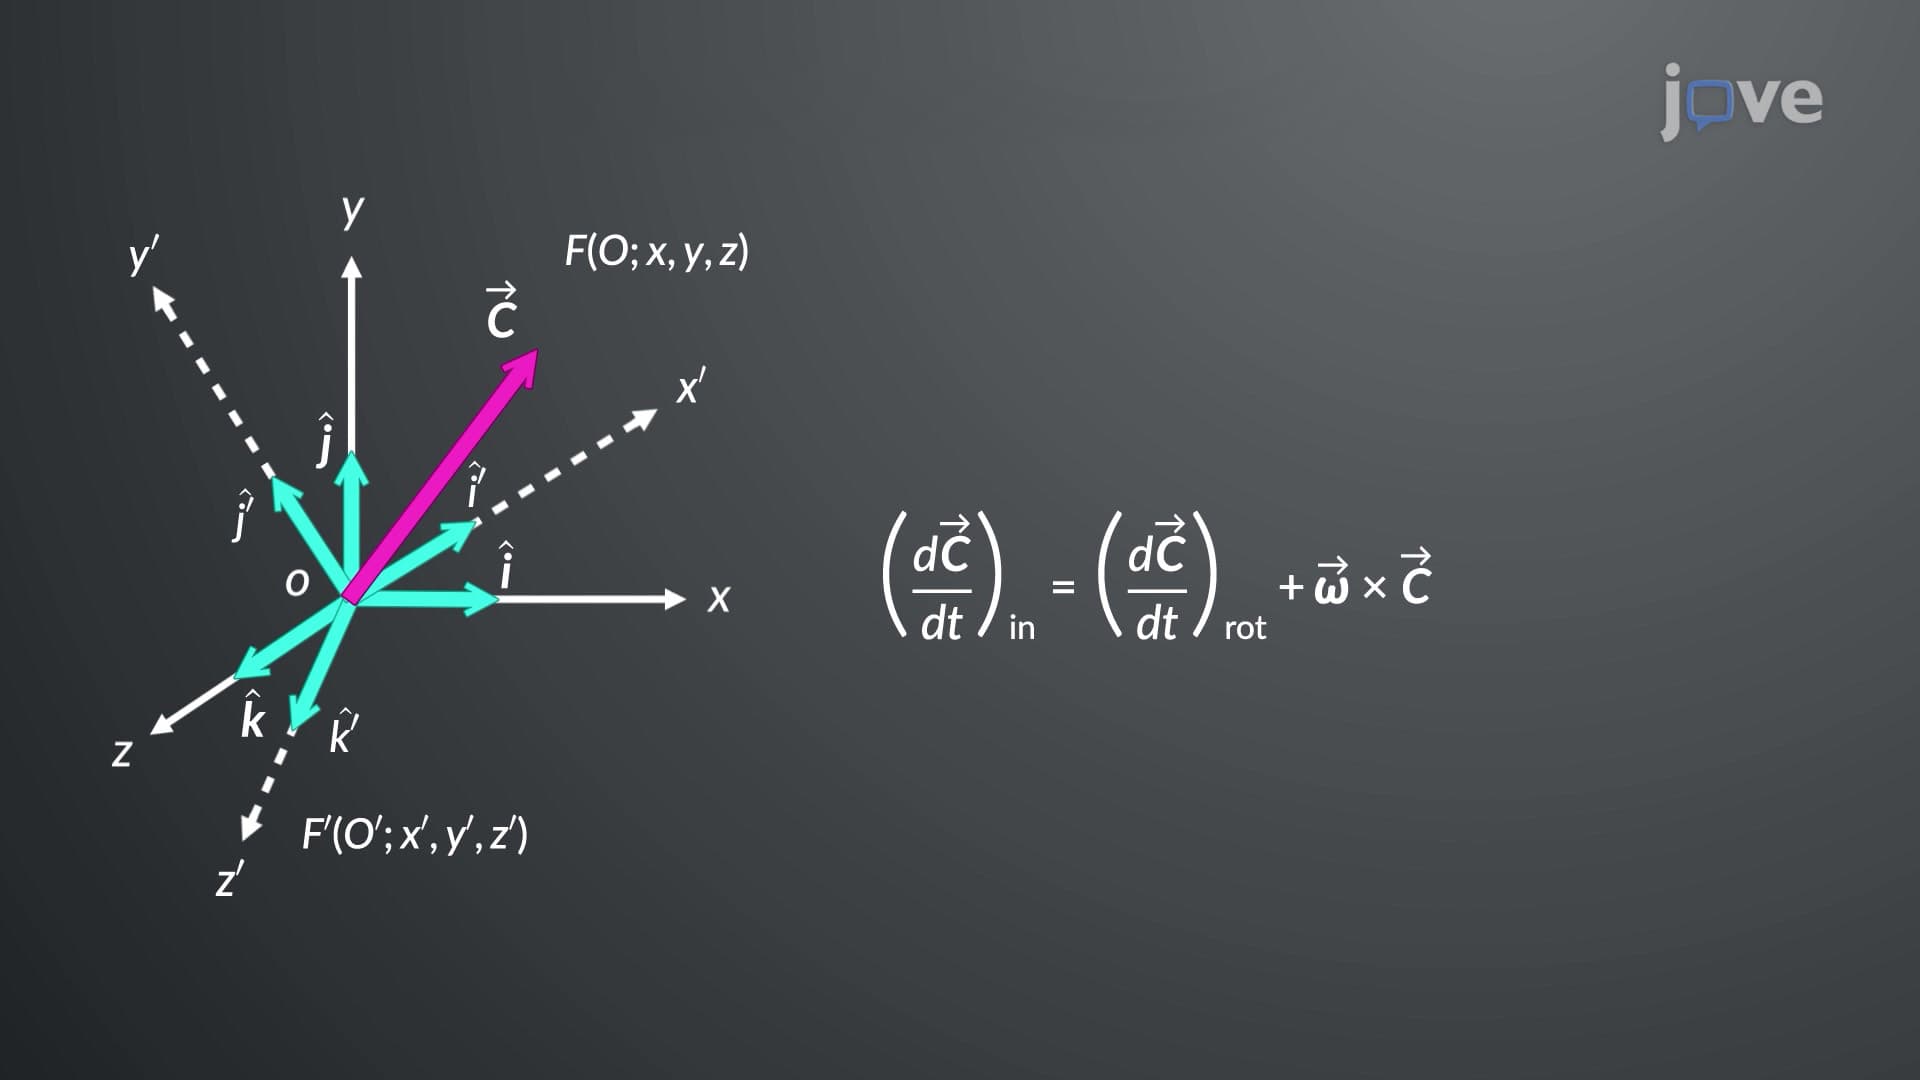 01:16
Vector Transformation in Rotating Coordinate Systems