Related Experiment Video
Updated: Jul 18, 2026

Proton Therapy Delivery and Its Clinical Application in Select Solid Tumor Malignancies
Published on: February 6, 2019
Derivative-free generation and interpolation of convex Pareto optimal IMRT plans
Aswin L Hoffmann1, Alex Y D Siem, Dick den Hertog
1Department of Radiation Oncology, Radboud University Nijmegen Medical Centre, PO Box 9101, 6500 HB Nijmegen, The Netherlands. a.hoffmann@rther.umcn.nl

Abstract:
In inverse treatment planning for intensity-modulated radiation therapy (IMRT), beamlet intensity levels in fluence maps of high-energy photon beams are optimized. Treatment plan evaluation criteria are used as objective functions to steer the optimization process. Fluence map optimization can be considered a multi-objective optimization problem, for which a set of Pareto optimal solutions exists: the Pareto efficient frontier (PEF). In this paper, a constrained optimization method is pursued to iteratively estimate the PEF up to some predefined error. We use the property that the PEF is convex for a convex optimization problem to construct piecewise-linear upper and lower bounds to approximate the PEF from a small initial set of Pareto optimal plans. A derivative-free Sandwich algorithm is presented in which these bounds are used with three strategies to determine the location of the next Pareto optimal solution such that the uncertainty in the estimated PEF is maximally reduced. We show that an intelligent initial solution for a new Pareto optimal plan can be obtained by interpolation of fluence maps from neighbouring Pareto optimal plans. The method has been applied to a simplified clinical test case using two convex objective functions to map the trade-off between tumour dose heterogeneity and critical organ sparing. All three strategies produce representative estimates of the PEF. The new algorithm is particularly suitable for dynamic generation of Pareto optimal plans in interactive treatment planning.
More Related Videos
Related Concept Videos
 01:30
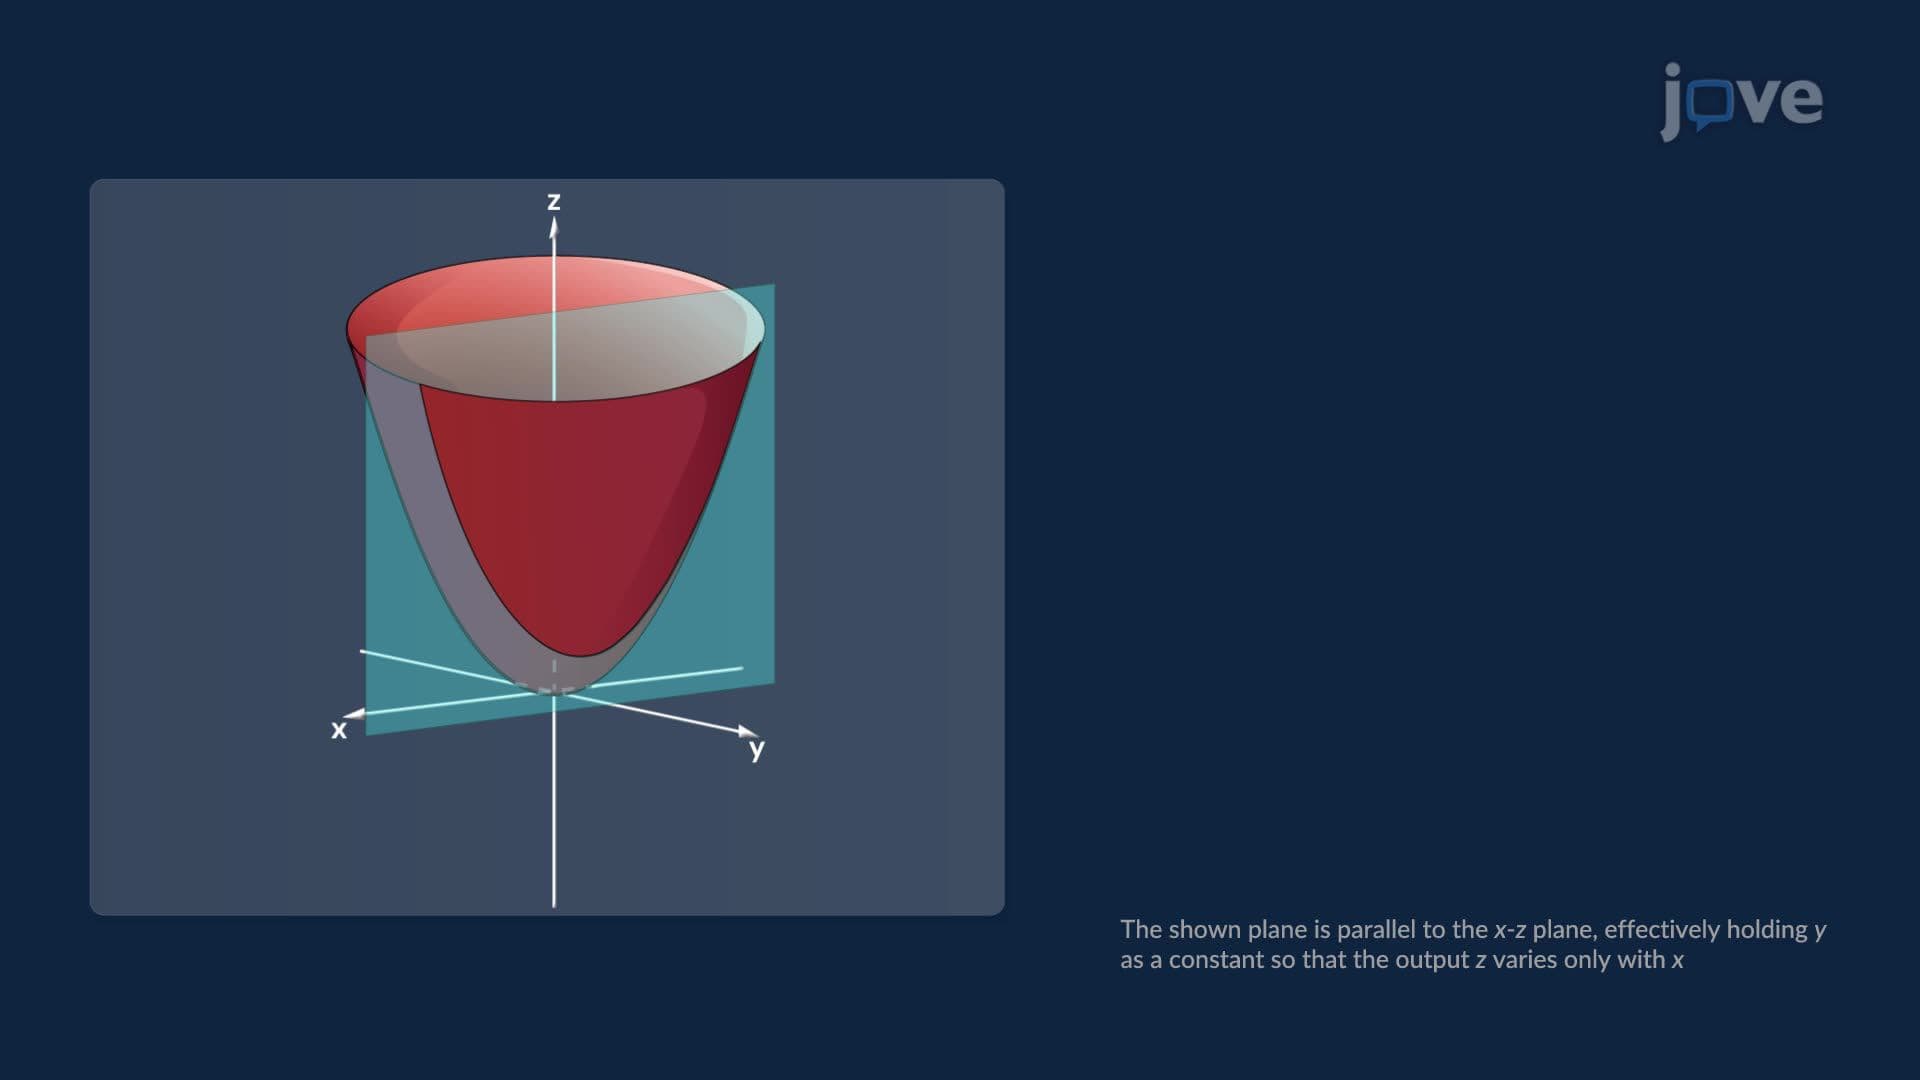
Multivariable Functions and Higher Derivatives
 01:27
Implicit Differentiation with Partial Derivatives
 01:28
Lagrange Multipliers: Two Constraints
 01:25
Maximizing the Directional Derivative
 01:26
Implicit Differentiation
 01:25
Introduction to Partial Derivatives