Related Experiment Video
Updated: Jul 17, 2026
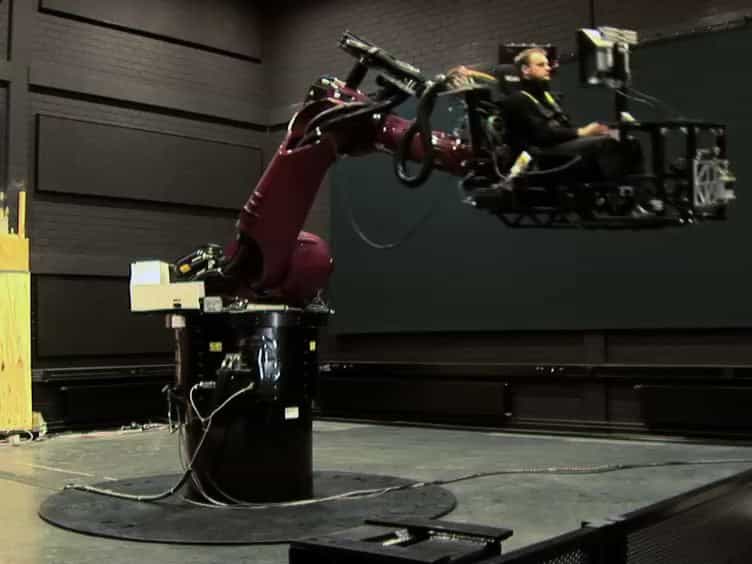
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Dual Stewart platform mobility simulator
R F Boian1, M Bouzit, G C Burdea
1CAIP Center, Rutgers University, Piscataway, NJ, USA.

Abstract:
A robotic mobility simulator is being developed to allow training on various hapticly simulated surfaces while still being in the safe clinical environment. The simulator is integrated with a rich virtual environment displayed in front of the patient. The system uses two Stewart platform robots to render the walking surface geometry and condition. The hardware components of the platforms and the considerations behind their design are presented here. In addition, the nine state algorithm used for simulating the treadmill functioning is described along with the procedure used to transform the motion of the robots into walking in the virtual environment.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:20
Two-Dimensional Force System
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...