Development of a shape memory alloy actuator for transanal endoscopic microsurgery
Related Experiment Video
Updated: Jul 17, 2026
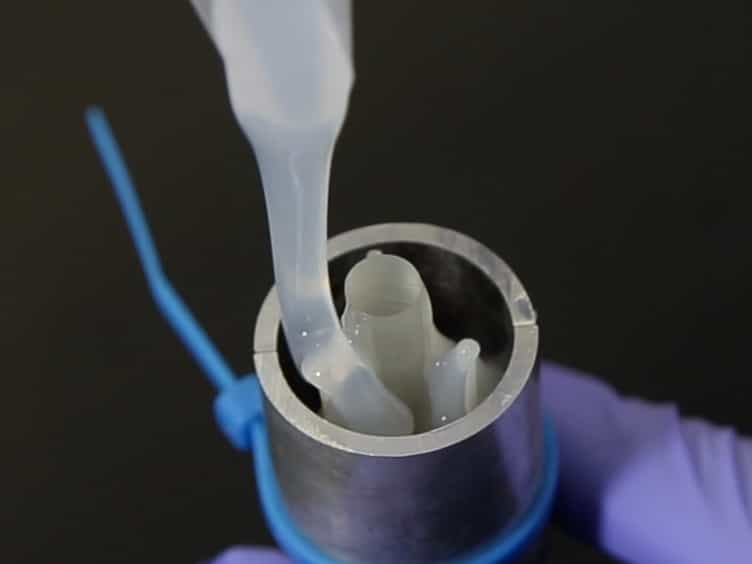
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Zhigang Wang1, Jim Hewit, Eric Abel
1Member, IEEE, Division of Mechanical Engineering and Mechatronics, University of Dundee, Dundee DD1 4HN, UK (phone: +44 1382 345484; fax: +44 1382 345508;

Abstract:
This paper describes problems in traditional transanal endoscopic microsurgery (TEM), and proposes a mechatronics approach in new design. As one of several actuation mechanisms to expose rectal cavity, a compression coil spring made of shape memory alloy (SMA) has been studied. A custom SMA spring actuator was designed to displace 12 mm with 45 N driving force. This actuator was embedded with our new TEM tubular structure and can be used to expose a rectal site up to 60 mm wide and 80 mm long. This exposure is considered to be sufficient for treating many tumors.