Detection of shape in radial frequency contours: independence of local and global form information
Related Experiment Video
Updated: Jul 16, 2026
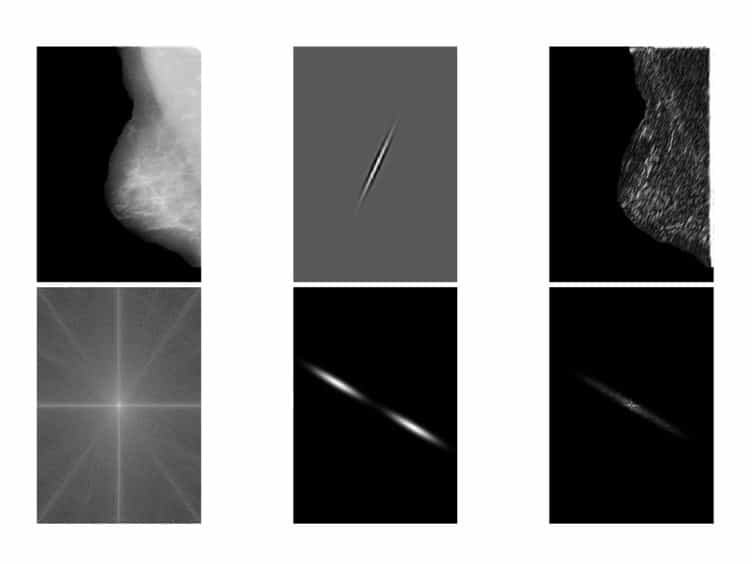
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Jason Bell1, David R Badcock, Hugh Wilson
1School of Psychology, The University of Western Australia, 35 Stirling Highway, Crawley 6009, WA, Australia. bellj02@student.uwa.edu.au

Abstract:
Radial frequency (RF) patterns have been used to study the processes involved in shape perception. The psychophysical literature suggests that there are distinct global and local shape detection processes for low and high radial frequency patterns, but this has not been tested in a combined contour pattern, such as would be needed to describe the contours of most natural objects. Here, we combined frequencies from the local and global range onto a compound RF structure. Observers' ability to detect a single RF component on the compound pattern was measured. Results show that sensitivity to high frequency local deviations in shape was not affected by the presence of a globally perceived low frequency pattern. In the reverse condition, detection of global form was not influenced by adding local deviations onto the structure. This suggests that local and global shape information can be detected independently within the human visual system.
Related Concept Videos
 01:03
IR Frequency Region: Fingerprint Region
The...
 01:12
Radius of Gyration of an Area
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the system's...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...