Related Experiment Videos
Performance-oriented antiwindup for a class of linear control systems with augmented neural network controller
Guido Herrmann1, Matthew C Turner, Ian Postlethwaite
1Control and Instrumentation Research Group, University of Leicester, Leicester LE1 7RH, UK. gh17@le.ac.uk

Abstract:
This paper presents a conditioning scheme for a linear control system which is enhanced by a neural network (NN) controller and subjected to a control signal amplitude limit. The NN controller improves the performance of the linear control system by directly estimating an actuator-matched, unmodeled, nonlinear disturbance, in closed-loop, and compensating for it. As disturbances are generally known to be bounded, the nominal NN-control element is modified to keep its output below the disturbance bound. The linear control element is conditioned by an antiwindup (AW) compensator which ensures performance close to the nominal controller and swift recovery from saturation. For this, the AW compensator proposed is of low order, designed using convex linear matrix inequalities (LMIs) optimization.
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:21
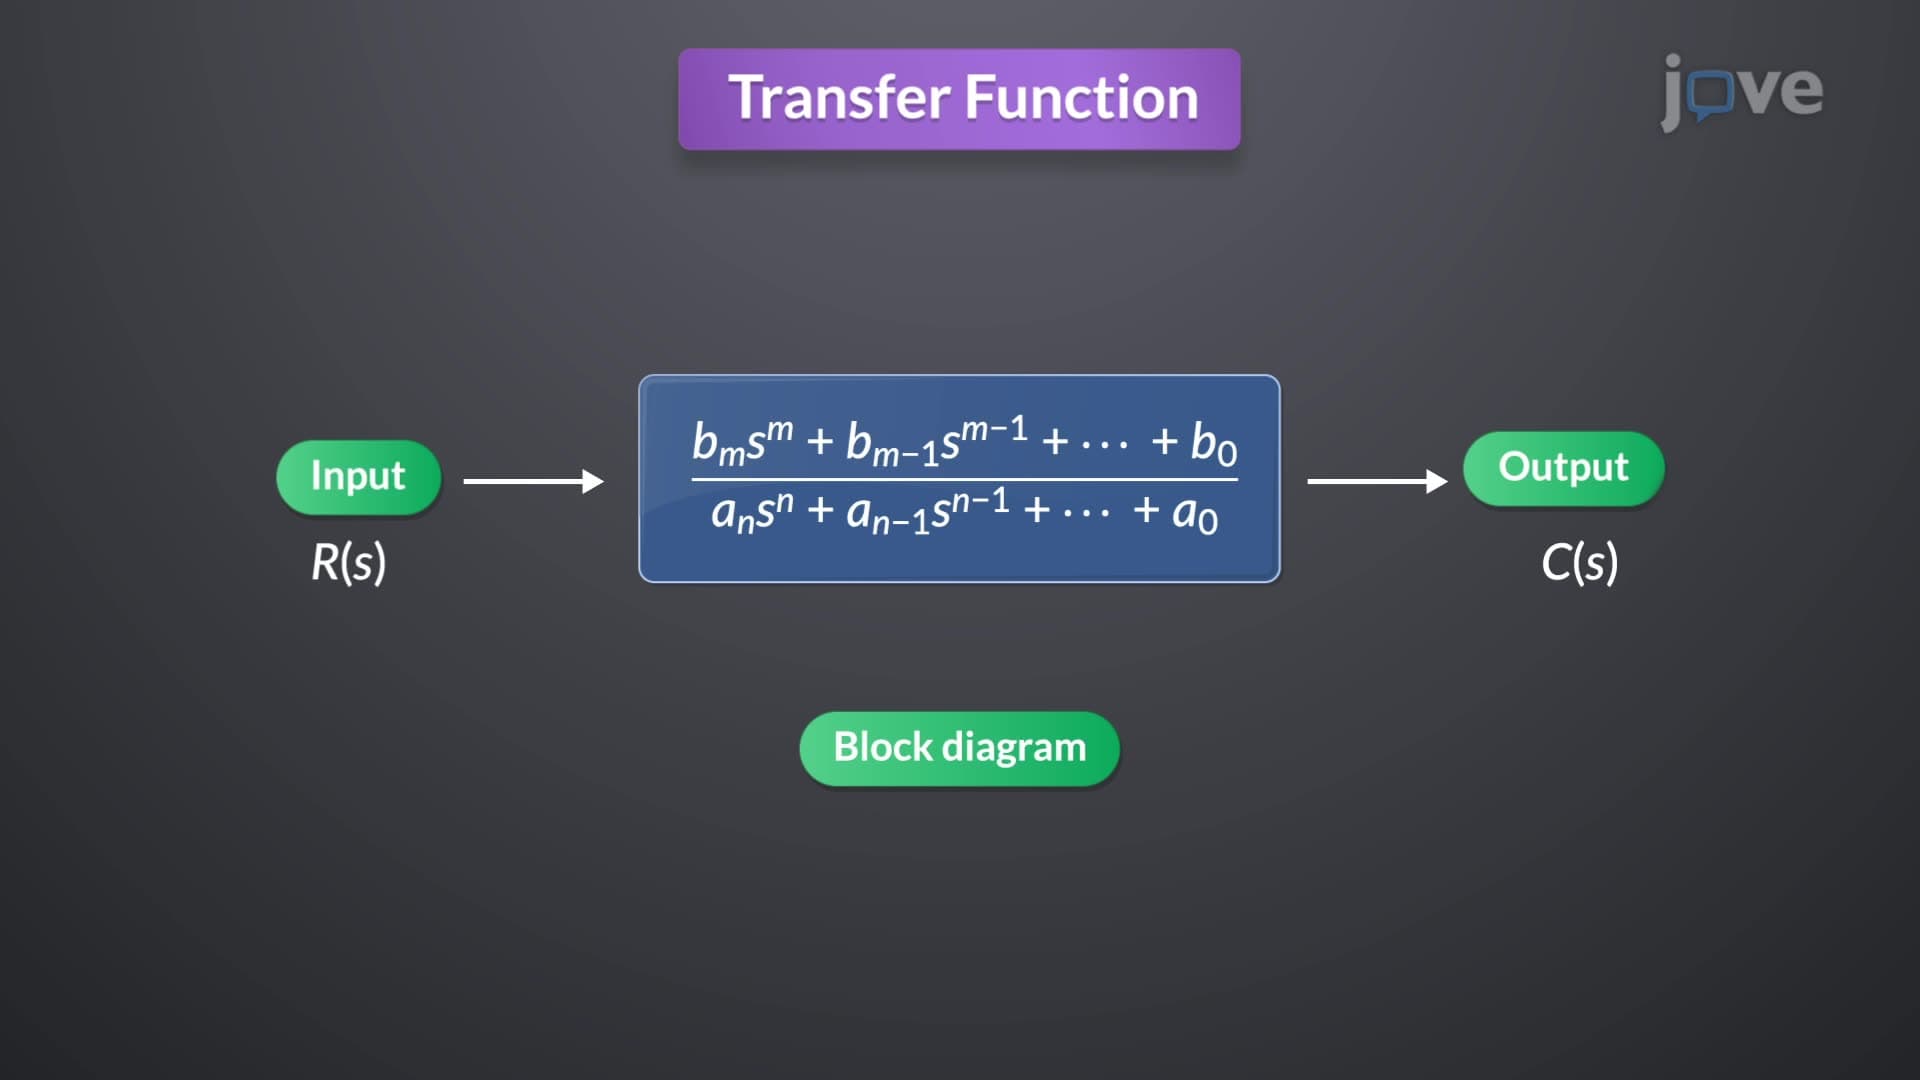
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:19
PID Controller