Related Experiment Video
Updated: Jul 15, 2026


A Flexible Wearable Supernumerary Robotic Limb for Chronic Stroke Patients
Published on: October 27, 2023
Mathematical and empirical proof of principle for an on-body personal lift augmentation device (PLAD)
Mohammad Abdoli-Eramaki1, Joan M Stevenson, Susan A Reid
1Queen's University Ergonomics Research Group, School of Occupational and Public Health, 350 Victoria Street, Toronto, Rm 148, PEC Kingston, Ont., Canada M5B2K3. mabdoli@ryerson.ca

Abstract:
In our laboratory, we have developed a prototype of a personal lift augmentation device (PLAD) that can be worn by workers during manual handling tasks involving lifting or lowering or static holding in symmetric and asymmetric postures. Our concept was to develop a human-speed on-body assistive device that would reduce the required lumbar moment by 20-30% without negative consequences on other joints or lifting kinematics. This paper provides mathematical proof using simplified free body diagrams and two-dimensional moment balance equations. Empirical proof is also provided based on lifting trials with nine male subjects who executed sagittal plane lifts using three lifting styles (stoop, squat, free) and three different loads (5, 15, and 25kg) under two conditions (PLAD, No-PLAD). Nine Fastrak sensors and six in-line strap force sensors were used to estimate the reduction of compressive and shear forces on L4/L5 as well as estimate the forces transferred to the shoulders and knees. Depending on lifting technique, the PLAD applied an added 23-36Nm of torque to assist the back muscles during lifting tasks. The peak pelvic girdle contact forces were estimated and their magnitudes ranged from 221.3+/-11.2N for stoop lifting, 324.3+/-17.2N for freestyle lifts to 468.47+/-23.2N for squat lifting. The PLAD was able to reduce the compression and shear forces about 23-29% and 7.9-8.5%, respectively.
More Related Videos
 07:30
The Muscle Cuff Regenerative Peripheral Nerve Interface for the Amplification of Intact Peripheral Nerve Signals
Published on: January 13, 2022
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Related Concept Videos
 01:30
Machines: Problem Solving II
 01:19
Machines
A free-body diagram of the...
 01:21
Upward Impending Motion
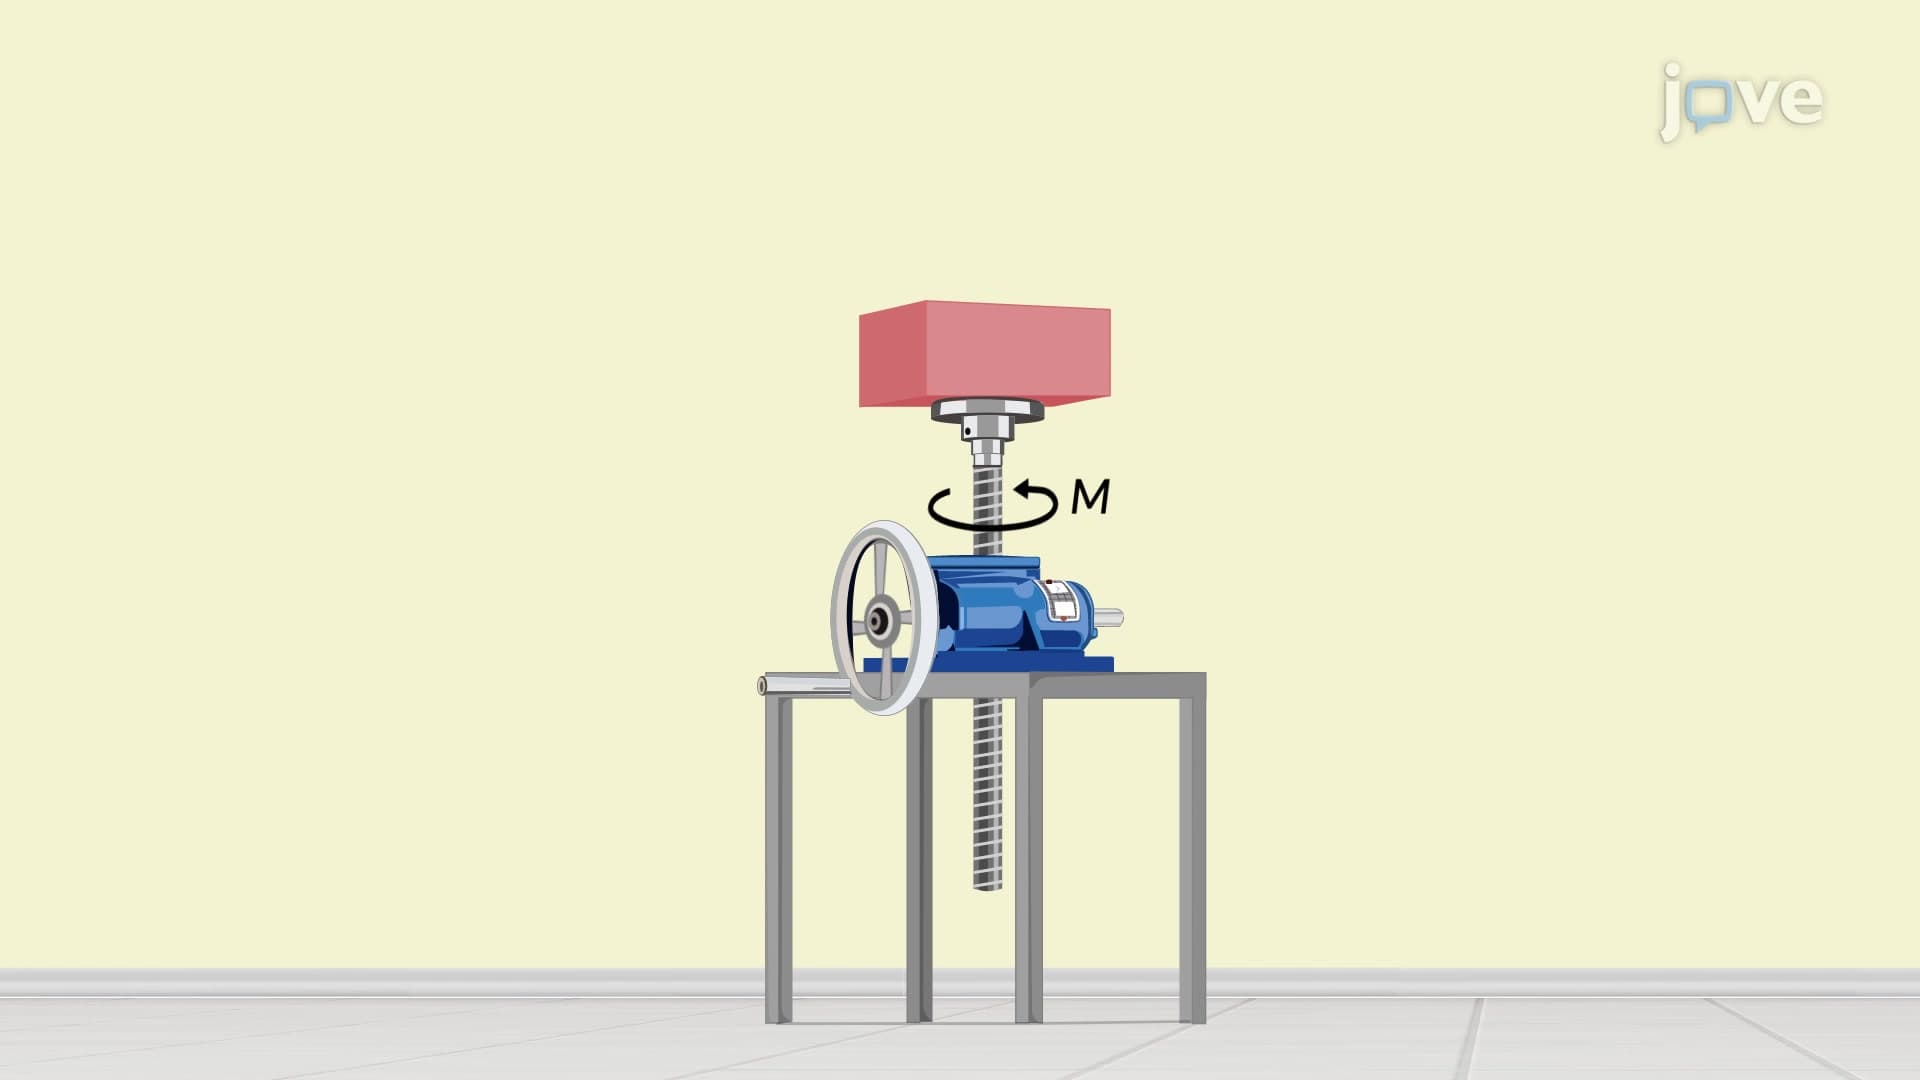
To better comprehend how a screw jack functions, consider the completely unraveled thread as a block in contact with the...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:13
Archimedes' Principle
 01:11
Design Example: Application of Archimedes' Principle
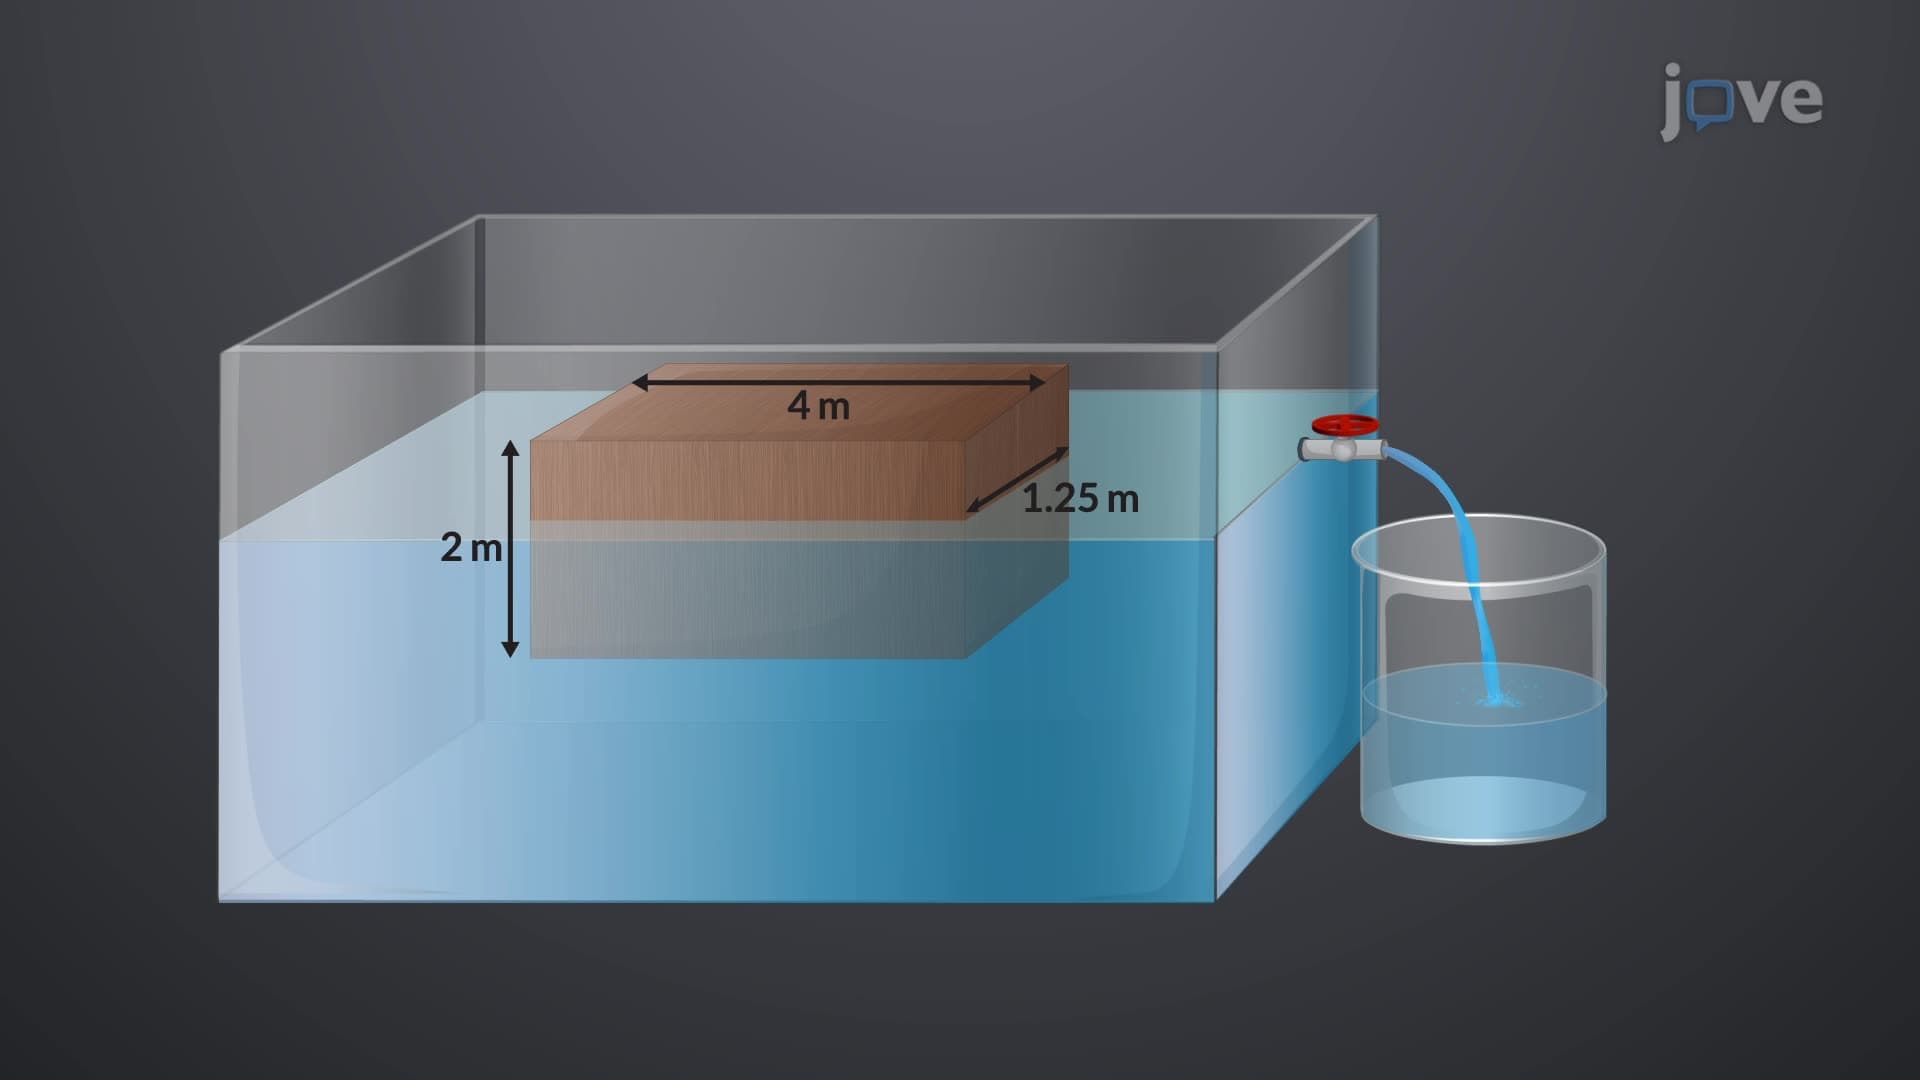
The volume of seawater displaced by the block is determined by first calculating the block's weight. This is done by multiplying the block's volume by...