Visual and haptic feedback contribute to tuning and online control during object manipulation
Related Experiment Video
Updated: Jul 14, 2026
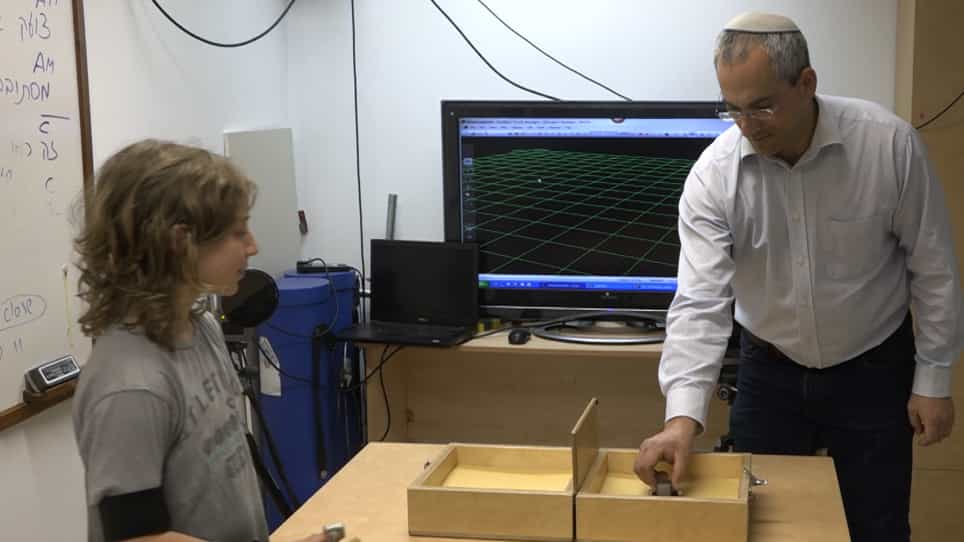
Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Felix C Huang1, R Brent Gillespie, Arthur D Kuo
1Department of Mechanical Engineering, University of Michigan, Ann Arbor, MI 48109, USA.

Abstract:
The authors employed a virtual environment to investigate how humans use haptic and visual feedback in a simple, rhythmic object-manipulation task. The authors hypothesized that feedback would help participants identify the appropriate resonant frequency and perform online control adjustments. The 1st test was whether sensory feedback is needed at all; the 2nd was whether the motor system combines visual and haptic feedback to improve performance. Task performance was quantified in terms of work performed on the virtual inertia, ability to identify the correct rhythm, and variability of movement. Strict feedforward control was found to be ineffective for this task, even when participants had previous knowledge of the rhythm. Participants (N = 11) performed far better when feedback was available (11 times more work, 2.2 times more precise frequency, 30% less variability; p < .05 for all 3 performance measures). Using sensory feedback, participants were able to rapidly identify 4 different spring-inertia systems without foreknowledge of the corresponding resonant frequencies. They performed over 20% more work with 24% less variability when provided with both visual and haptic feedback than they did with either feedback channel alone (p < .05), providing evidence that they integrated online sensory channels. Whereas feedforward control alone led to poor performance, feedback control led to fast tuning or calibration of control according to the resonant frequency of the object, and to better control of the rhythmic movement itself.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:10
Control Systems
At the heart...
 01:27
Tactile and Chemical Senses
 01:18
Hierarchy of Motor Control