Related Experiment Video
Updated: Jul 12, 2026
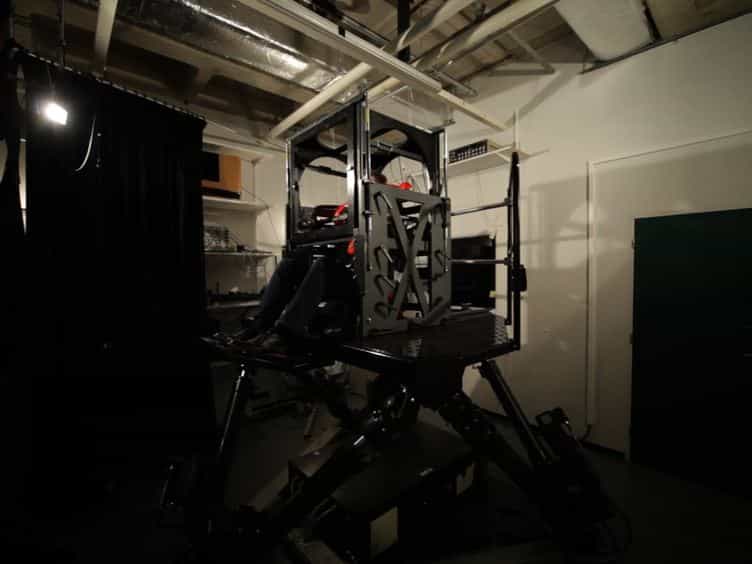

Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
Translational motion perception and vestiboocular responses in the absence of non-inertial cues
1Department of Neurobiology and Anatomy, University of Rochester, Rochester, NY 14642, USA. scott.seidman@rochester.edu

Abstract:
Path integration studies in humans show that we have the ability to accurately reproduce our path in the absence of visual information. It has been suggested that this ability is supported by acceleration signals, as transduced by the otolith organs, which may then be integrated twice to produce path excursion. Vestibuloocular responses to linear translations (LVOR), however, show considerable frequency dependence, with substantial attenuation in response to low frequency translational motion. If otolith information were processed similarly by path integration mechanisms, the resulting signal would not be sufficient to account for robust path integration for stimuli typically used in such studies. We hypothesized that such behavior relies upon cognitive skill and transient otolith cues, typically combined with non-directional cues of motion, such as vibration and noise produced by the mechanics apparatus used to produce linear motion. Continuous motion estimation tasks were used to assess translation perception, while eye movement recordings revealed LVOR responses, in 12 normal and 2 vestibulopathic human subjects while riding on a sled designed to specifically minimize non-directional motion cues. In the near absence of such cues, perceptual responses, like the LVOR, showed high-pass characteristics. This implies that otolith signals are not sufficient to support previously observed path integration behaviors, which must be supplemented by non-directional motion cues.
More Related Videos
Related Concept Videos
 01:29
The Vestibular System
 01:03
Inertial Frames of Reference
 01:27
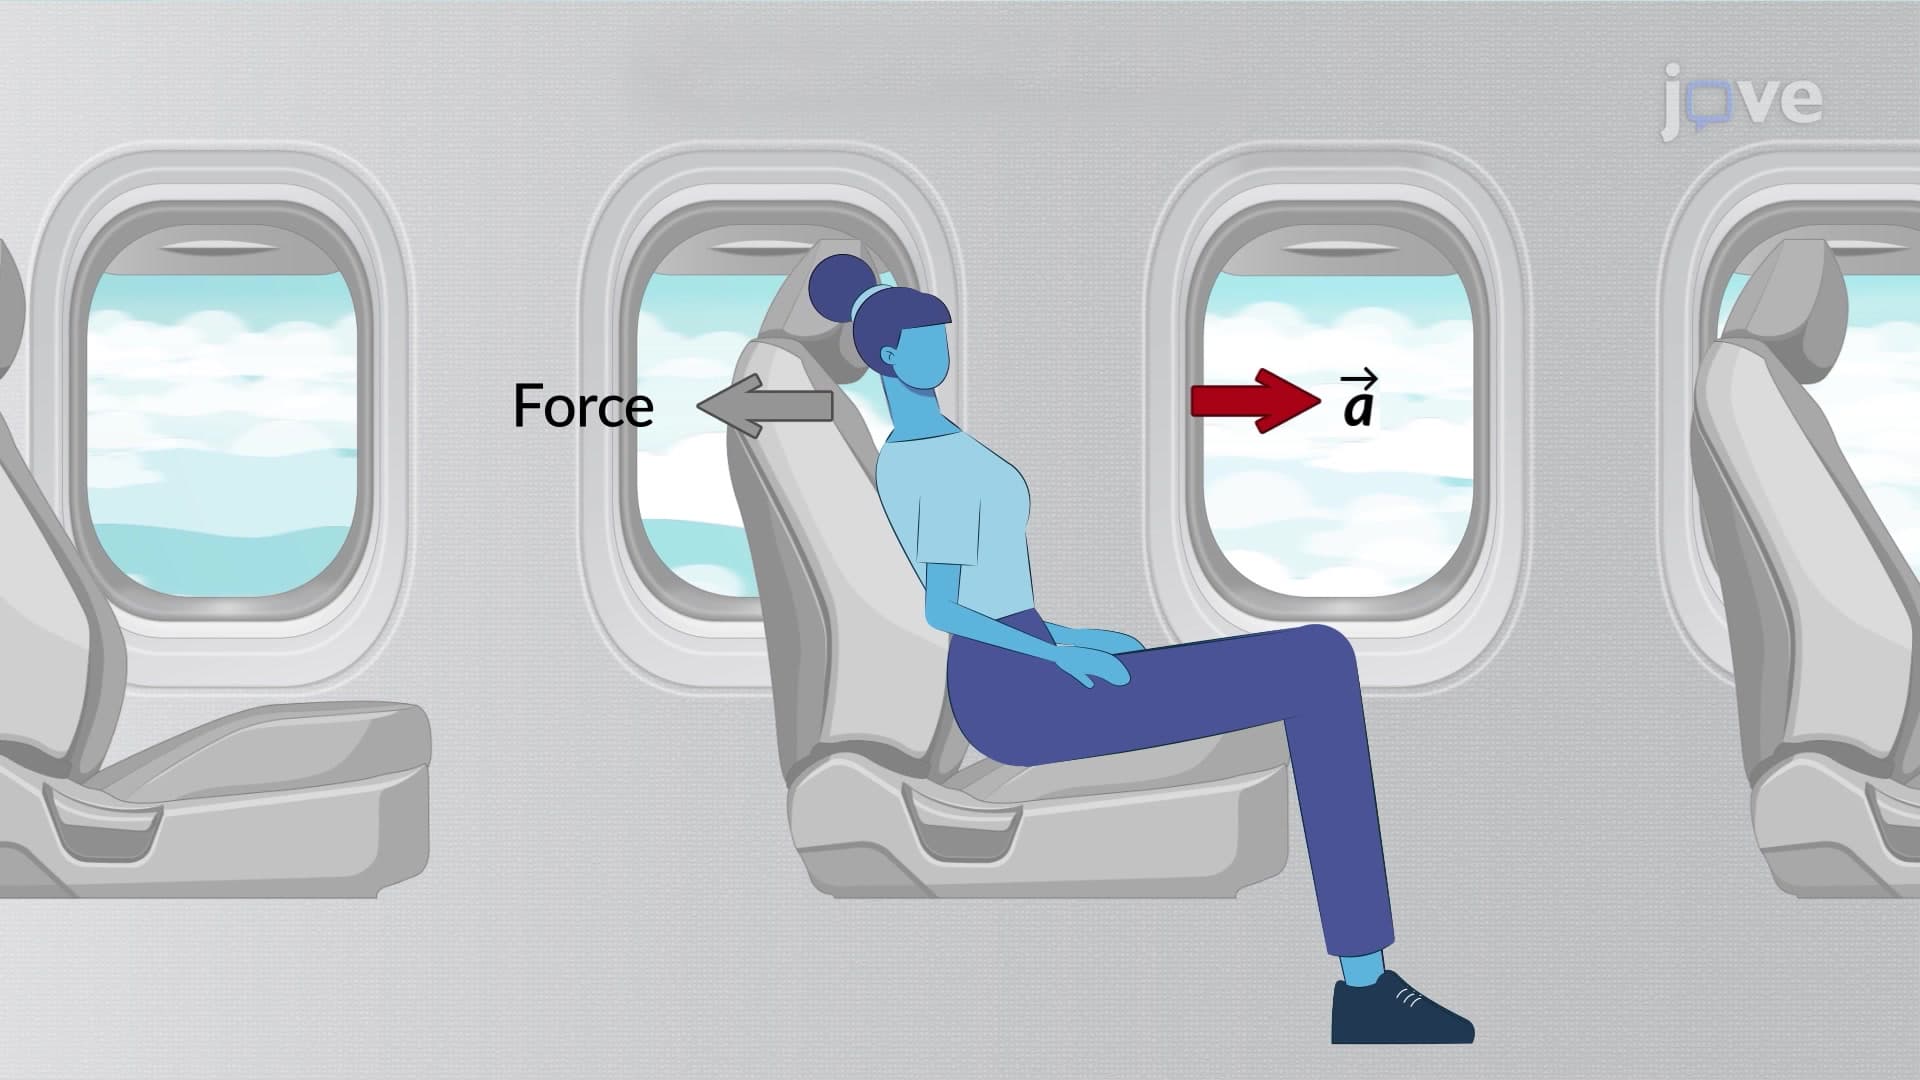
Non-inertial Frames of Reference
 01:15
Equilibrium and Balance
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...