Asymmetric interjoint feedback contributes to postural control of redundant multi-link systems
Related Experiment Video
Updated: Jan 26, 2026
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Nathan E Bunderson1, Lena H Ting, Thomas J Burkholder
1Department of Biomedical Engineering, Georgia Institute of Technology and Emory University, Atlanta, GA 30332, USA.

Abstract:
Maintaining the postural configuration of a limb such as an arm or leg is a fundamental neural control task that involves the coordination of multiple linked body segments. Biological systems are known to use a complex network of inter- and intra-joint feedback mechanisms arising from muscles, spinal reflexes and higher neuronal structures to stabilize the limbs. While previous work has shown that a small amount of asymmetric heterogenic feedback contributes to the behavior of these systems, a satisfactory functional explanation for this non-conservative feedback structure has not been put forth. We hypothesized that an asymmetric multi-joint control strategy would confer both an energetic and stability advantage in maintaining endpoint position of a kinematically redundant system. We tested this hypothesis by using optimal control models incorporating symmetric versus asymmetric feedback with the goal of maintaining the endpoint location of a kinematically redundant, planar limb. Asymmetric feedback improved endpoint control performance of the limb by 16%, reduced energetic cost by 21% and increased interjoint coordination by 40% compared to the symmetric feedback system. The overall effect of the asymmetry was that proximal joint motion resulted in greater torque generation at distal joints than vice versa. The asymmetric organization is consistent with heterogenic stretch reflex gains measured experimentally. We conclude that asymmetric feedback has a functionally relevant role in coordinating redundant degrees of freedom to maintain the position of the hand or foot.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
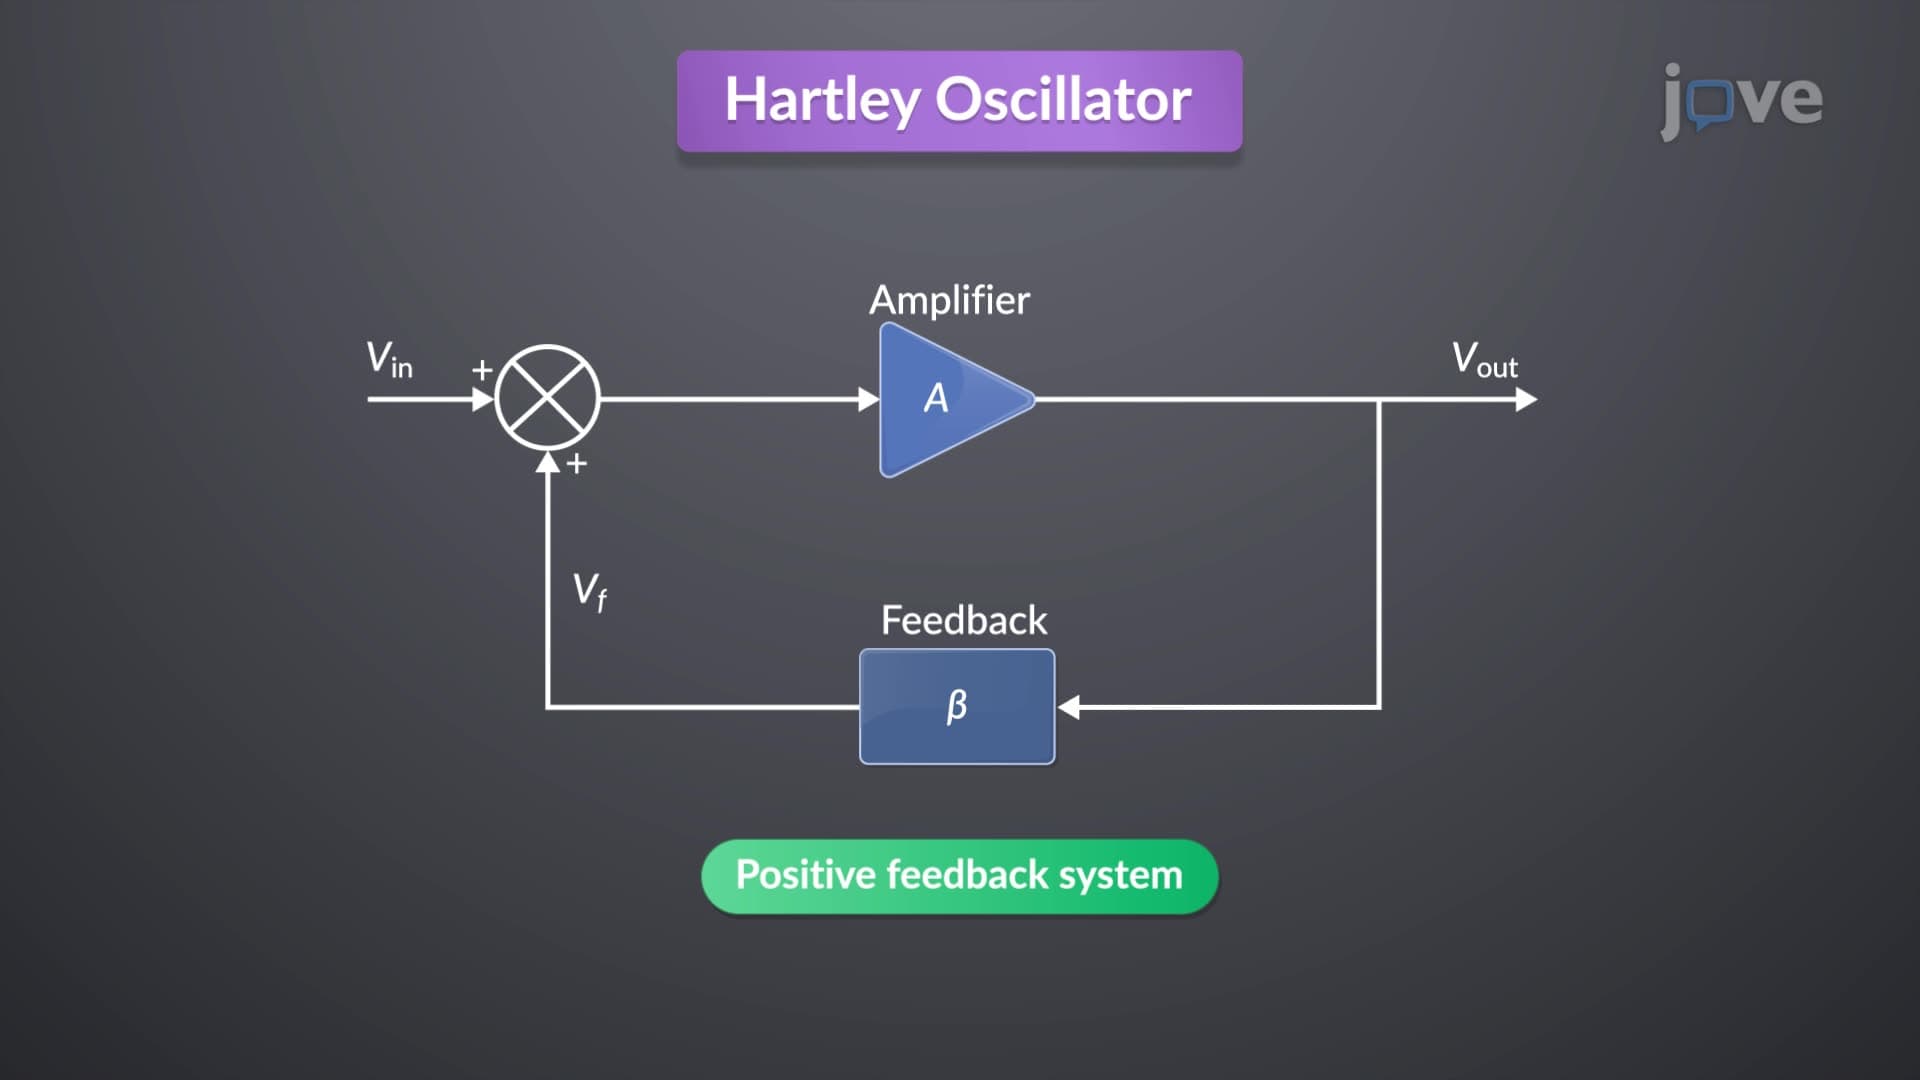
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:10
Control Systems
At the heart...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 00:46
Feedback Inhibition