Related Experiment Video
Updated: Jul 11, 2026


MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
The perceived position of a moving object is not the result of position integration
Mowei Shen1, Jifan Zhou, Tao Gao
1Department of Psychology and Behaviroal Sciences, Xixi Campus, Zhejiang University, Hangzhou, Zhejiang 310028, People's Republic of China.

Abstract:
The flash-lag effect is a robust visual illusion in which a flash appears to spatially lag a continuously moving stimulus, even though both stimuli are actually precisely aligned. Some research has been done to test how visual information has been integrated over time. The position integration model suggests motion integration is a form of interpolation of past positions, and predicts that we cannot perceive the reversal point at its actual position on the trajectory of a moving object which reverses abruptly. In current research, we demonstrate that subjects could perceive the reversal point accurately while the psychometric function measured by a flash does not pass through the actual turning point. These results do not support the position integration model. We propose that the flash-lag effect is more likely to be a temporal illusion.

Related Concept Videos
 01:00
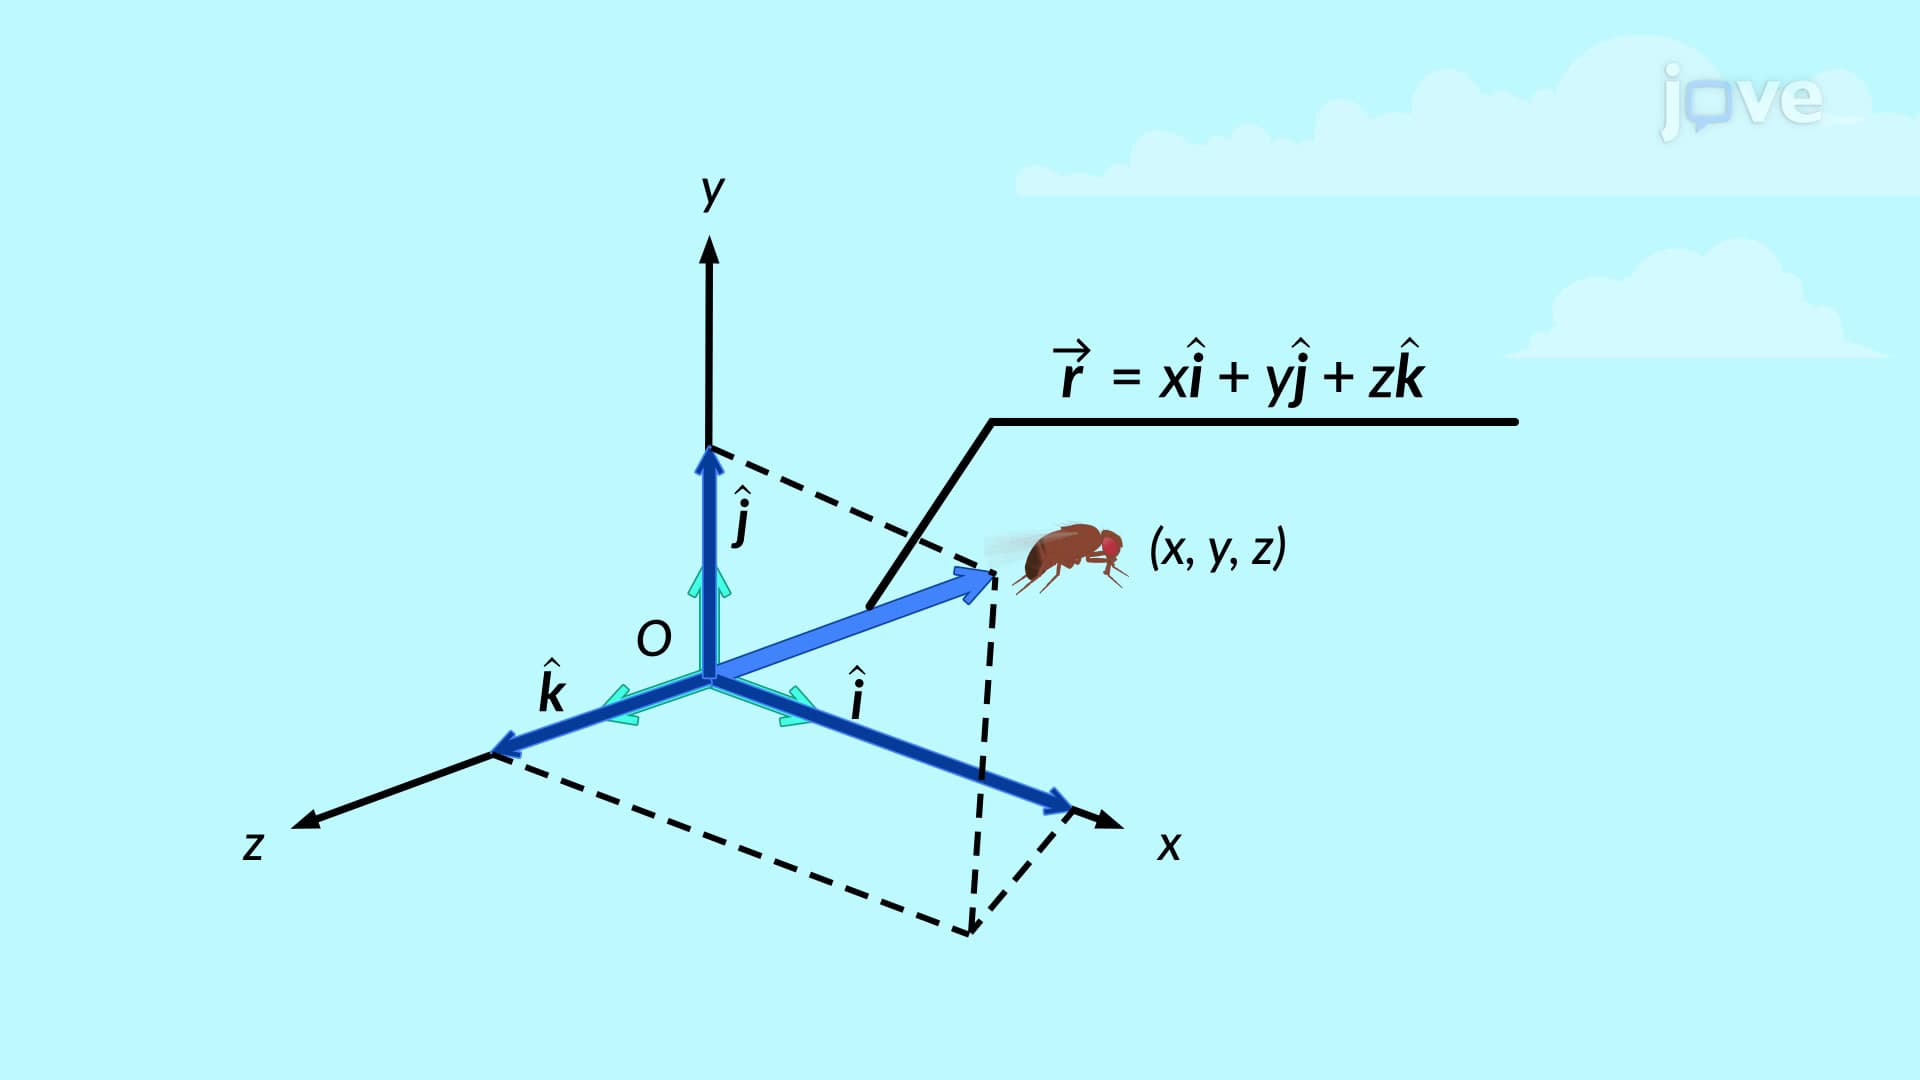
Position and Displacement Vectors
Further, several important kinds of...
01:00Position and Displacement Vectors
Further, several important kinds of...
 01:31
Position and Displacement
01:31Position and Displacement
 01:20
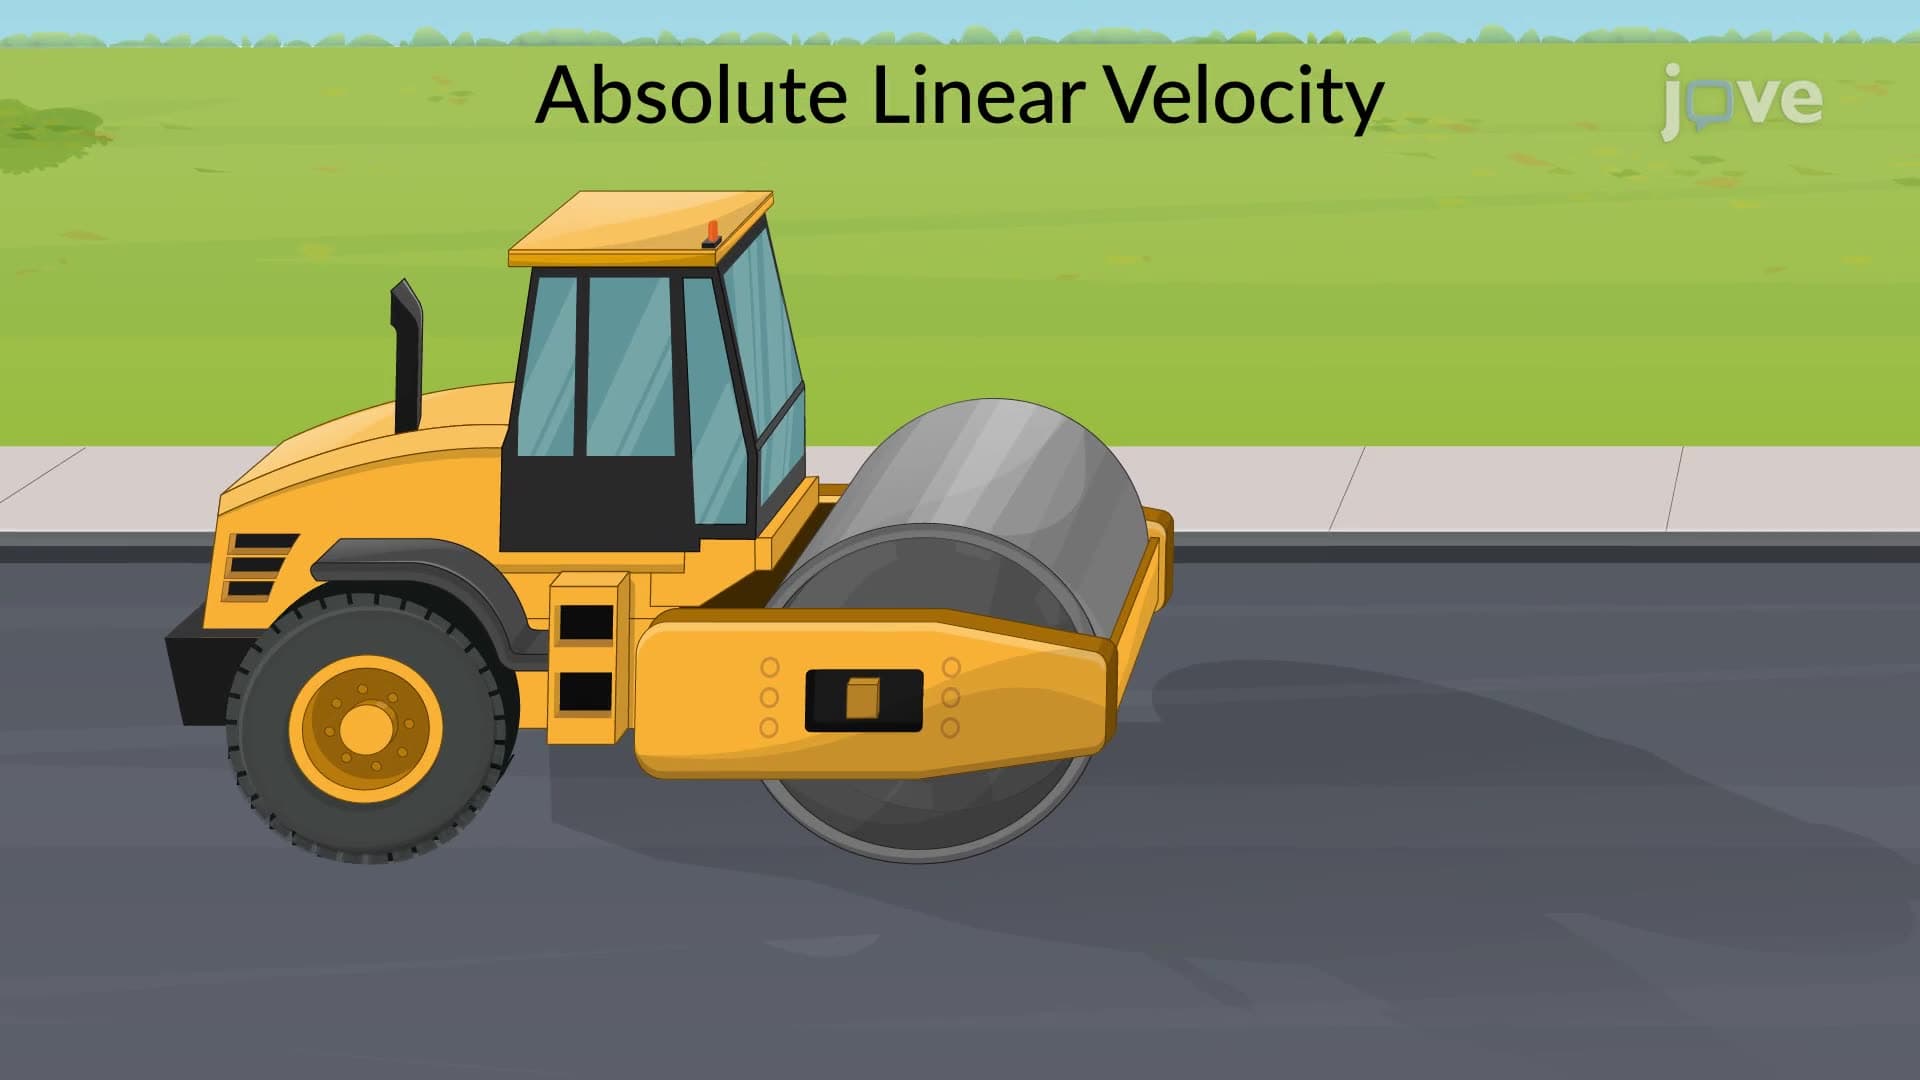
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
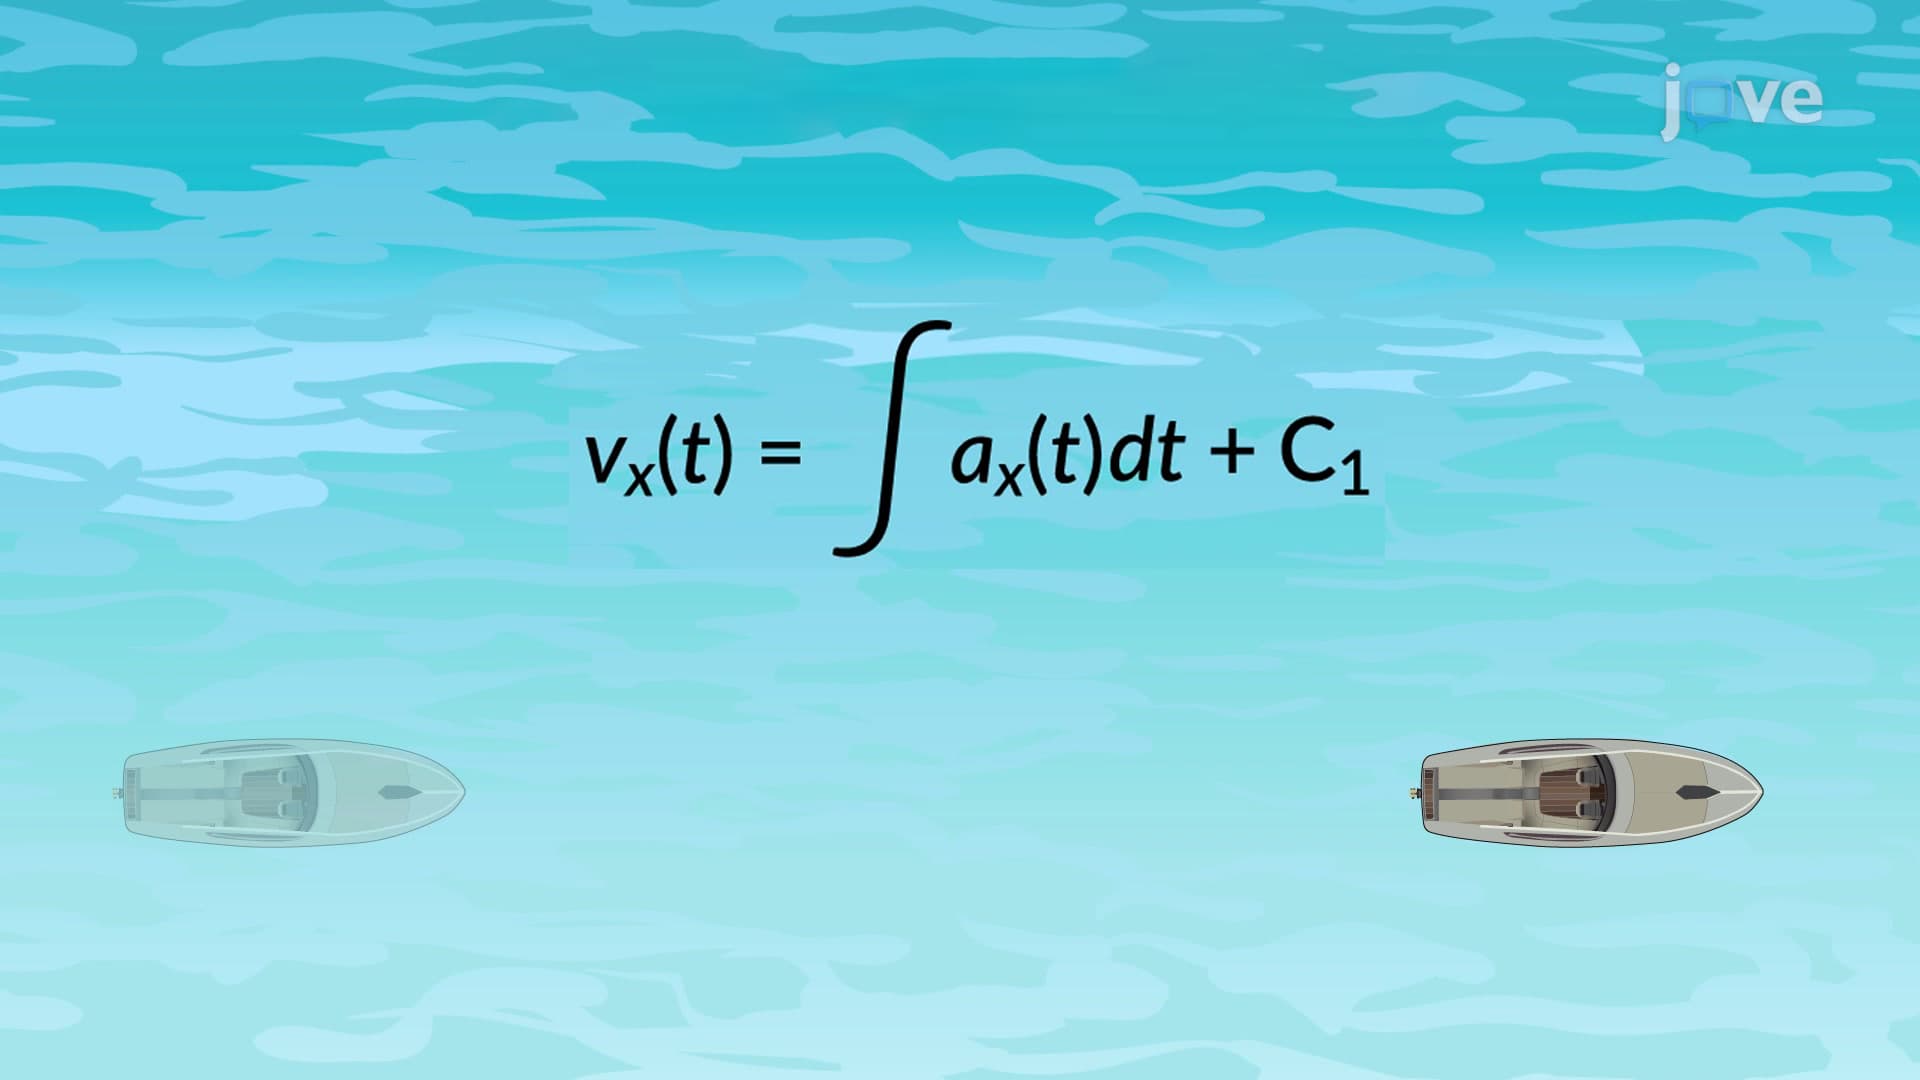 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...