Related Experiment Video
Updated: Jul 10, 2026

A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Dimensionality reduction of cellular actuator arrays using the concept of synergy for driving a robotic hand
1Dept. of Mech. Eng., Massachusetts Inst. of Technol., Cambridge, MA 02139, USA. kyujin@mit.edu

Abstract:
This paper presents a method of reducing dimensionality of cellular actuator arrays. The cellular actuator arrays are used to drive a multi-axis system, i.e. robotic hand. The actuator arrays use Segmented Binary Control (SBC) which simplifies the control of nonlinear artificial muscle actuators. Although the SBC simplifies the control, the number of cells required to create motions is increased dramatically, thereby increasing the dimension of the actuator arrays. Therefore, reducing the number of controls, or dimension is needed. The coordinated motion of the robotic hand enables the coupling of actuators. In biological systems, synergies, a strategy of grouping output variables to simplify the control of a large number of muscles and joints is used to explain the coordinated motion created by the muscles. Similarly we can apply this concept to group the cells of the actuator array to be turned on or off together. Each group of cells, called segments can be designed to perform a certain set of desired postures. Data from fifteen different tasks is used in the design. The gathered joint angle data is transformed into actuator displacement data and used to generate a segmentation design of the actuator. For segmentation design, feature extraction method, similar to non-negative matrix factorization with binary filter is proposed. The segmentation design reduces 96 separately controlled segments to 6, while maintaining the ability to accomplish all desired postures. A prototype robotic hand with five fingers, designed and fabricated using the FDM process, is driven with this actuator system.

Related Concept Videos
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:30
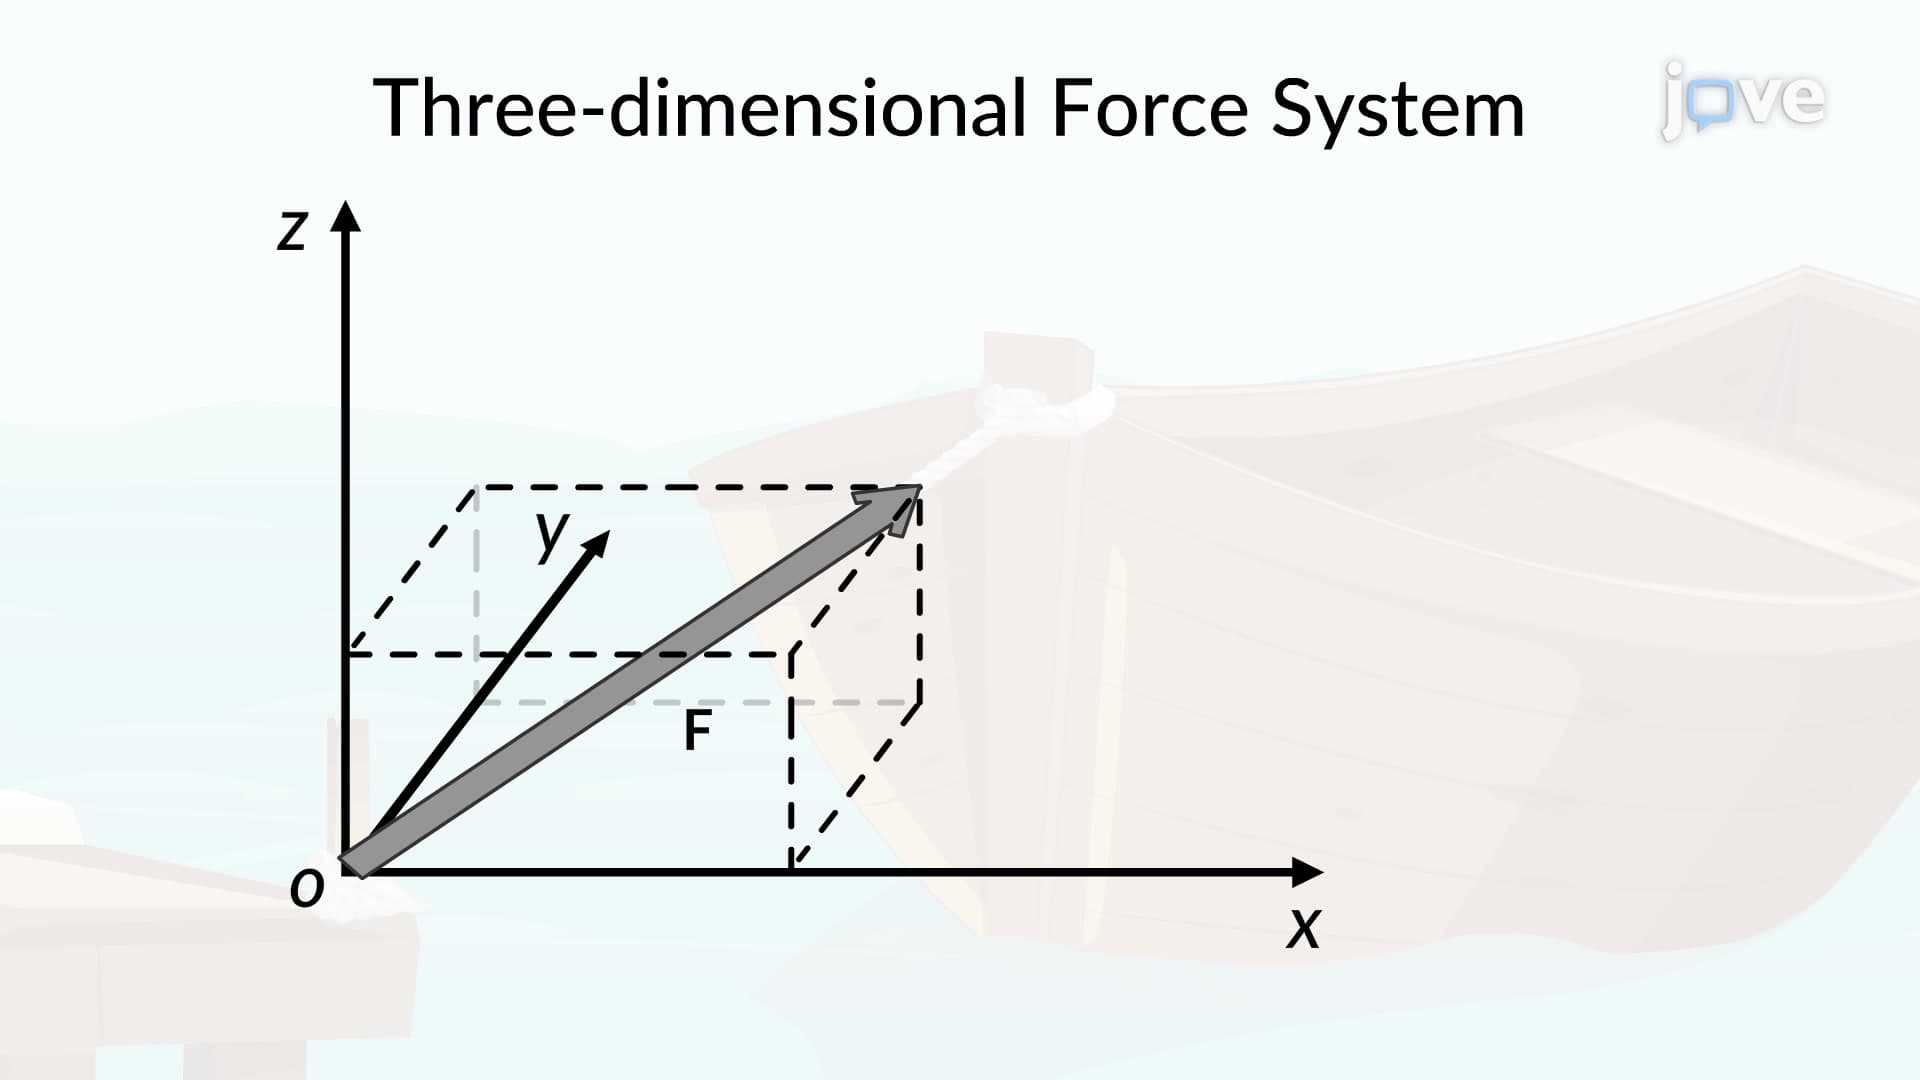
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:23
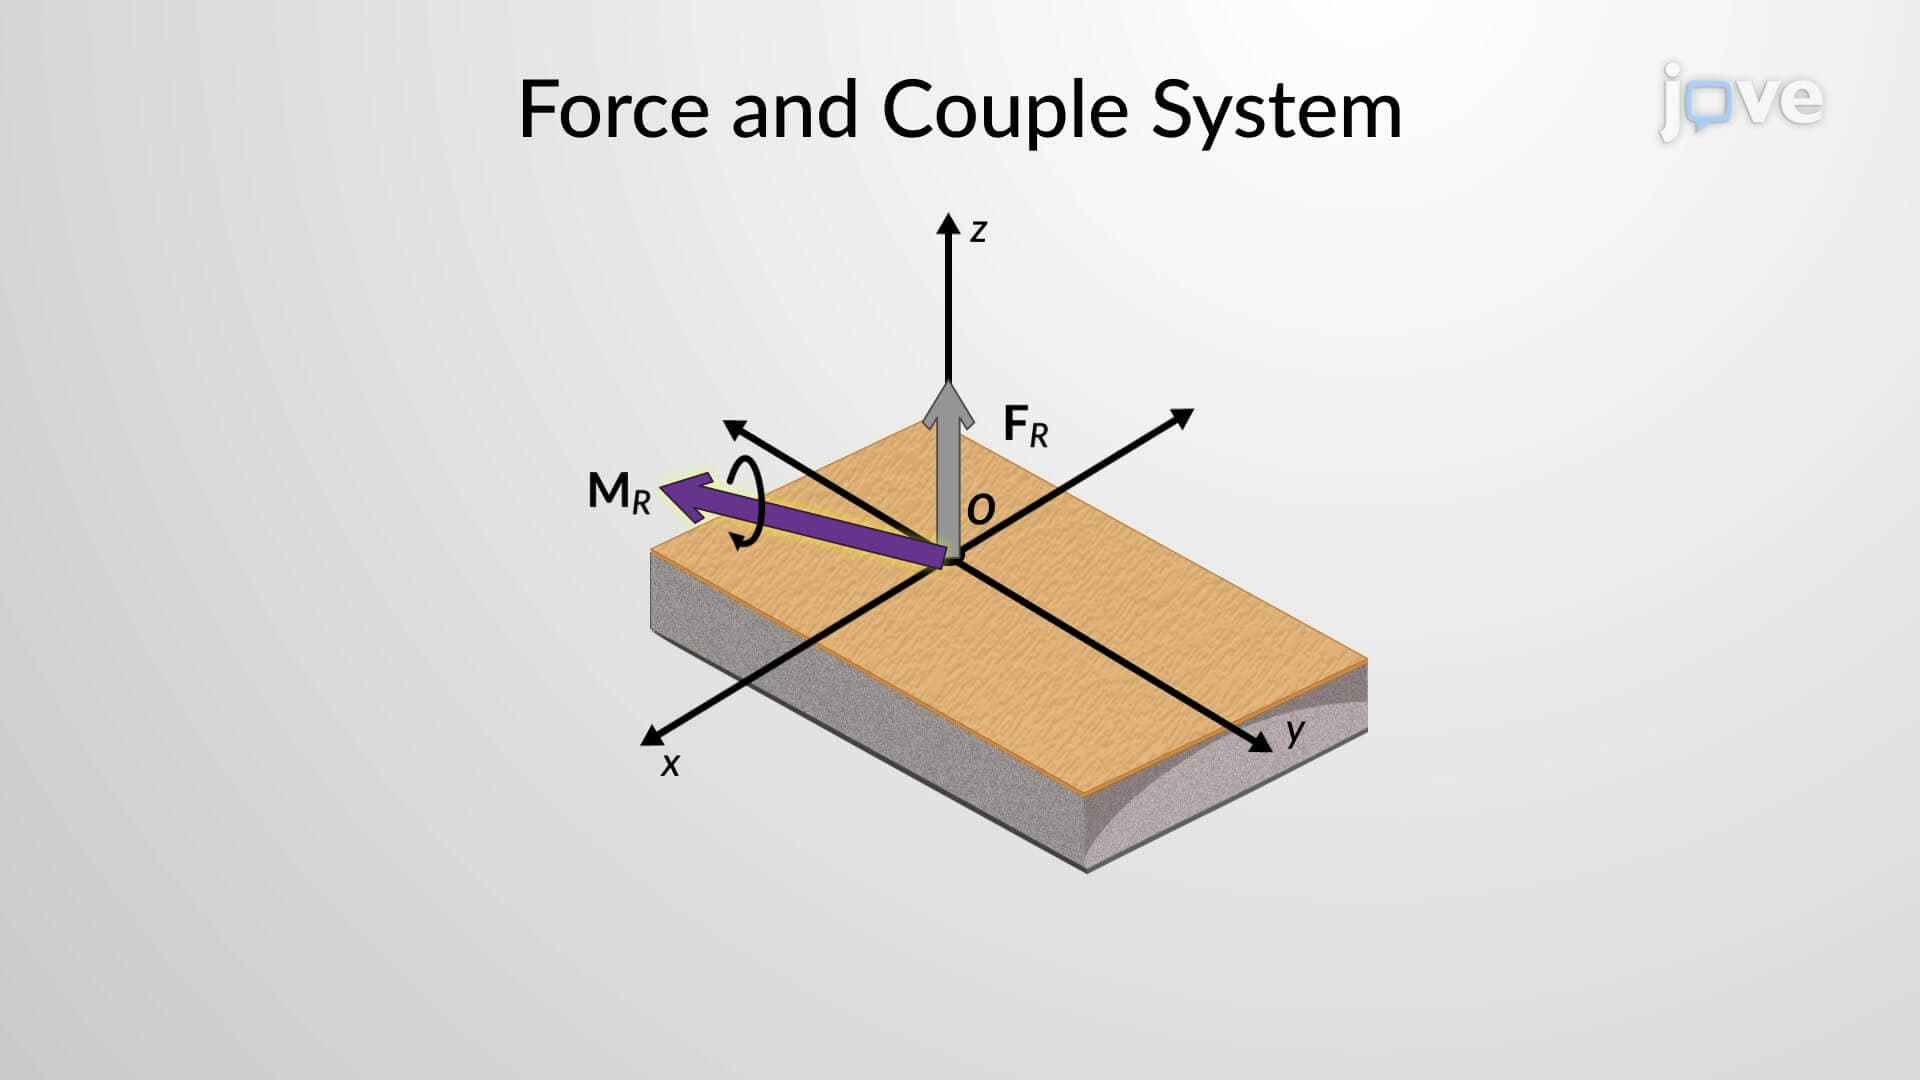
Simplification of a Force and Couple System: II
 01:29
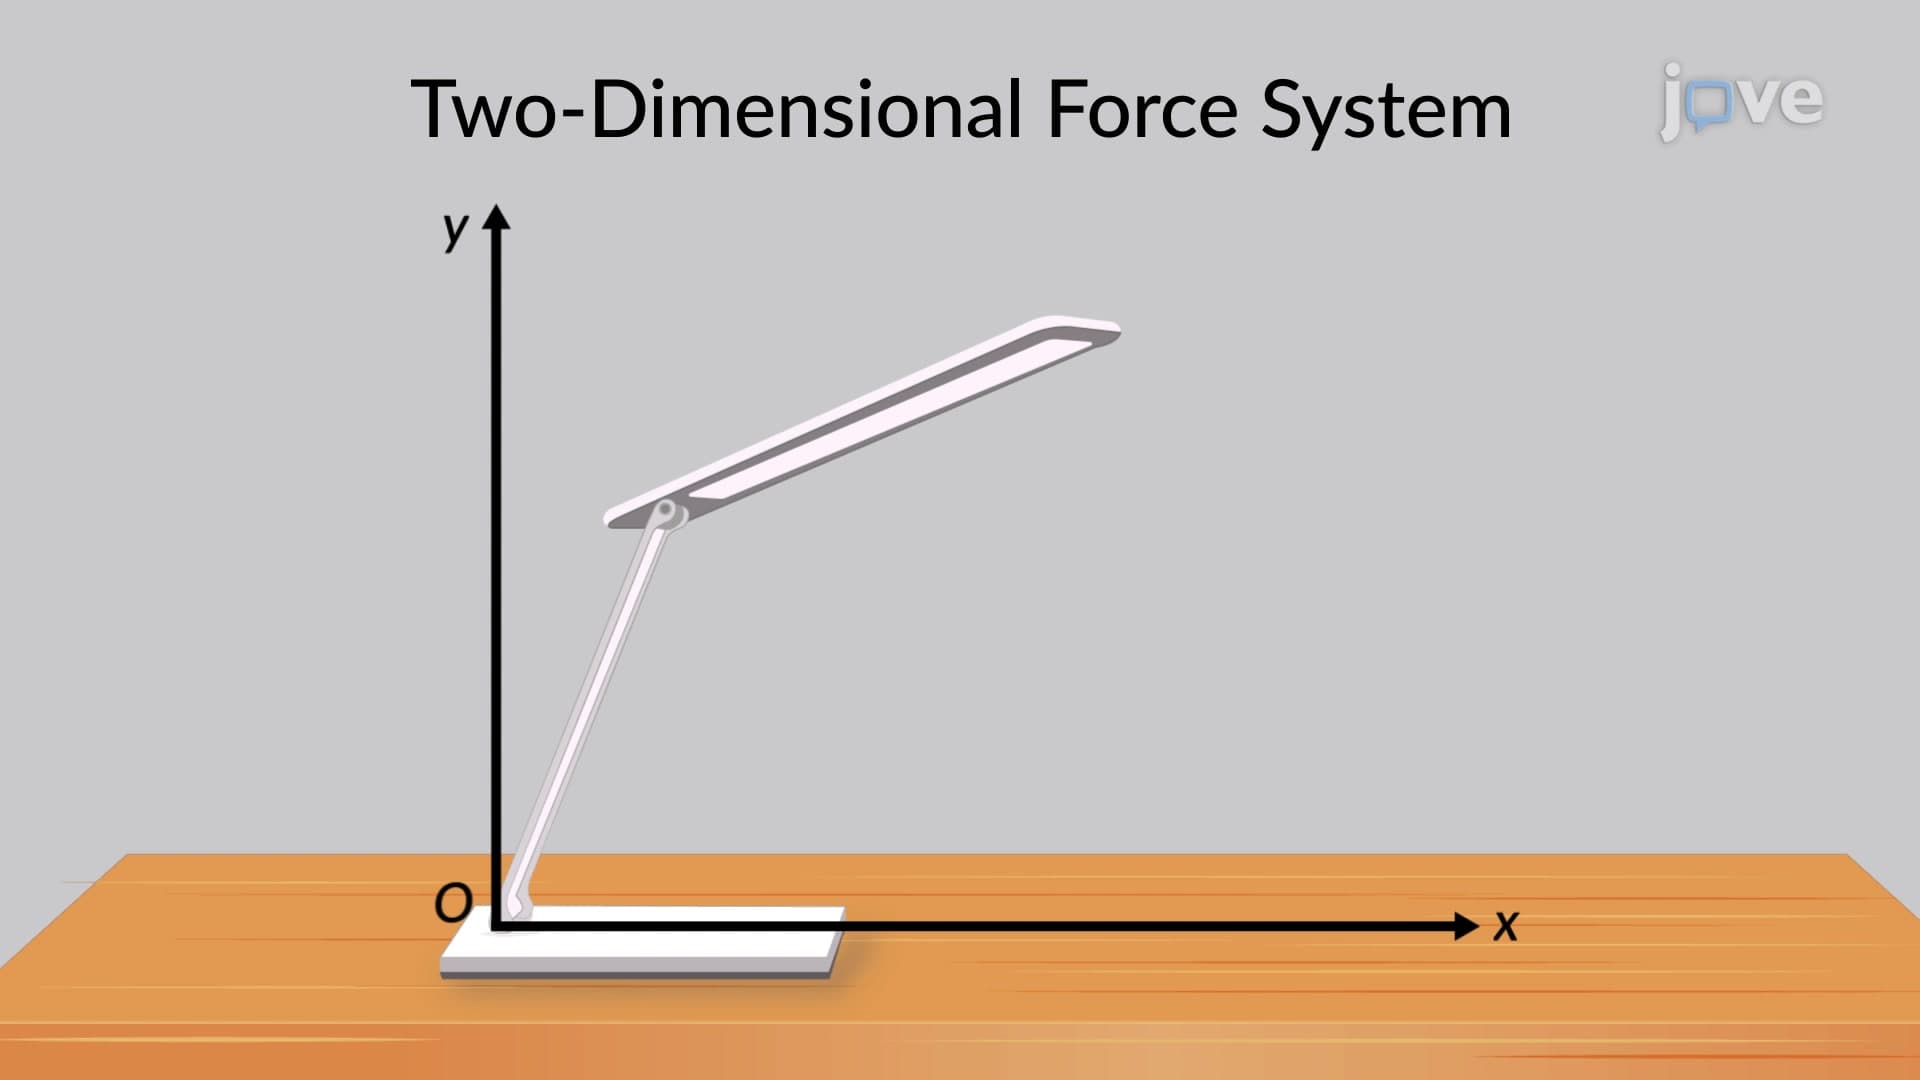
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Three-Dimensional Force System
 01:20
Two-Dimensional Force System