Related Experiment Video
Updated: Mar 25, 2026
Quantifying Intermembrane Distances with Serial Image Dilations
Published on: September 28, 2018
Efficient tracking of the dominant eigenspace of a normalized kernel matrix
Geert Gins1, Ilse Y Smets, Jan F Van Impe
1Bioprocess Technology and Control, Katholieke Universiteit Leuven, W de Croylaan 46, B-3001, Leuven, Belgium. geert.gins@cit.kuleuven.be

Abstract:
Various machine learning problems rely on kernel-based methods. The power of these methods resides in the ability to solve highly nonlinear problems by reformulating them in a linear context. The dominant eigenspace of a (normalized) kernel matrix is often required. Unfortunately, the computational requirements of the existing kernel methods are such that the applicability is restricted to relatively small data sets. This letter therefore focuses on a kernel-based method for large data sets. More specifically, a numerically stable tracking algorithm for the dominant eigenspace of a normalized kernel matrix is proposed, which proceeds by an updating (the addition of a new data point) followed by a downdating (the exclusion of an old data point) of the kernel matrix. Testing the algorithm on some representative case studies reveals that a very good approximation of the dominant eigenspace is obtained, while only a minimal amount of operations and memory space per iteration step is required.
Related Concept Videos
 01:26
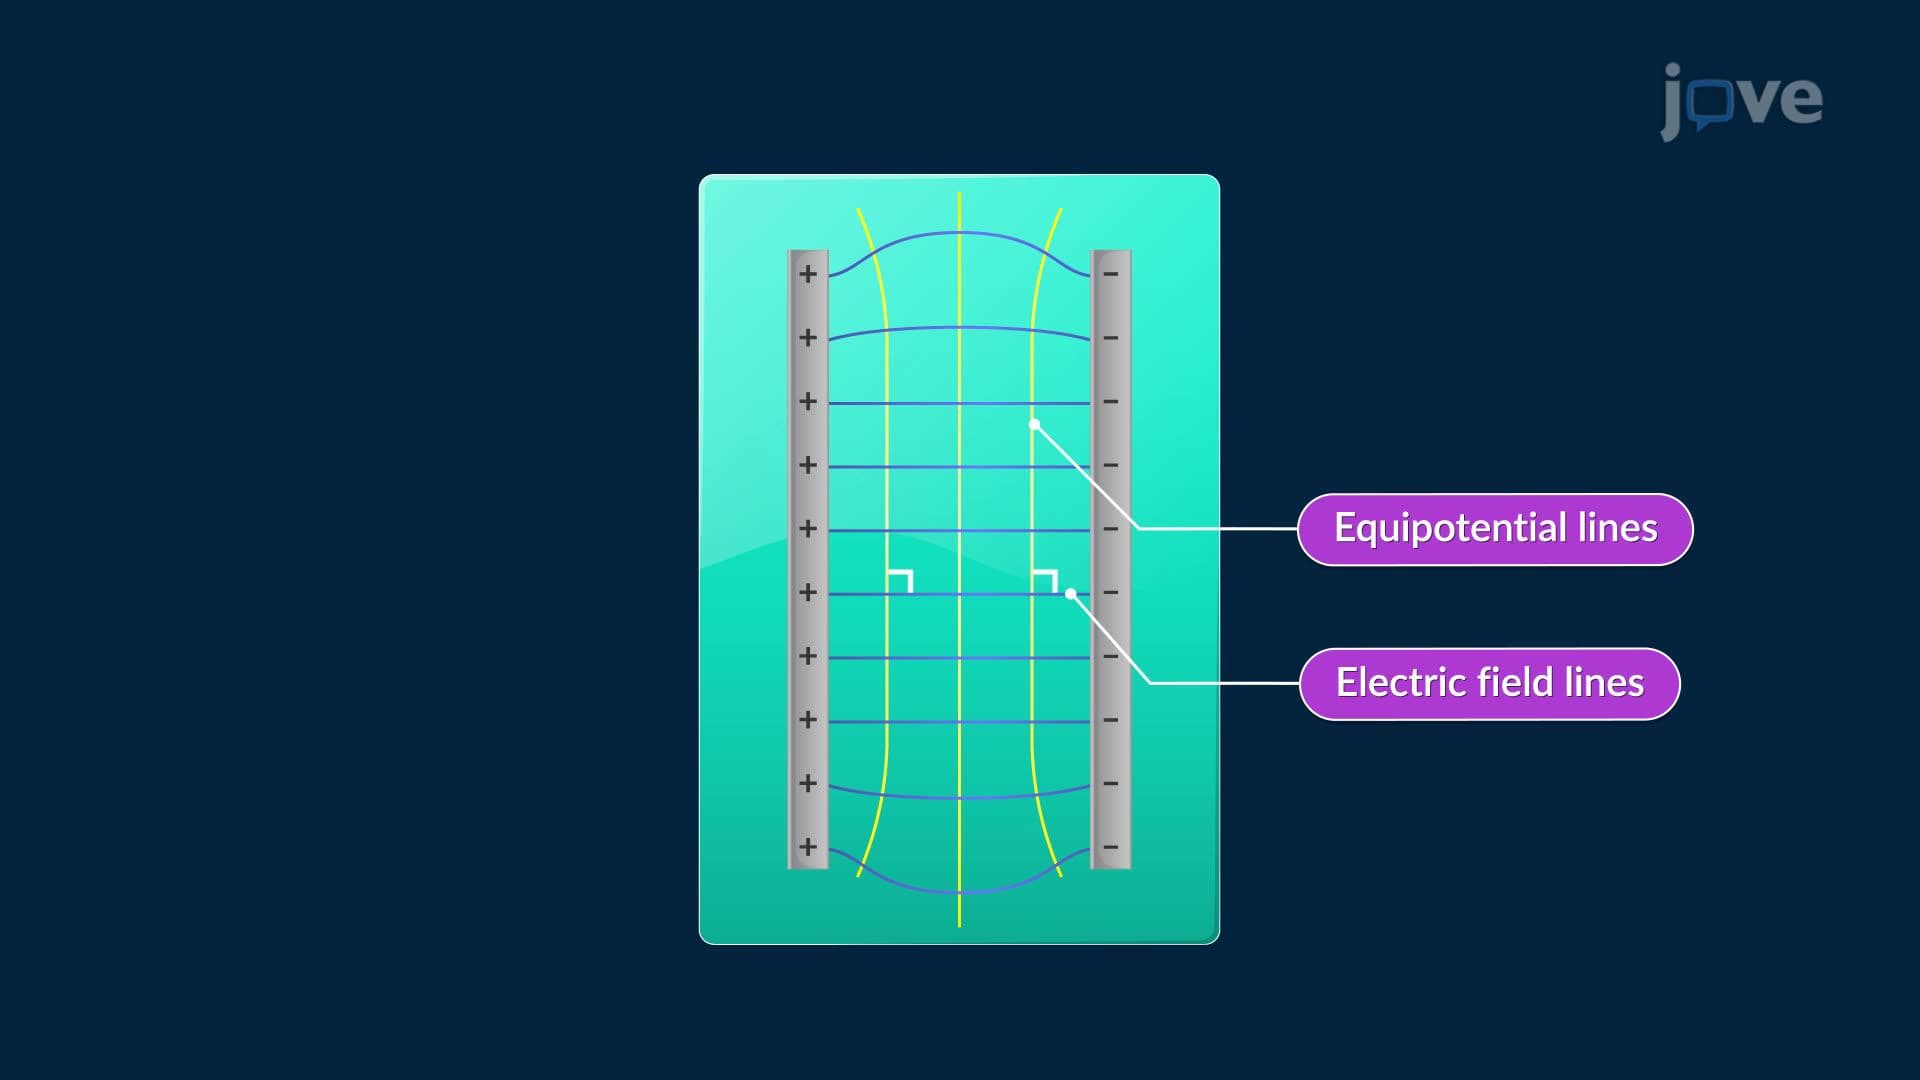
Orthogonal Trajectories
 01:30
Gaussian Elimination: Problem Solving
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:14
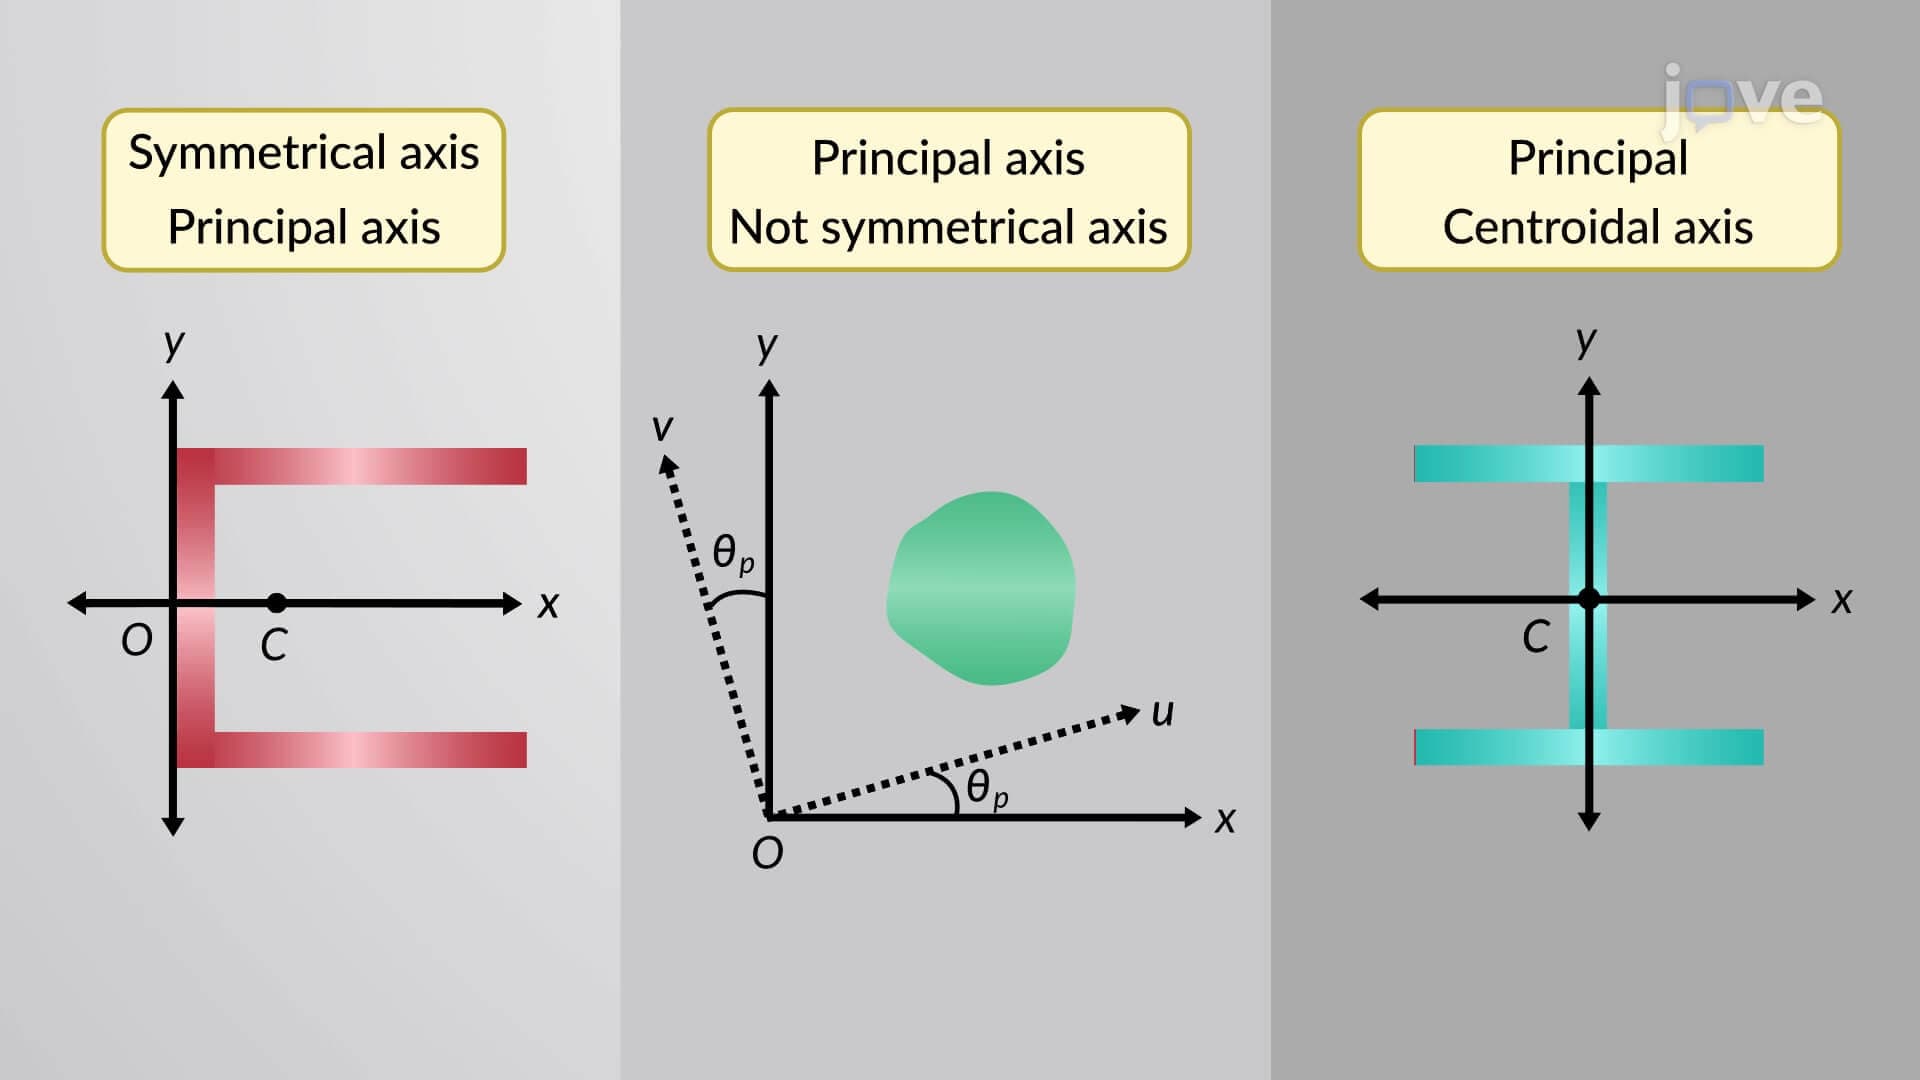
Principal Moments of Area
The principal moment of inertia axes are the...
 01:29
Position Vectors
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...