Related Experiment Videos
Gradient-based residual variance modeling and its applications to motion-compensated video coding
1Electrical Engineering Department, Princeton University, Princeton, NJ 08540, USA. bo.tao@streaming21.com

Abstract:
This paper analyzes the relationship between the residual frame and the previous frame in motion-compensated video coding. It is found that the variance of the residual signal depends on the gradient magnitude. On average, the variance of the residual signal is larger for pixels with larger gradient magnitude. Two applications of this analysis are presented. In the first one, the relationship between the residual signal variance and the gradient magnitude is used to model the second-order statistics of the residual field in a nonstationary way. This modeling enables more efficient residual signal coding. The other application is for pixel decimation-based fast block matching. It is proposed that pixels with the largest gradient magnitude in a block be chosen to participate in the block matching process. It is demonstrated that such a gradient-adaptive subsampling achieves great advantage over two other known subsampling methods.
Related Concept Videos
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:19
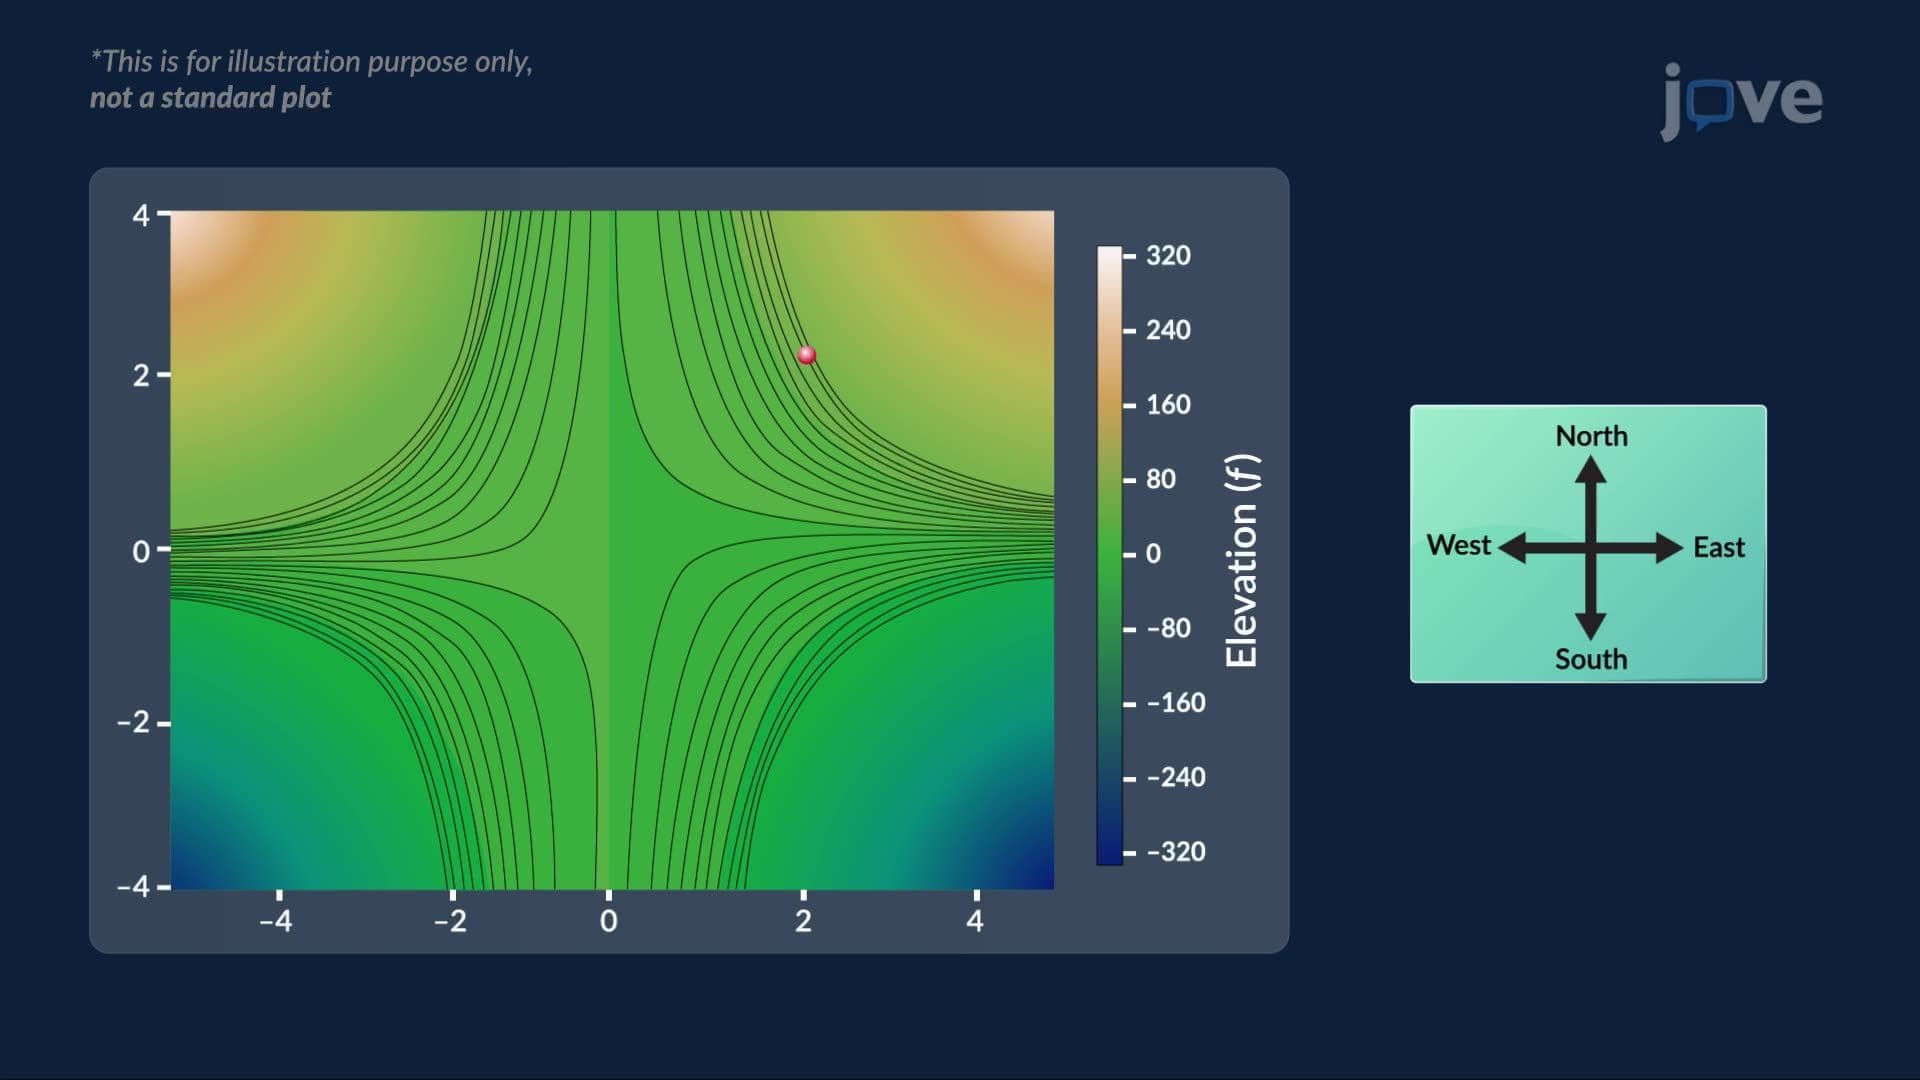
Gradient Vectors and Their Applications
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...