Related Experiment Video
Updated: Jul 7, 2026


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Location and stability of the high-gain equilibria of nonlinear neural networks
1Centre for Artificial Intelligence and Robotics, Bangladore.

Abstract:
The author analyzes the number, location, and stability behavior of the equilibria of arbitrary nonlinear neural networks without resorting to energy arguments based on assumptions of symmetric interactions or no self-interactions. The class of networks studied consists of very general continuous-time continuous-state (CTCS) networks that contain the standard Hopfield network as a special case. The emphasis is on the case where the slopes of the sigmoidal nonlinearities become larger and larger.
Related Concept Videos
 01:19
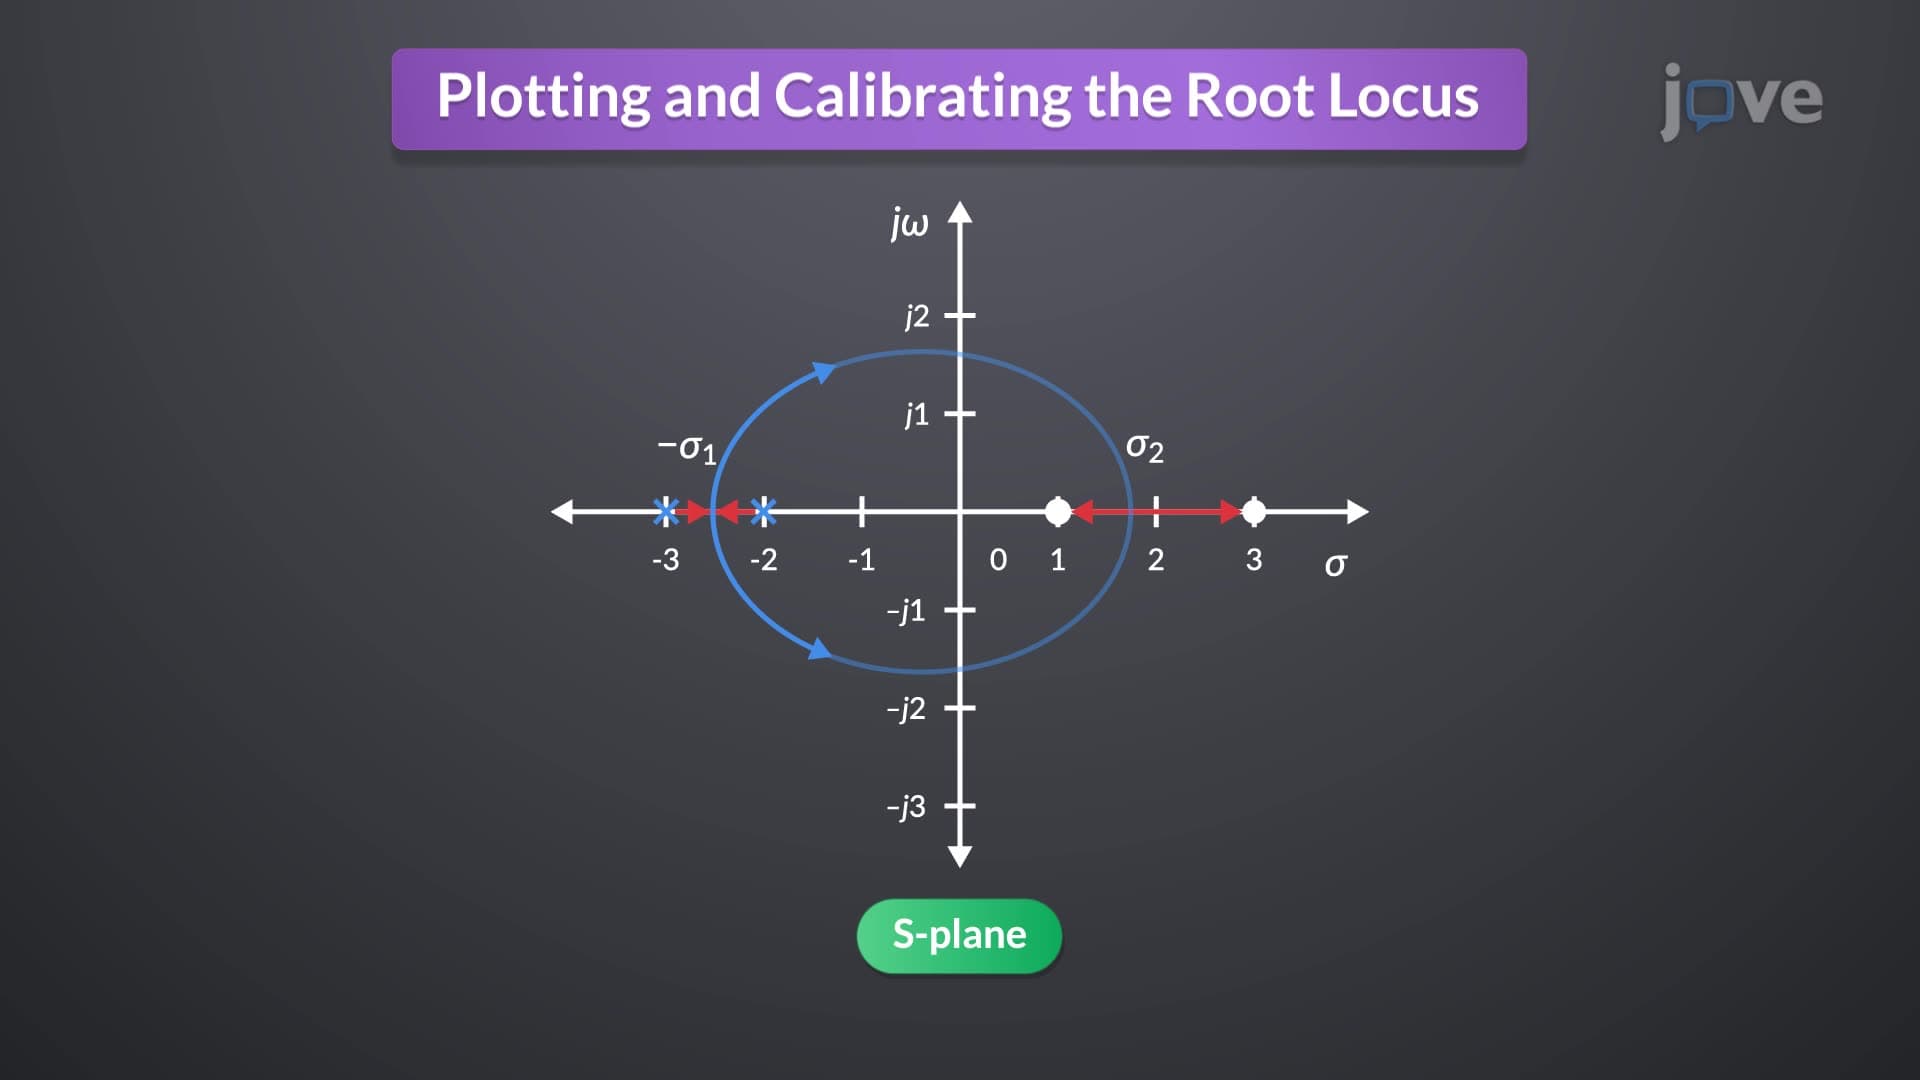
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:23
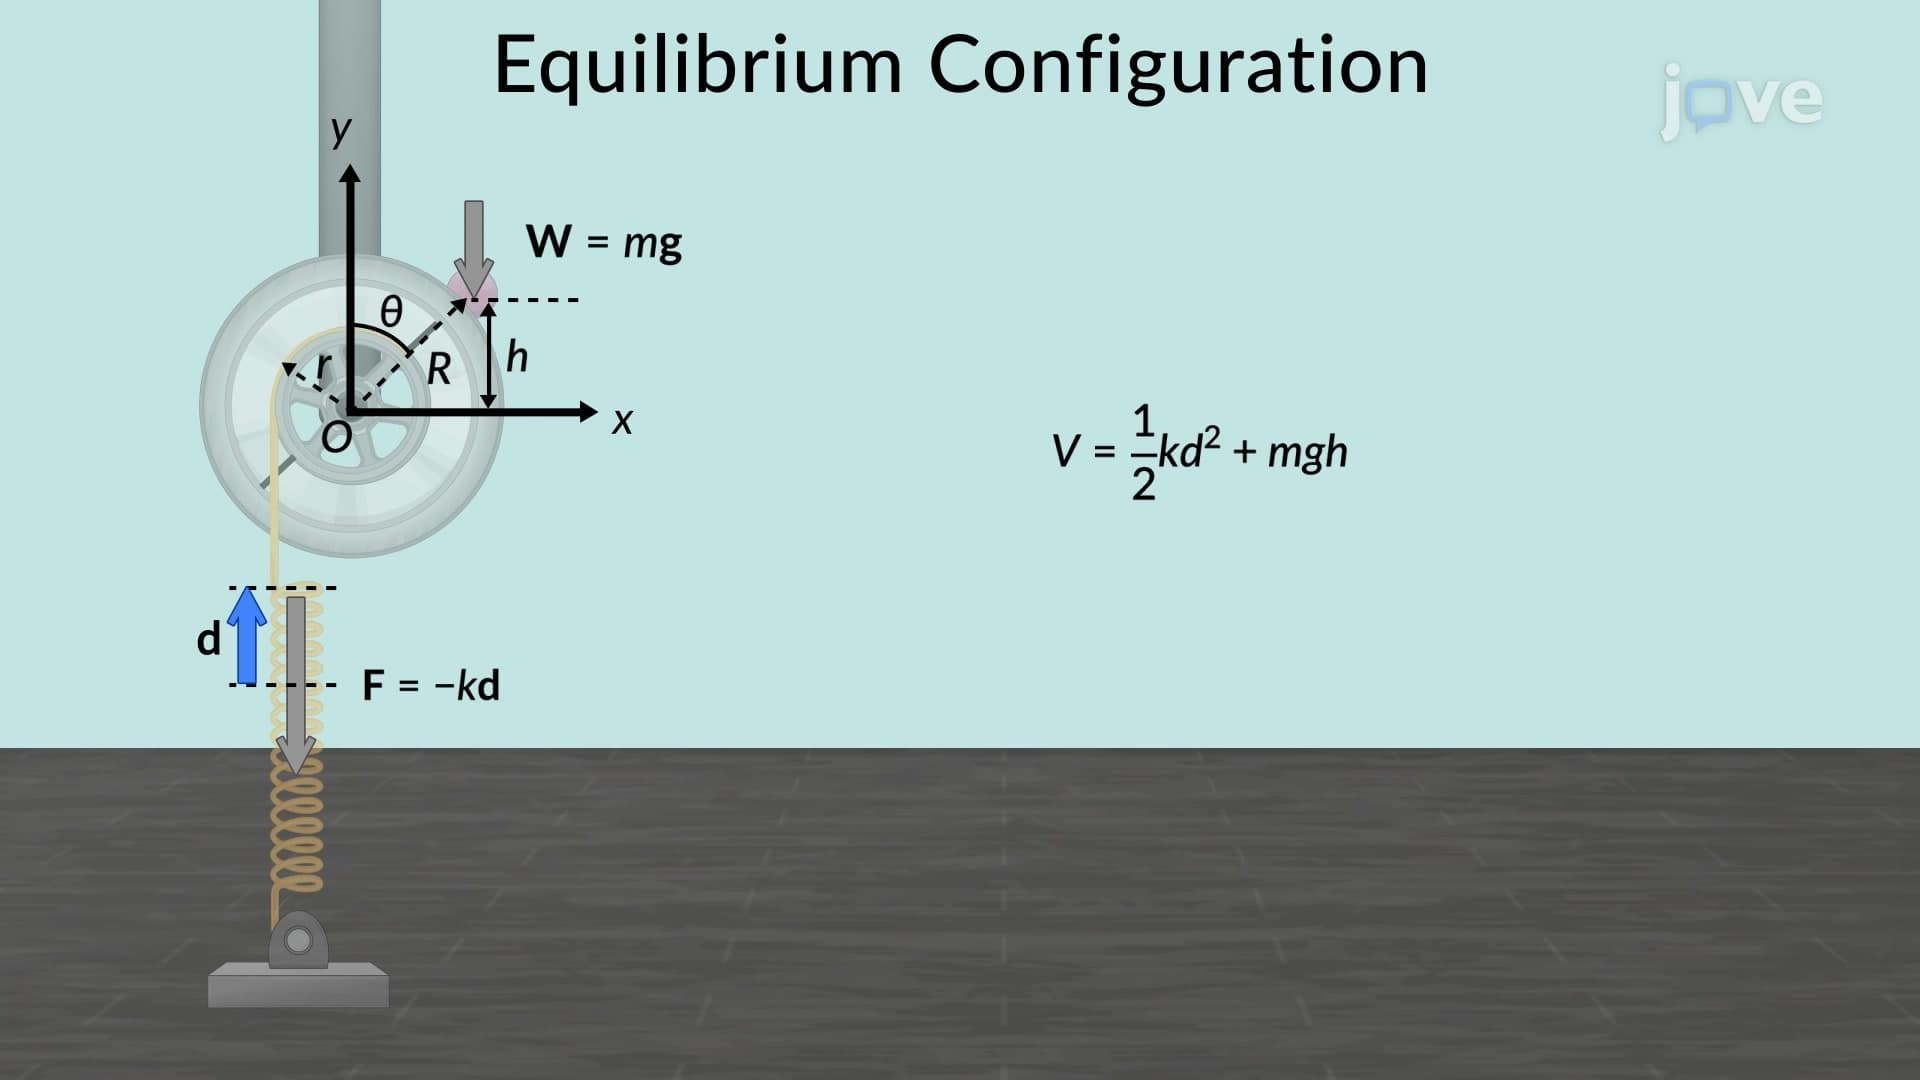
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:04
Oscillations about an Equilibrium Position
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...