Related Experiment Video
Updated: Jul 7, 2026

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
A new motion-compensated reduced-order model Kalman filter for space-varying restoration of progressive and
A J Patti1, A M Tekalp, M I Sezan
1Hewlett-Packard Co., Palo Alto, CA 94304-1126, USA. patti@hpl.hp.com

Abstract:
We propose a new approach for motion-compensated, reduced order model Kalman filtering for restoration of progressive and interlaced video. In the case of interlaced inputs, the proposed filter also performs deinterlacing. In contrast to the literature, both motion-compensation and reduced-order state modeling are achieved by augmenting the observation equation, as opposed to modifying the state-transition equation. The proposed modeling, which includes the two-dimensional (2-D) reduced order model Kalman filtering (ROMKF) of Angwin and Kaufman as a special case, results in significant performance improvement in fixed-lag Kalman filtering of space-varying blurred images. This is demonstrated by experimental results.
Related Concept Videos
 01:10
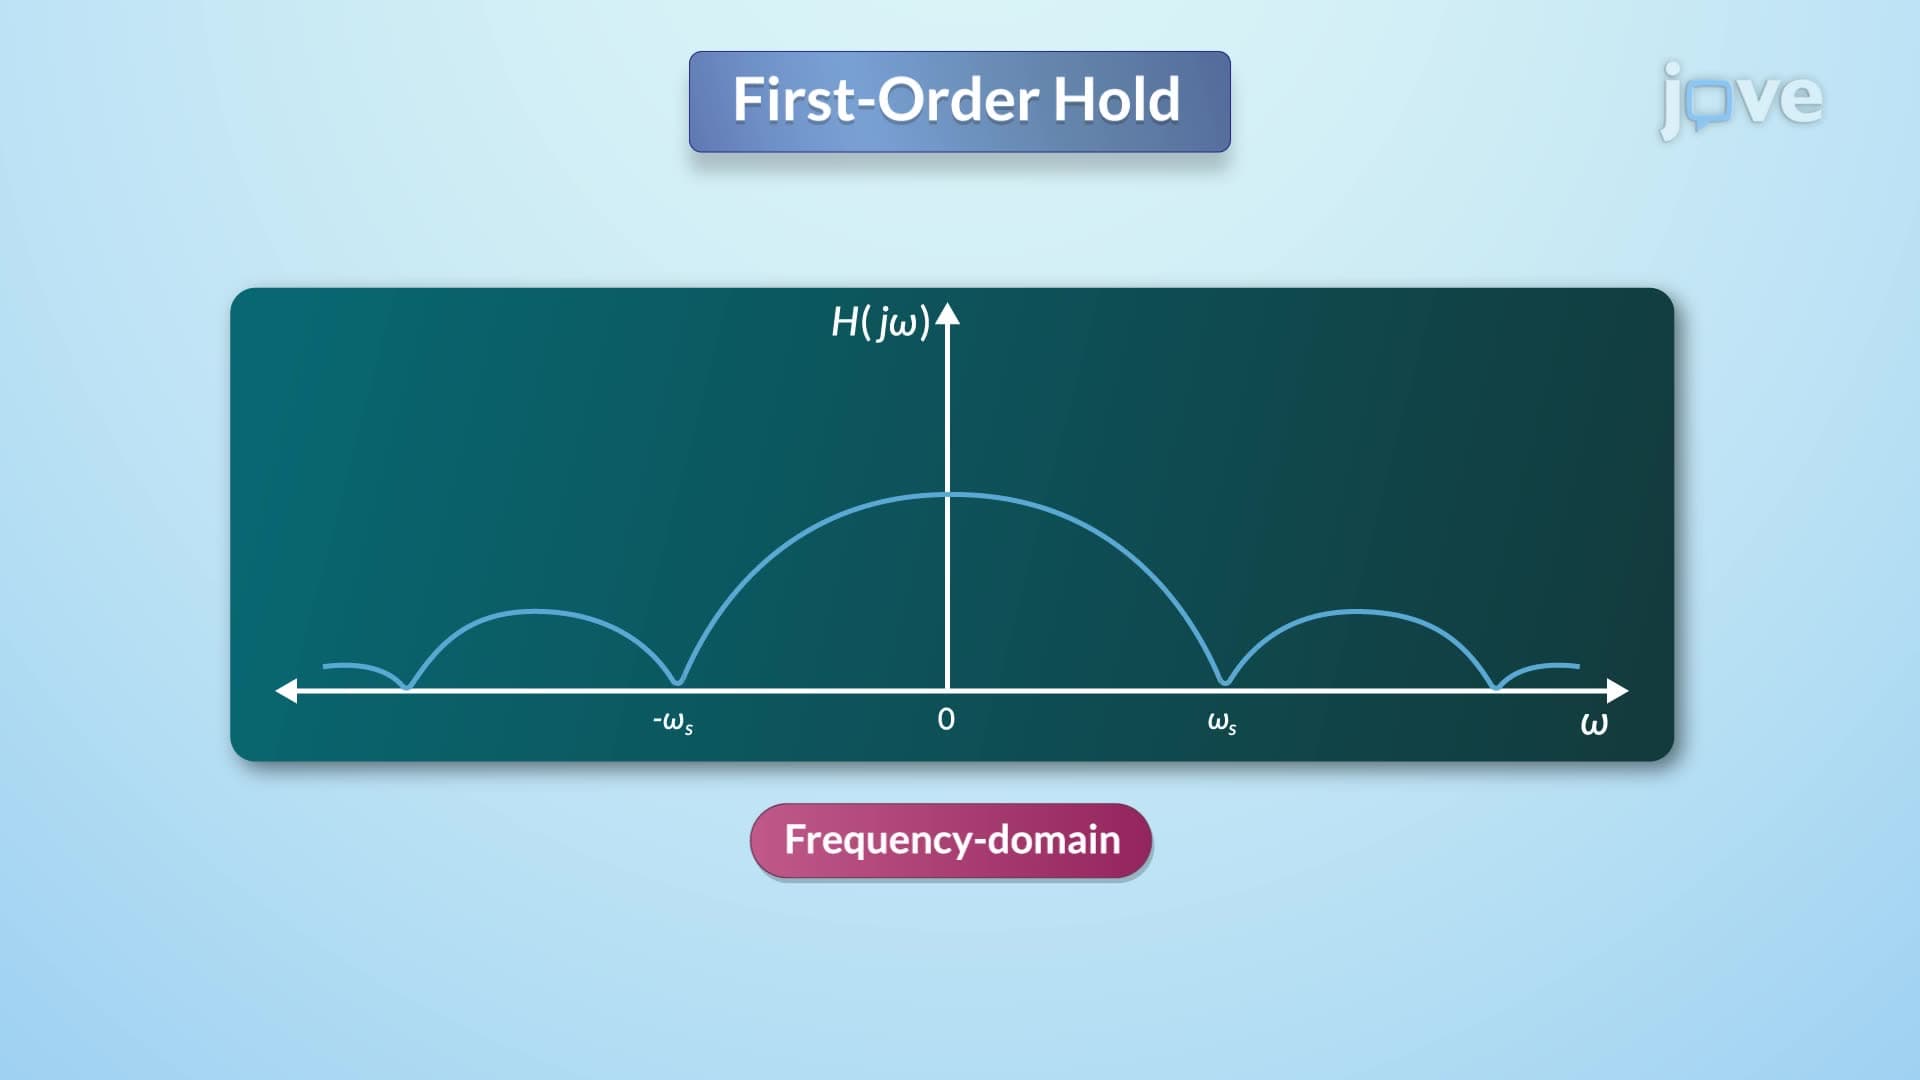
Reconstruction of Signal using Interpolation
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...