Robust B-spline image modeling with application to image processing

Related Concept Videos

Real-World Applications of Space Curves01:29

Real-World Applications of Space Curves

Modern aerospace navigation depends on the accurate prediction of motion in three-dimensional space. In defense applications, radar systems continuously track both interceptors and moving aerial targets to find whether their flight paths will result in a collision. These motions are modeled mathematically as space curves, which represent paths that change continuously with time. Each object’s position is described by a vector function that specifies its location in terms of time-dependent...
Imaging Biological Samples with Optical Microscopy01:18

Imaging Biological Samples with Optical Microscopy

Optical microscopy uses optic principles to provide detailed images of samples. Antonie van Leeuwenhoek designed the first compound optical microscope in the 17th century to visualize blood cells, bacteria, and yeast cells. In 1830, Joseph Jackson Lister created an essentially modern light microscope. The 20th century saw the development of microscopes with enhanced magnification and resolution.
In optical microscopy, the specimen to be viewed is placed on a glass slide and clipped on the stage...
Convolution: Math, Graphics, and Discrete Signals01:24

Convolution: Math, Graphics, and Discrete Signals

In any LTI (Linear Time-Invariant) system, the convolution of two signals is denoted using a convolution operator, assuming all initial conditions are zero. The convolution integral can be divided into two parts: the zero-input or natural response and the zero-state or forced response, with t0 indicating the initial time.
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
Curvature and Its Interpretation01:25

Curvature and Its Interpretation

Curvature describes how rapidly a curve changes direction at a particular point. A curve with a small curvature bends gently, while a curve with a large curvature turns sharply. For a space curve, the position of a moving object can be described by a vector-valued function r(t), where t often represents time. The direction of motion is determined by the tangent vector, and the unit tangent vector is obtained by normalizing the derivative of the position vector.The unit tangent vector gives the...
Reconstruction of Signal using Interpolation01:10

Reconstruction of Signal using Interpolation

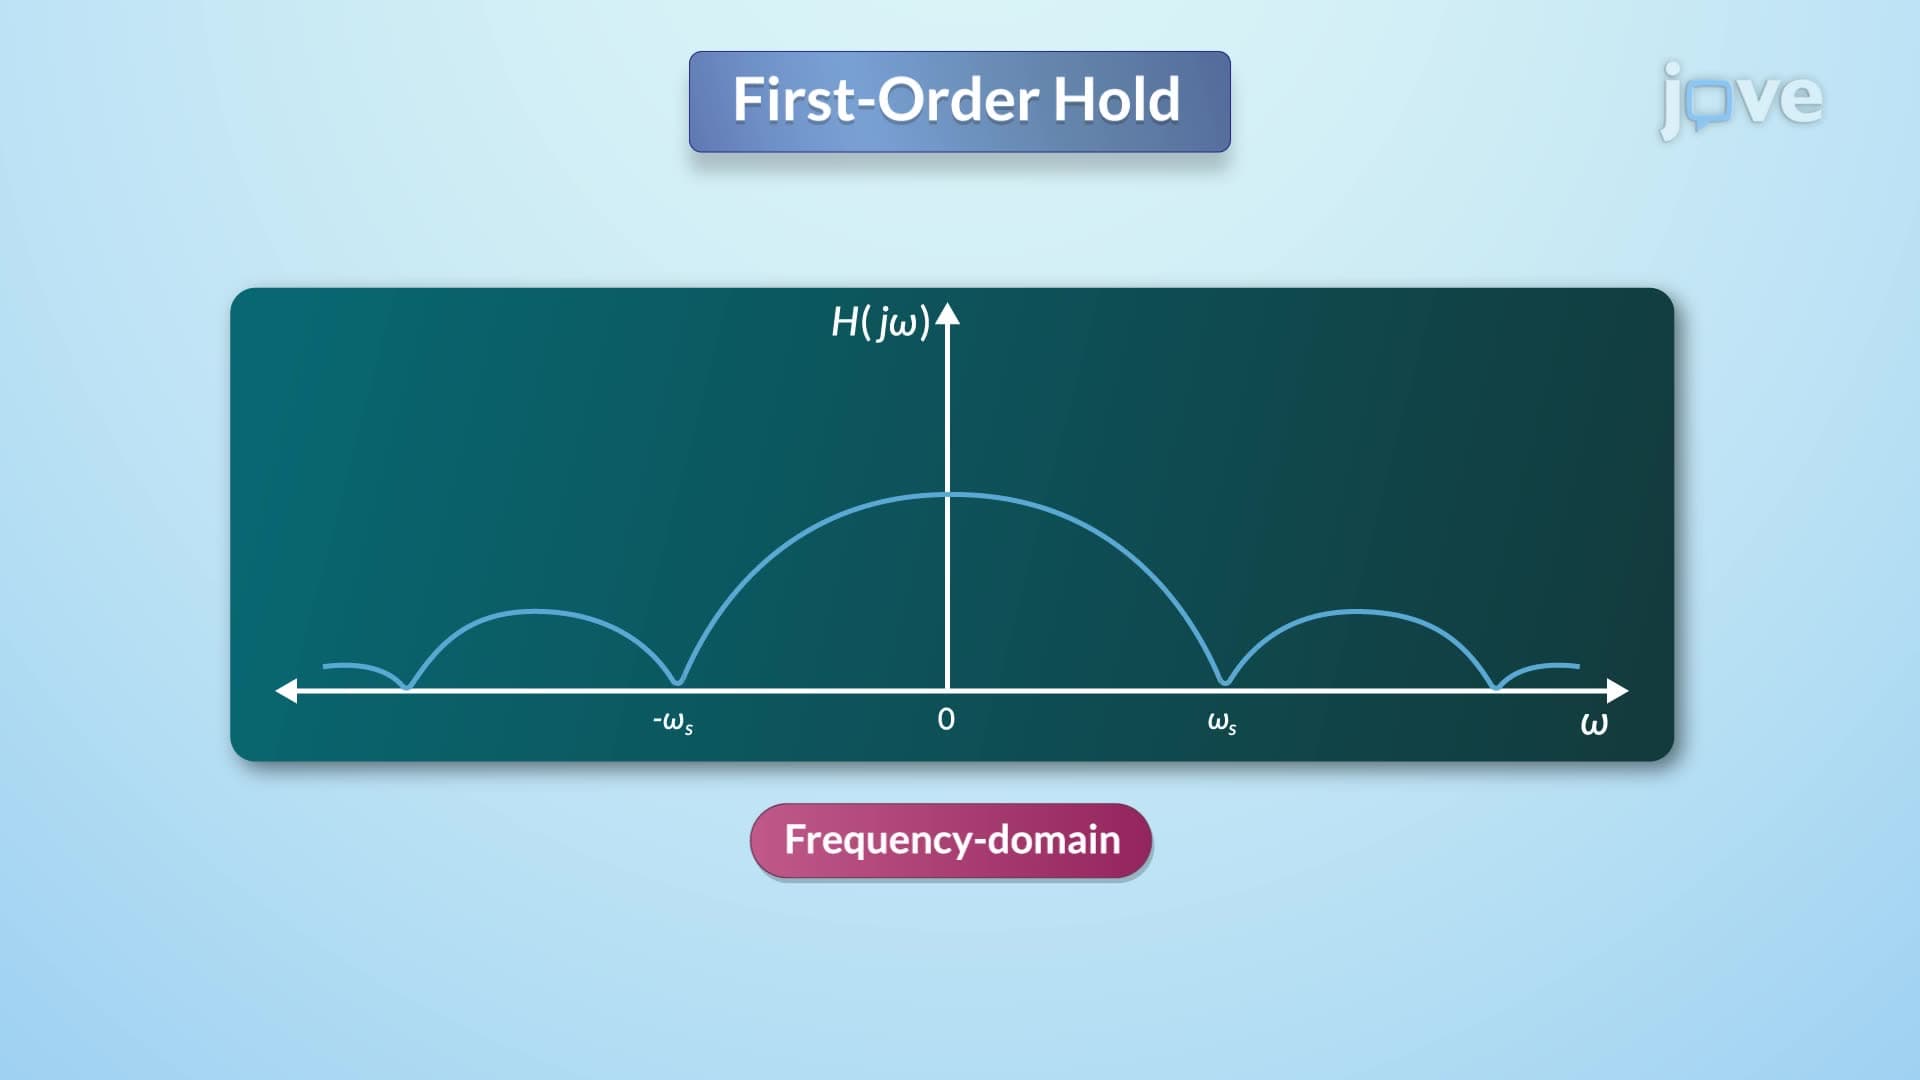
Signal processing techniques are essential for accurately converting continuous signals to digital formats and vice versa. When a continuous signal is sampled with a period T, the resulting sampled signal exhibits replicas of the original spectrum in the frequency domain, spaced at intervals equal to the sampling frequency. To handle this sampled signal, a zero-order hold method can be applied, which creates a piecewise constant signal by retaining each sample's value until the next sampling...
Curvilinear Motion: Rectangular Components01:23

Curvilinear Motion: Rectangular Components

Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...