Related Experiment Video
Updated: Jul 6, 2026

Visually Based Characterization of the Incipient Particle Motion in Regular Substrates: From Laminar to Turbulent Conditions
Published on: February 22, 2018
Prevalence of marginally unstable periodic orbits in chaotic billiards
E G Altmann1, T Friedrich, A E Motter
1Max-Planck-Institut für Physik komplexer Systeme, 01187 Dresden, Germany.

Abstract:
The dynamics of chaotic billiards is significantly influenced by coexisting regions of regular motion. Here we investigate the prevalence of a different fundamental structure, which is formed by marginally unstable periodic orbits and stands apart from the regular regions. We show that these structures both exist and strongly influence the dynamics of locally perturbed billiards, which include a large class of widely studied systems. We demonstrate the impact of these structures in the quantum regime using microwave experiments in annular billiards.
Related Concept Videos
 01:28
Conservation of Linear Momentum for a System of Particles
The impulsive force at play during this interaction is of extremely short duration, rendering its impulse negligible. When...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:04
Oscillations about an Equilibrium Position
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:13
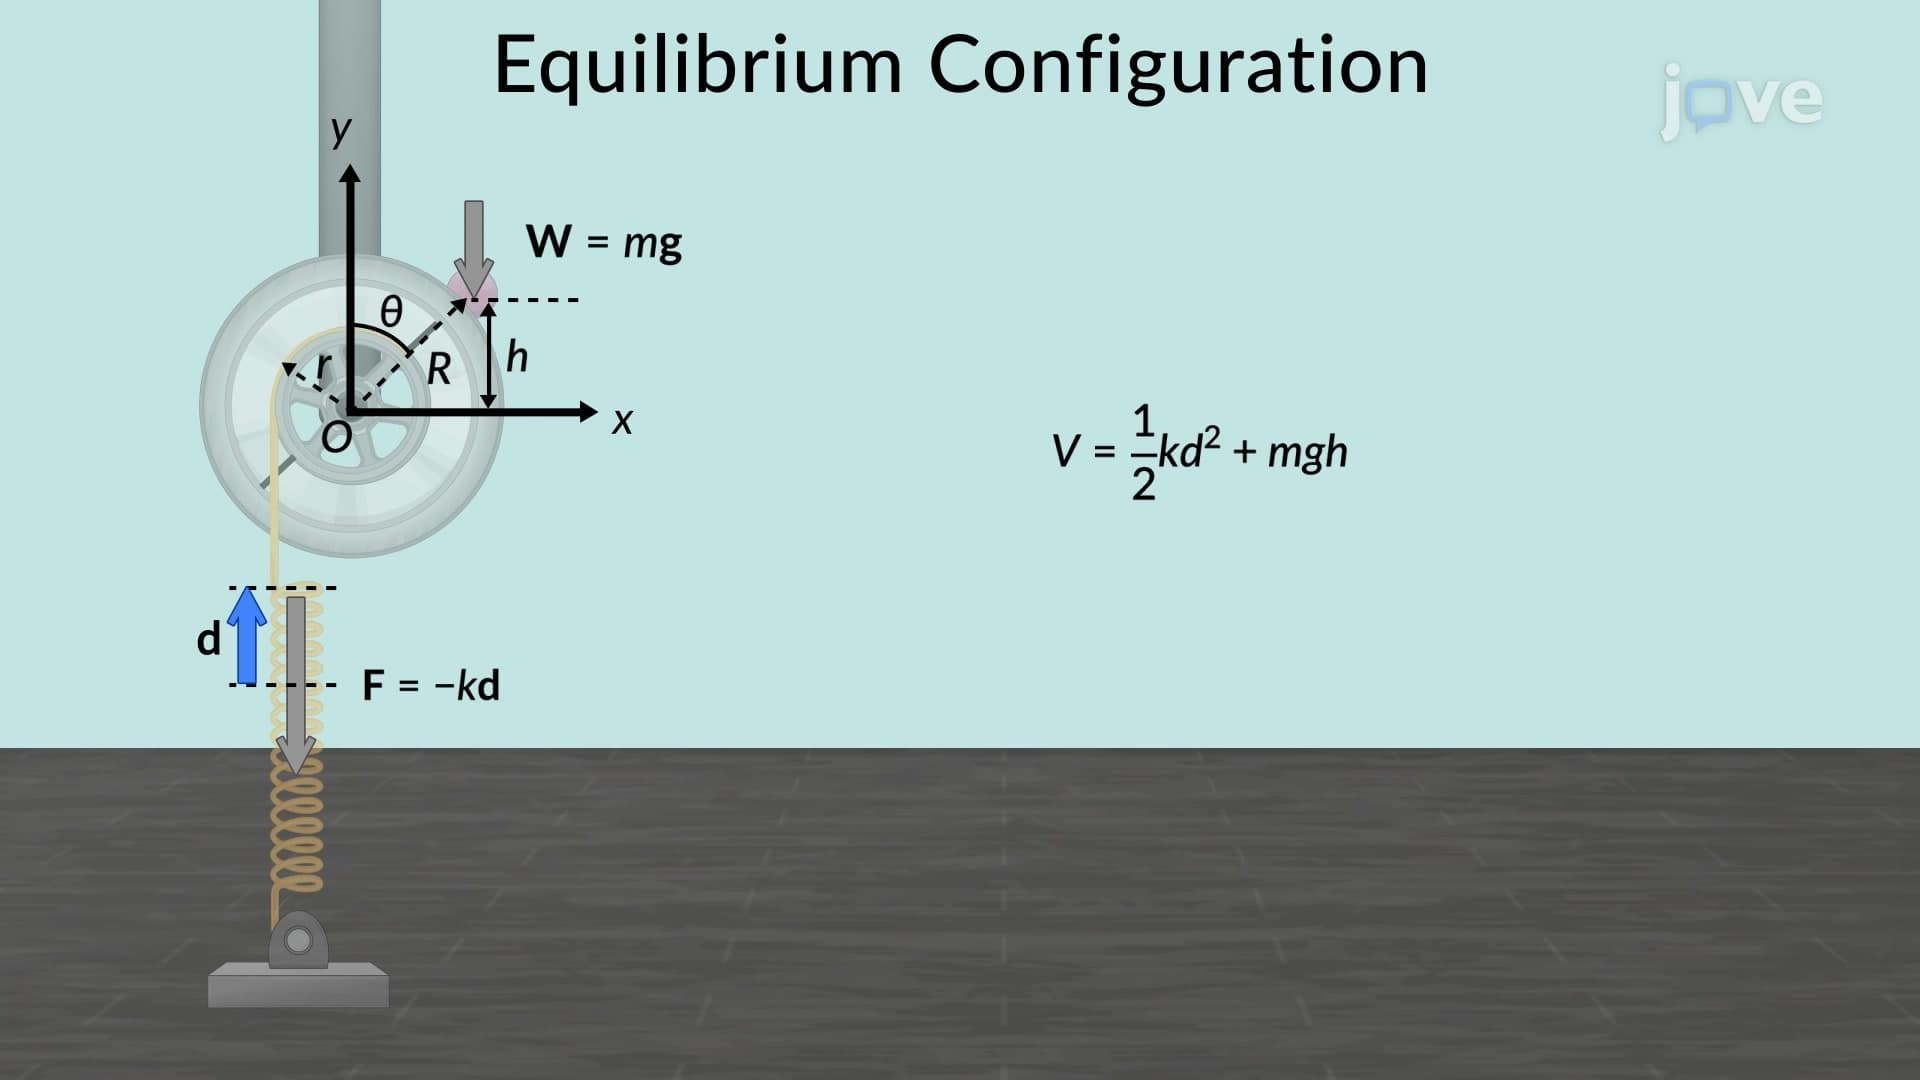
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.