Related Experiment Video
Updated: Jul 5, 2026

Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Position and Orientation Distributions for Locally Self-Avoiding Walks in the Presence of Obstacles
Aris Skliros1, Gregory S Chirikjian
1Department of Mechanical Engineering, Johns Hopkins University, Baltimore, MD 21218, USA,

Abstract:
This paper presents a new approach to study the statistics of lattice random walks in the presence of obstacles and local self-avoidance constraints (excluded volume). By excluding sequentially local interactions within a window that slides along the chain, we obtain an upper bound on the number of self-avoiding walks (SAWs) that terminate at each possible position and orientation. Furthermore we develop a technique to include the effects of obstacles. Thus our model is a more realistic approximation of a polymer chain than that of a simple lattice random walk, and it is more computationally tractable than enumeration of obstacle-avoiding SAWs. Our approach is based on the method of the lattice-motion-group convolution. We develop these techniques theoretically and present numerical results for 2-D and 3-D lattices (square, hexagonal, cubic and tetrahedral/diamond). We present numerical results that show how the connectivity constant mu changes with the length of each self-avoiding window and the total length of the chain. Quantities such as R and others such as the probability of ring closure are calculated and compared with results obtained in the literature for the simple random walk case.

Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Oriented Surfaces
 01:26
Orthogonal Trajectories
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions
 01:00
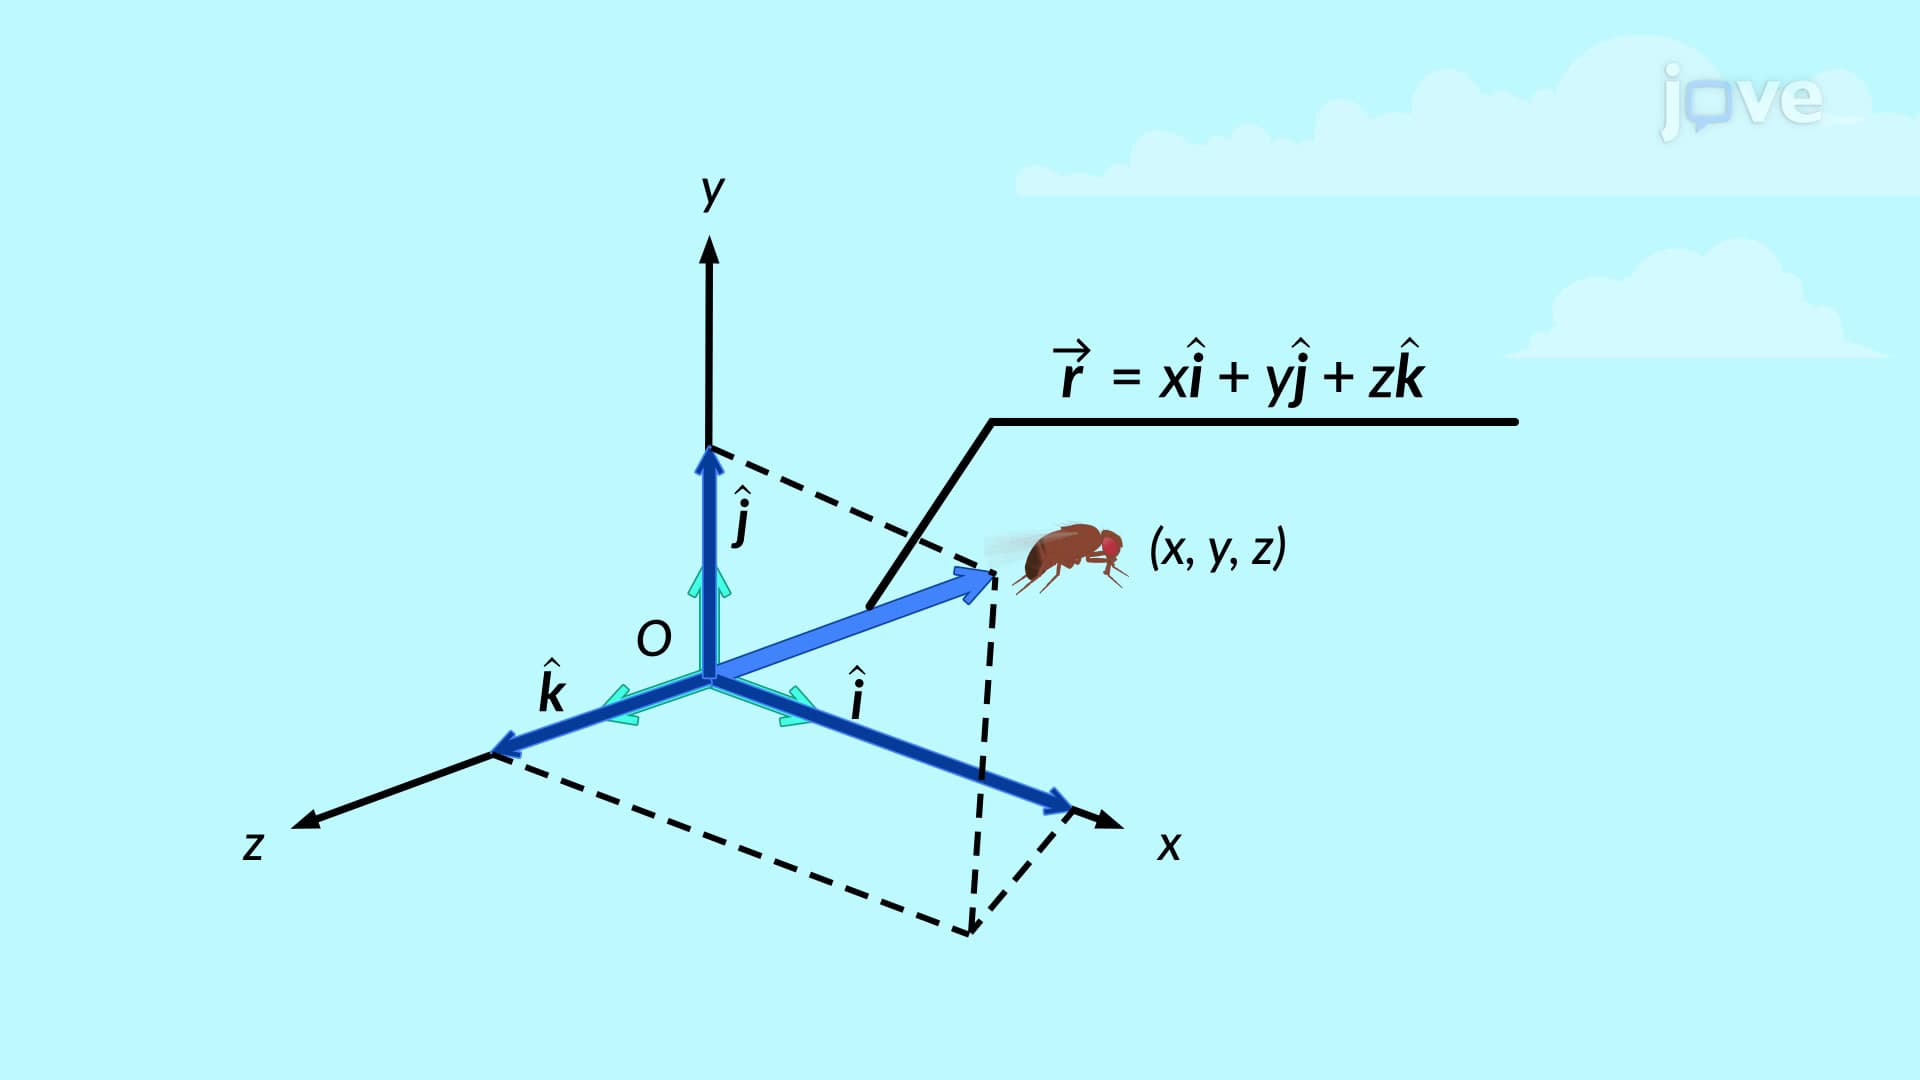
Position and Displacement Vectors
Further, several important kinds of...