Related Experiment Video
Updated: Jul 4, 2026
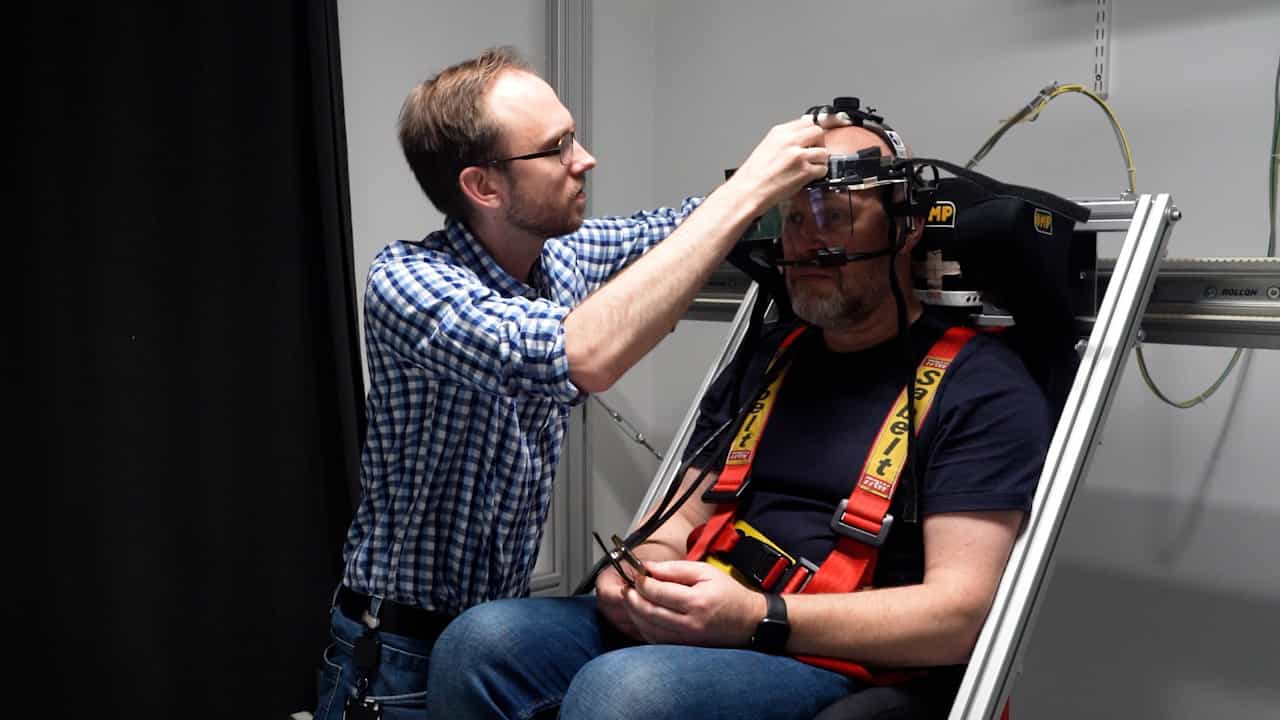

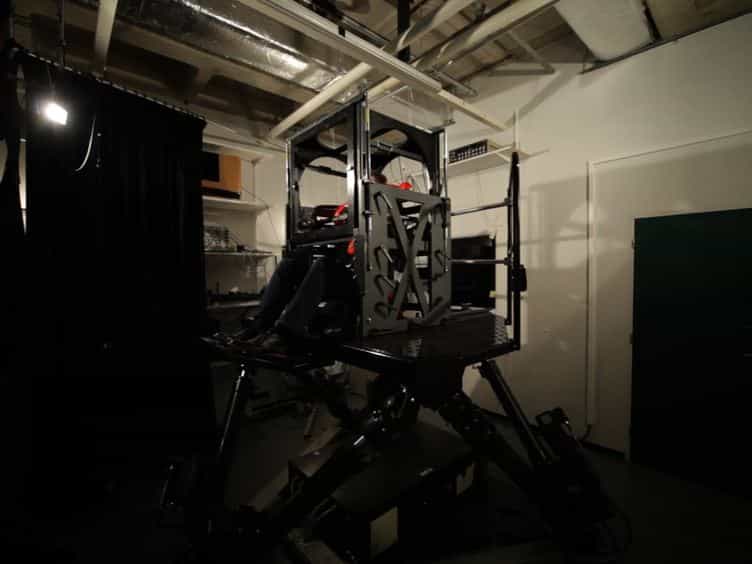
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
An adaptive gaze stabilization controller inspired by the vestibulo-ocular reflex
A Lenz1, T Balakrishnan, A G Pipe
1Bristol Robotics Laboratories, University of Bristol & University of the West of England, Bristol Business Park, Coldharbour Lane, Bristol, BS16 1QD, GB, UK. alex.lenz@brl.ac.uk

Abstract:
The vestibulo-ocular reflex stabilizes vision in many vertebrates. It integrates inertial and visual information to drive the eyes in the opposite direction to head movement and thereby stabilizes the image on the retina. Its adaptive nature guarantees stable vision even when the biological system undergoes dynamic changes (due to disease, growth or fatigue etc), a characteristic especially desirable in autonomous robotic systems. Based on novel, biologically plausible neurological models, we have developed a robotic testbed to qualitatively evaluate the performance of these algorithms. We show how the adaptive controller can adapt to a time varying plant and elaborate how this biologically inspired control architecture can be employed in general engineering applications where sensory feedback is very noisy and/or delayed.
Related Concept Videos
 01:29
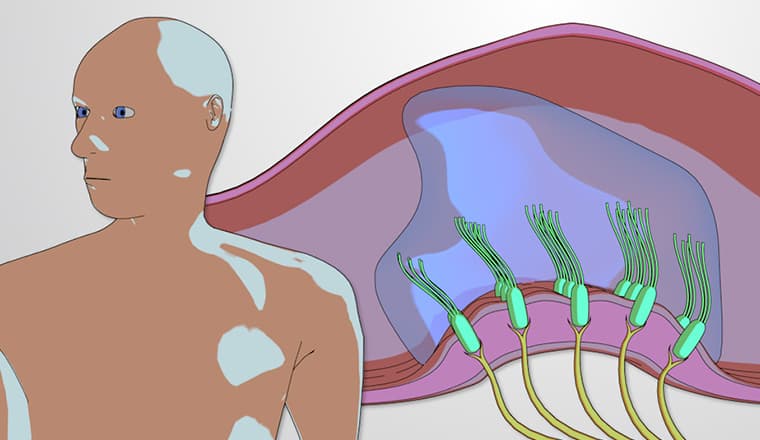
The Vestibular System
 01:02
Gyroscope
 01:20
Muscles of the Eye
Extraocular Muscles
The six extraocular muscles surround the eyeball and control its movements. They are responsible for a wide range of eye motions, including looking up, down, left, right, and rotating...
 01:17
Accessory Structures of the Eye
 01:24
Gyroscope: Precession