Related Experiment Video
Updated: Jul 2, 2026
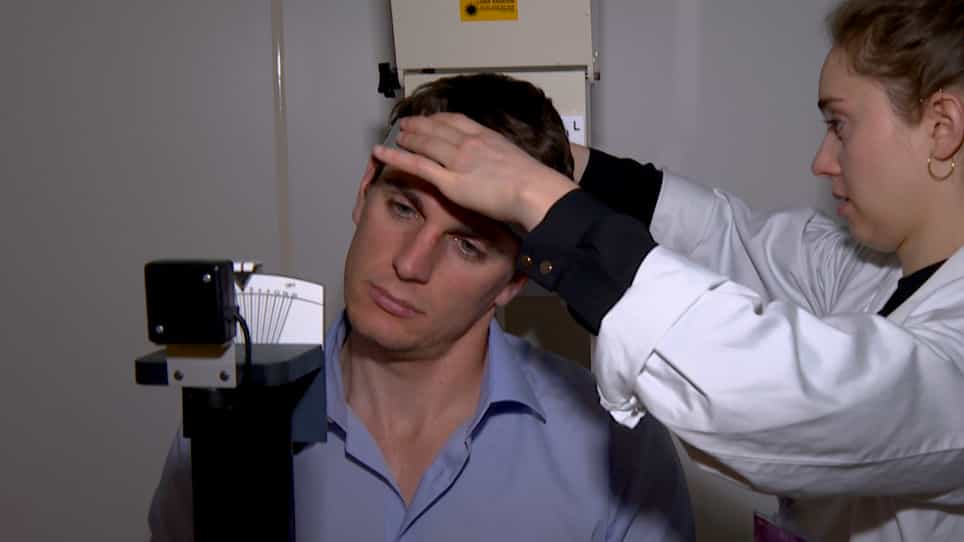

Assessment of Static Graviceptive Perception in the Roll-Plane using the Subjective Visual Vertical Paradigm
Published on: April 28, 2020
Hysteresis effects of the subjective visual vertical during continuous quasi-static whole-body roll rotation
A Palla1, M Tatalias, D Straumann
1Neurology Department, Zurich University Hospital, Zurich, Switzerland. antpalla@access.unizh.ch

Abstract:
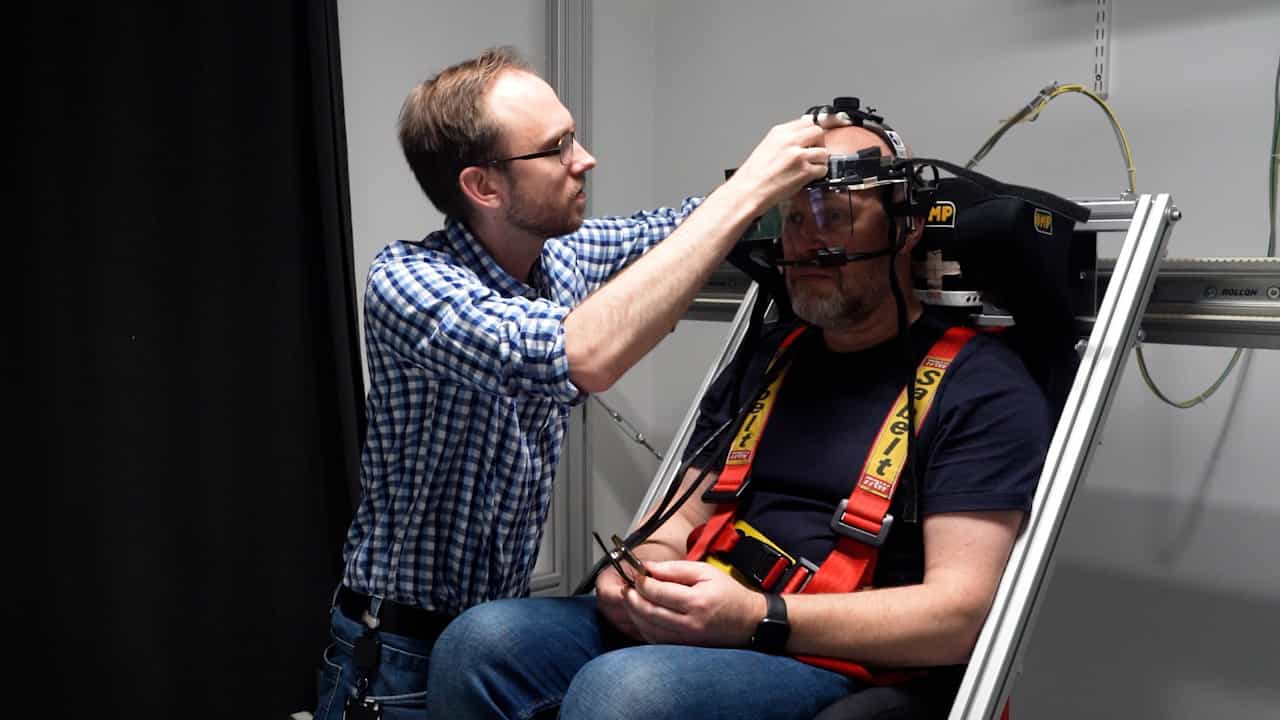
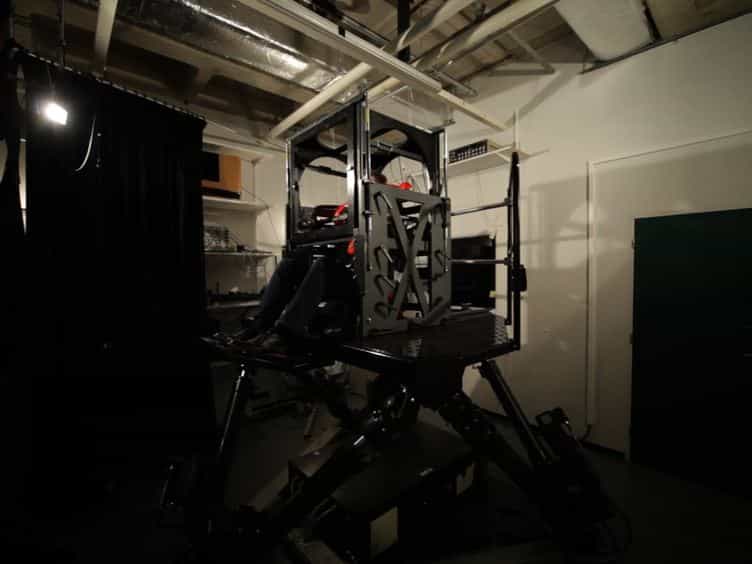
Healthy human subjects, when roll tilted in darkness, make systematic errors in estimating subjective visual vertical (SVV). Typically, roll tilt underestimation occurs at angles beyond 60 degrees (A-effect). At smaller tilt angles, overestimation may occur (E-effect). At approximately 135 degrees whole-body roll tilt, Kaptein and Van Gisbergen (2004, 2005) found an abrupt A/E transition, the exact location of which depended on the preceding rotation direction indicating hysteresis. Since this was observed using relatively fast roll velocity, it remains unclear whether the described hysteresis is dynamic or static. To clarify this uncertainty, we continuously rotated nine healthy subjects about the earth-horizontal naso-occipital axis, while they performed SVV adjustments every 2 s. Starting from the upright position, three full quasi-static constant velocity rotations (2 degrees/s) were completed in both directions (CW: clockwise; CCW: counterclockwise). SVV deviation from earth-verticality was plotted as a function of whole-body roll position. A bimodal Gaussian distribution function was fitted to SVV differences between CW and CCW rotations. A-effects (peaks at 88 degrees and 257 degrees chair position) at identical whole-body positions were larger after rotations from upside-down than after rotations from upright (average peak difference: 26 degrees). These results demonstrate static hysteresis for SVV estimation.
More Related Videos
Related Concept Videos
 01:15
Equilibrium and Balance
 01:26
Rotational Motion about a Fixed Axis
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:29
The Vestibular System
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...