Role of fluctuations in the response of coupled bistable units to weak time-periodic driving forces
Related Experiment Video
Updated: Jun 29, 2026
Assembly and Characterization of an External Driver for the Generation of Sub-Kilohertz Oscillatory Flow in Microchannels
Published on: January 28, 2022
Manuel Morillo1, José Gómez Ordóñez, José M Casado
1Area de Física TeóricaFacultad de Física, Universidad de Sevilla, Apartado de Correos 1065, Sevilla 41080, Spain.

Abstract:
We analyze the stochastic response of a finite set of globally coupled noisy bistable units driven by rather weak time-periodic forces. We focus on the stochastic resonance and phase frequency synchronization of the collective variable, defined as the arithmetic mean of the variable characterizing each element of the array. For single-unit systems, stochastic resonance can be understood with the powerful tools of linear response theory. Proper noise-induced phase frequency synchronization for a single-unit system in this linear response regime does not exist. For coupled arrays, our numerical simulations indicate an enhancement of the stochastic resonance effects leading to gains larger than unity as well as genuine phase frequency synchronization. The nonmonotonicity of the response with the strength of the coupling strength is investigated. Comparison with simplifying schemes proposed in the literature to describe the random response of the collective variable is carried out.
More Related Videos
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
 07:28
A Method for Evaluating Timeliness and Accuracy of Volitional Motor Responses to Vibrotactile Stimuli
Published on: August 2, 2016
Related Concept Videos
 01:06
Forced Oscillations
 01:18
Second Order systems II
If ζ...
 01:24
Transient and Steady-state Response
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state response.
 01:07
Damped Oscillations
Although friction and other non-conservative...
 01:21
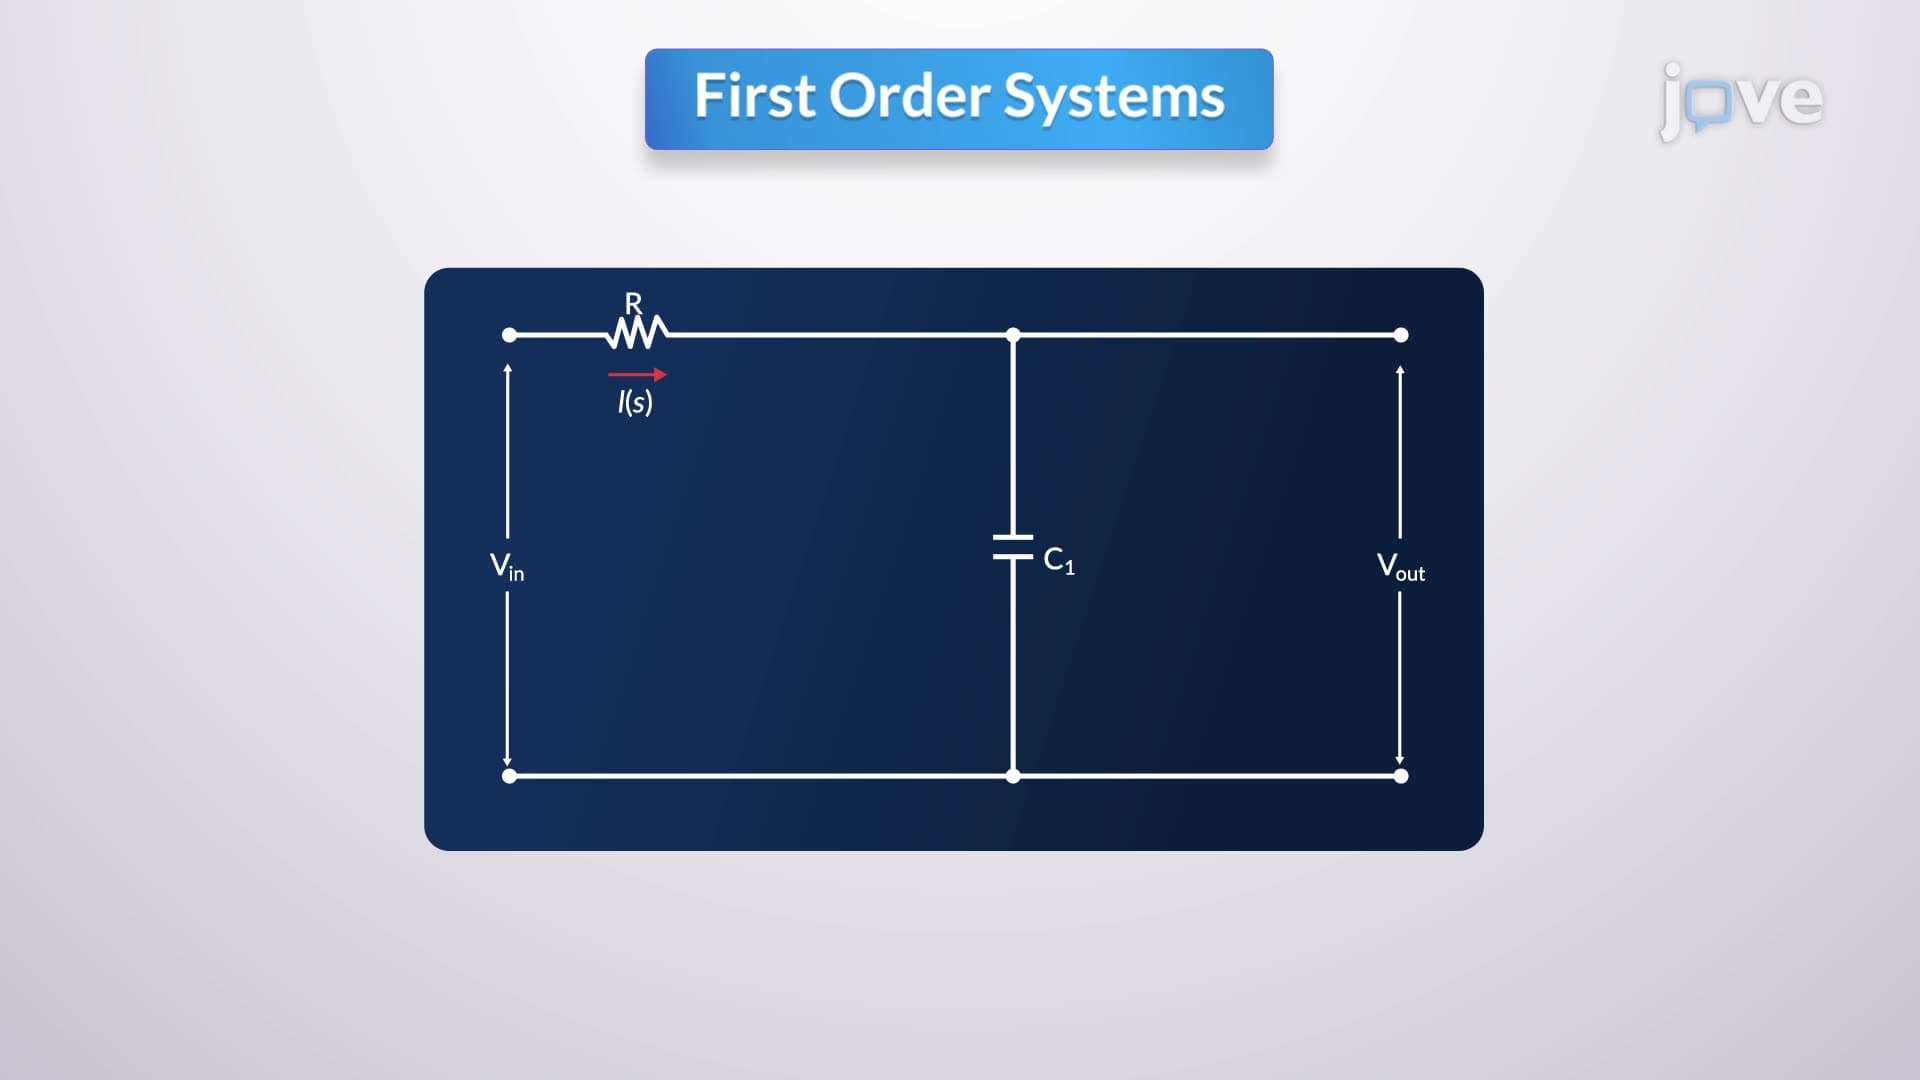
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:11
Types of Responses of Series RLC Circuits