Interactive navigation of heterogeneous agents using adaptive roadmaps
Related Experiment Video
Updated: Jun 28, 2026
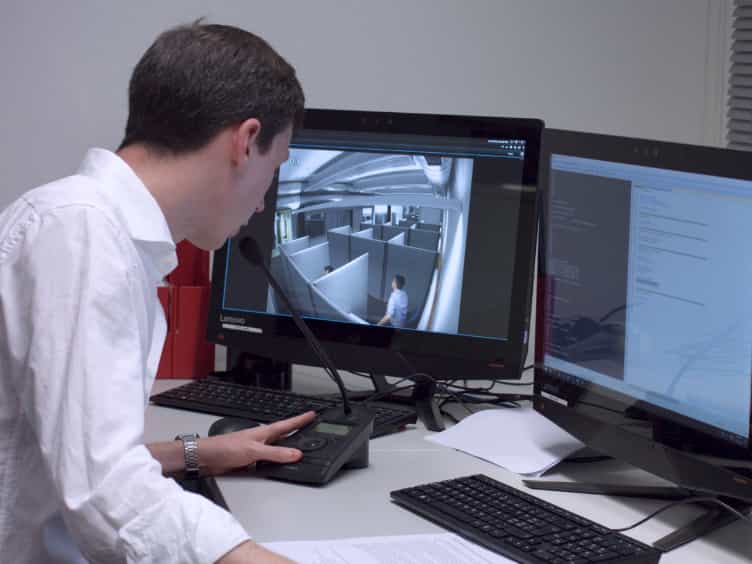
A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
Russell Gayle1, Avneesh Sud, Erik Andersen
1Department of Computer Science, University of North Carolina, Chapel Hill, NC 27599-3175, USA. rgayle@cs.unc.edu

Abstract:
We present a novel algorithm for collision-free navigation of a large number of independent agents in complex and dynamic environments. We introduce adaptive roadmaps to perform global path planning for each agent simultaneously. Our algorithm takes into account dynamic obstacles and interagents interaction forces to continuously update the roadmap based on a physically-based dynamics simulator. In order to efficiently update the links, we perform adaptive particle-based sampling along the links. We also introduce the notion of 'link bands' to resolve collisions among multiple agents. In practice, our algorithm can perform real-time navigation of hundreds and thousands of human agents in indoor and outdoor scenes.

Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:18
Hierarchy of Motor Control
 01:18
Fluid Movement Between Compartments
 01:21
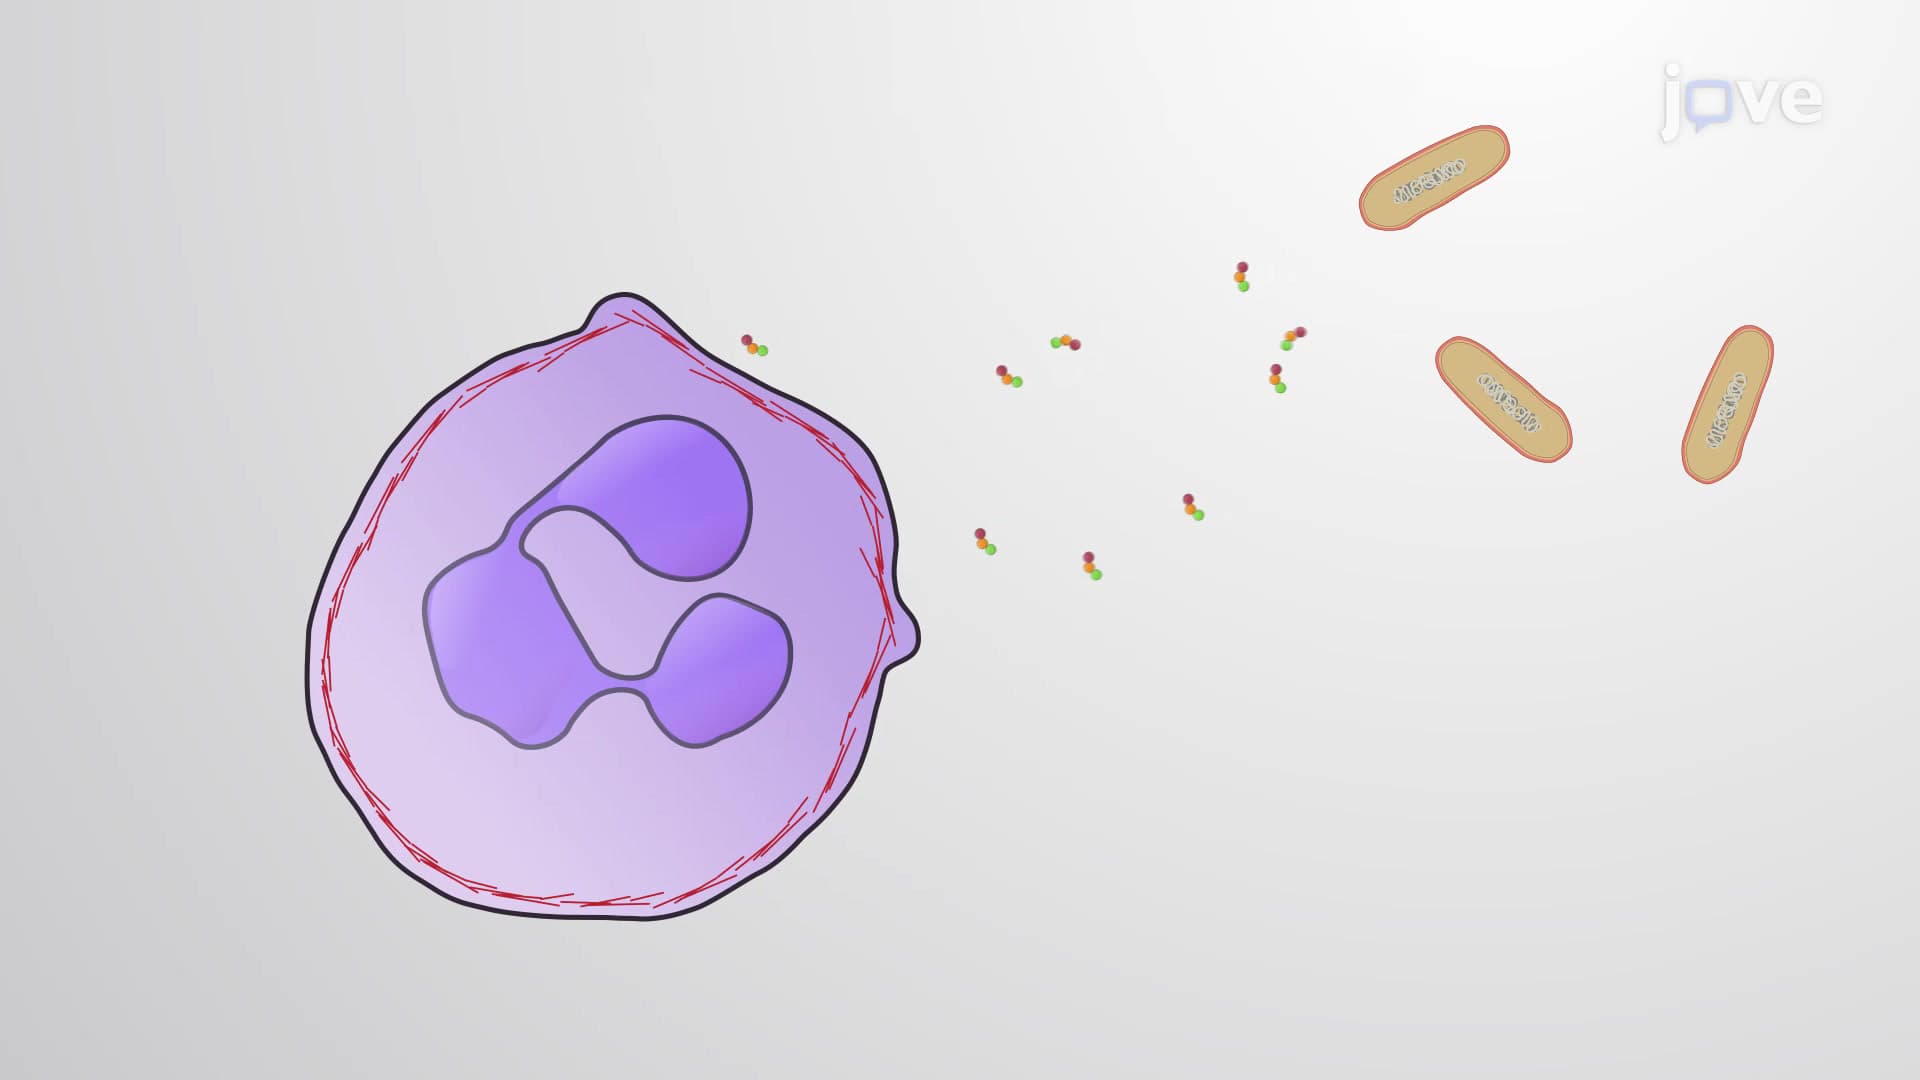
Chemotaxis and Direction of Cell Migration
 01:11
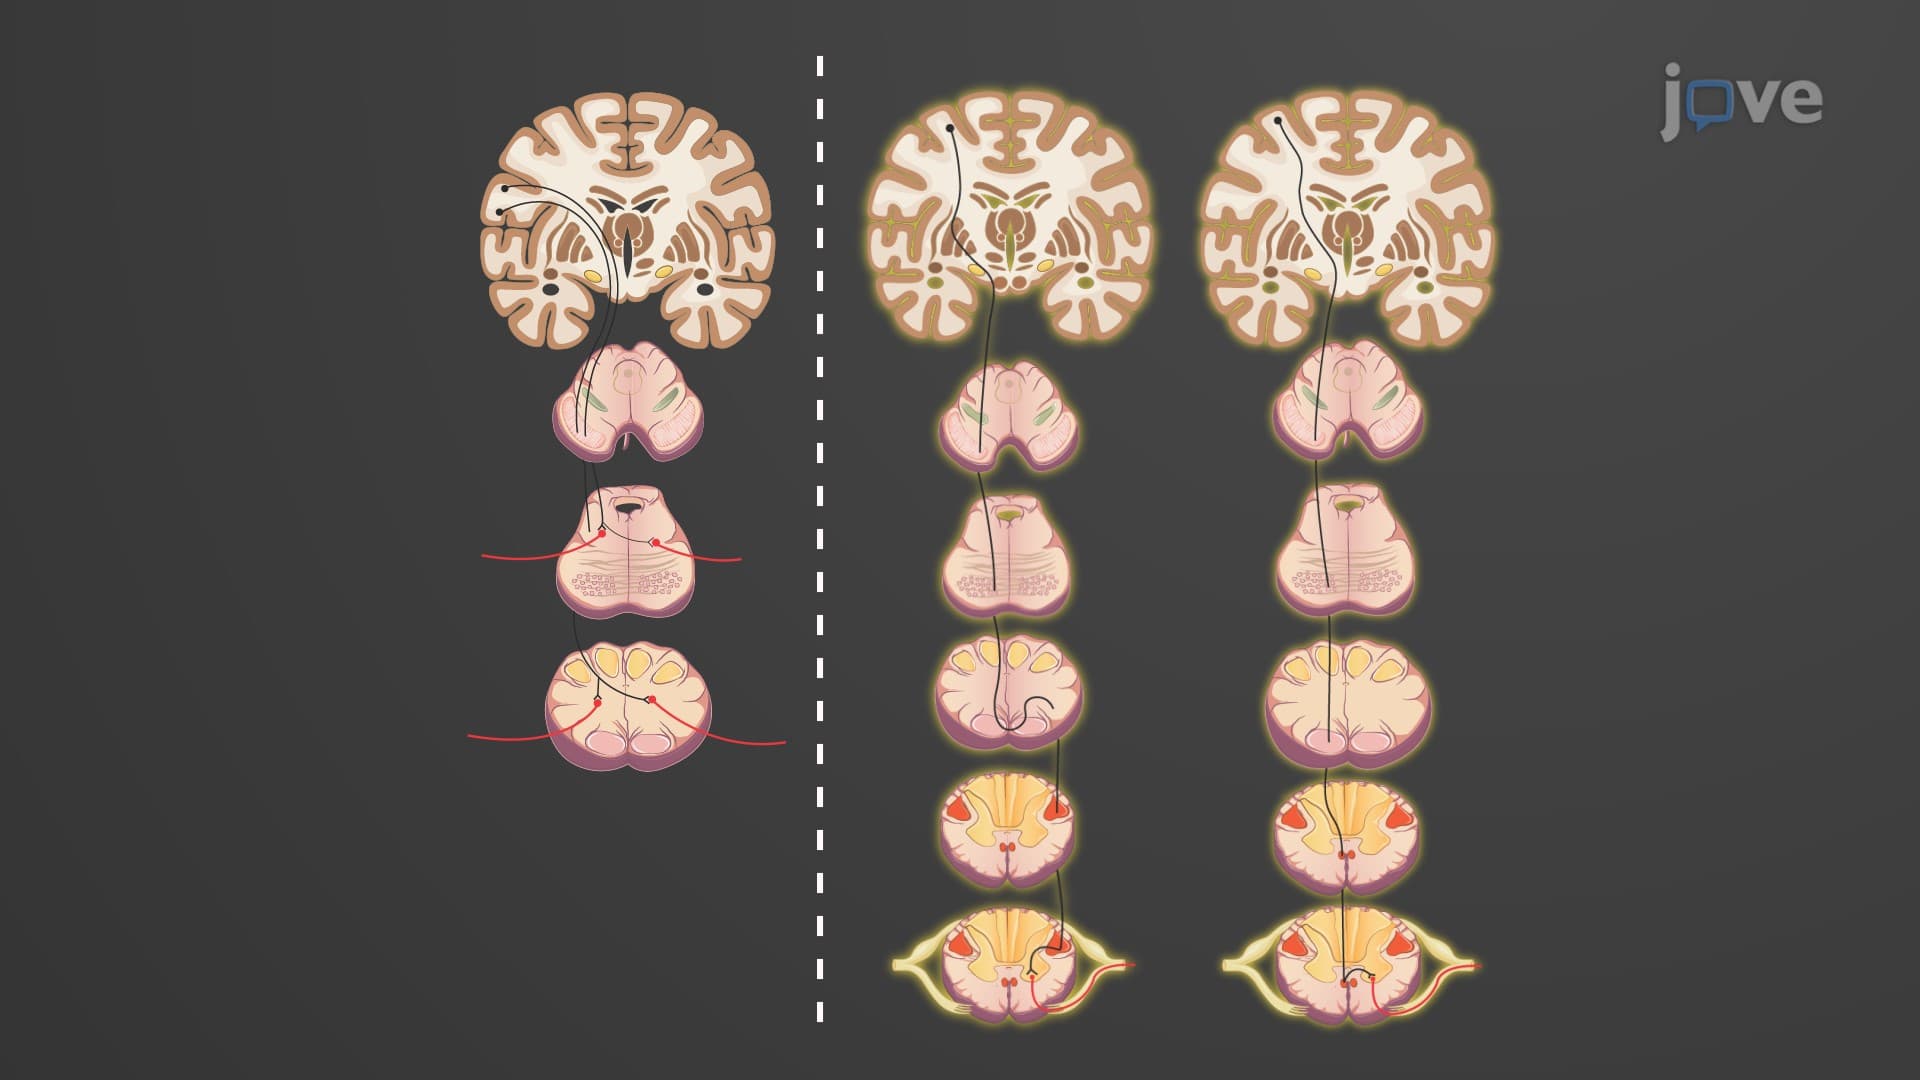
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...