Related Experiment Video

Updated: Jun 27, 2026
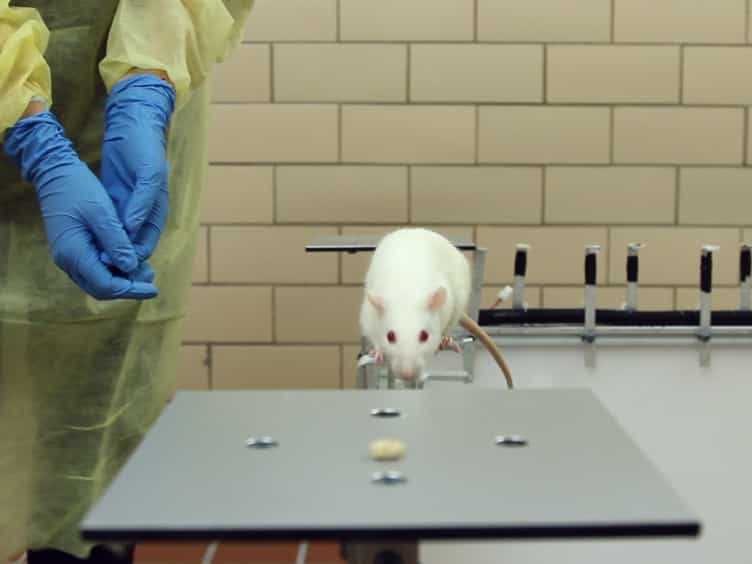
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
08:19

Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion

Published on: January 15, 2016

Foot and body control of biped robots to walk on irregularly protruded uneven surfaces

Jong Hyeon Park, Eung Seo Kim

    IEEE Transactions on Systems, Man, and Cybernetics. Part B, Cybernetics : a Publication of the IEEE Systems, Man, and Cybernetics Society
    |December 11, 2008
    PubMed

    Abstract:

    This correspondence proposes a control method for biped robots walking on a geometrically uneven surface with irregular protrusions. The focus is to maintain robot stability in leg and foot motions in order to adapt the foot to uneven terrains. Under the assumption that contact sensors are evenly installed at the foot soles, the geometric information under the landing foot is represented by a terrain matrix, whose elements represent the height of protruded cones. The control strategy of a landing phase (LP) is to form a large polygon with the contact points between the foot and the ground, based on the current zero-moment point (ZMP) and the locations of contact points during the transition from the LP to the stable double-support phase. The center of the polygon formed by the contact points at the end of the LP is to be used as the ZMP when the trajectory for the next step is generated. The gravity-compensated inverted-pendulum-mode-based trajectory is modified based on the newly located ZMP position and is interpolated to remove any trajectory discontinuity and to ensure a smooth transition. A series of computer simulations of a 28-degree-of-freedom (DOF) biped robot with a six-DOF environment model using SimMechanics shows that a stable compliant locomotion on uneven surfaces is successfully achieved with the proposed method.

    More Related Videos

    Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
    07:40

    Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot

    Published on: June 10, 2020

    Related Experiment Videos

    Last Updated: Jun 27, 2026

    Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
    08:19

    Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion

    Published on: January 15, 2016

    Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
    07:40

    Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot

    Published on: June 10, 2020

    Related Concept Videos

    Rolling Resistance: Problem Solving01:17

    Rolling Resistance: Problem Solving
    Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
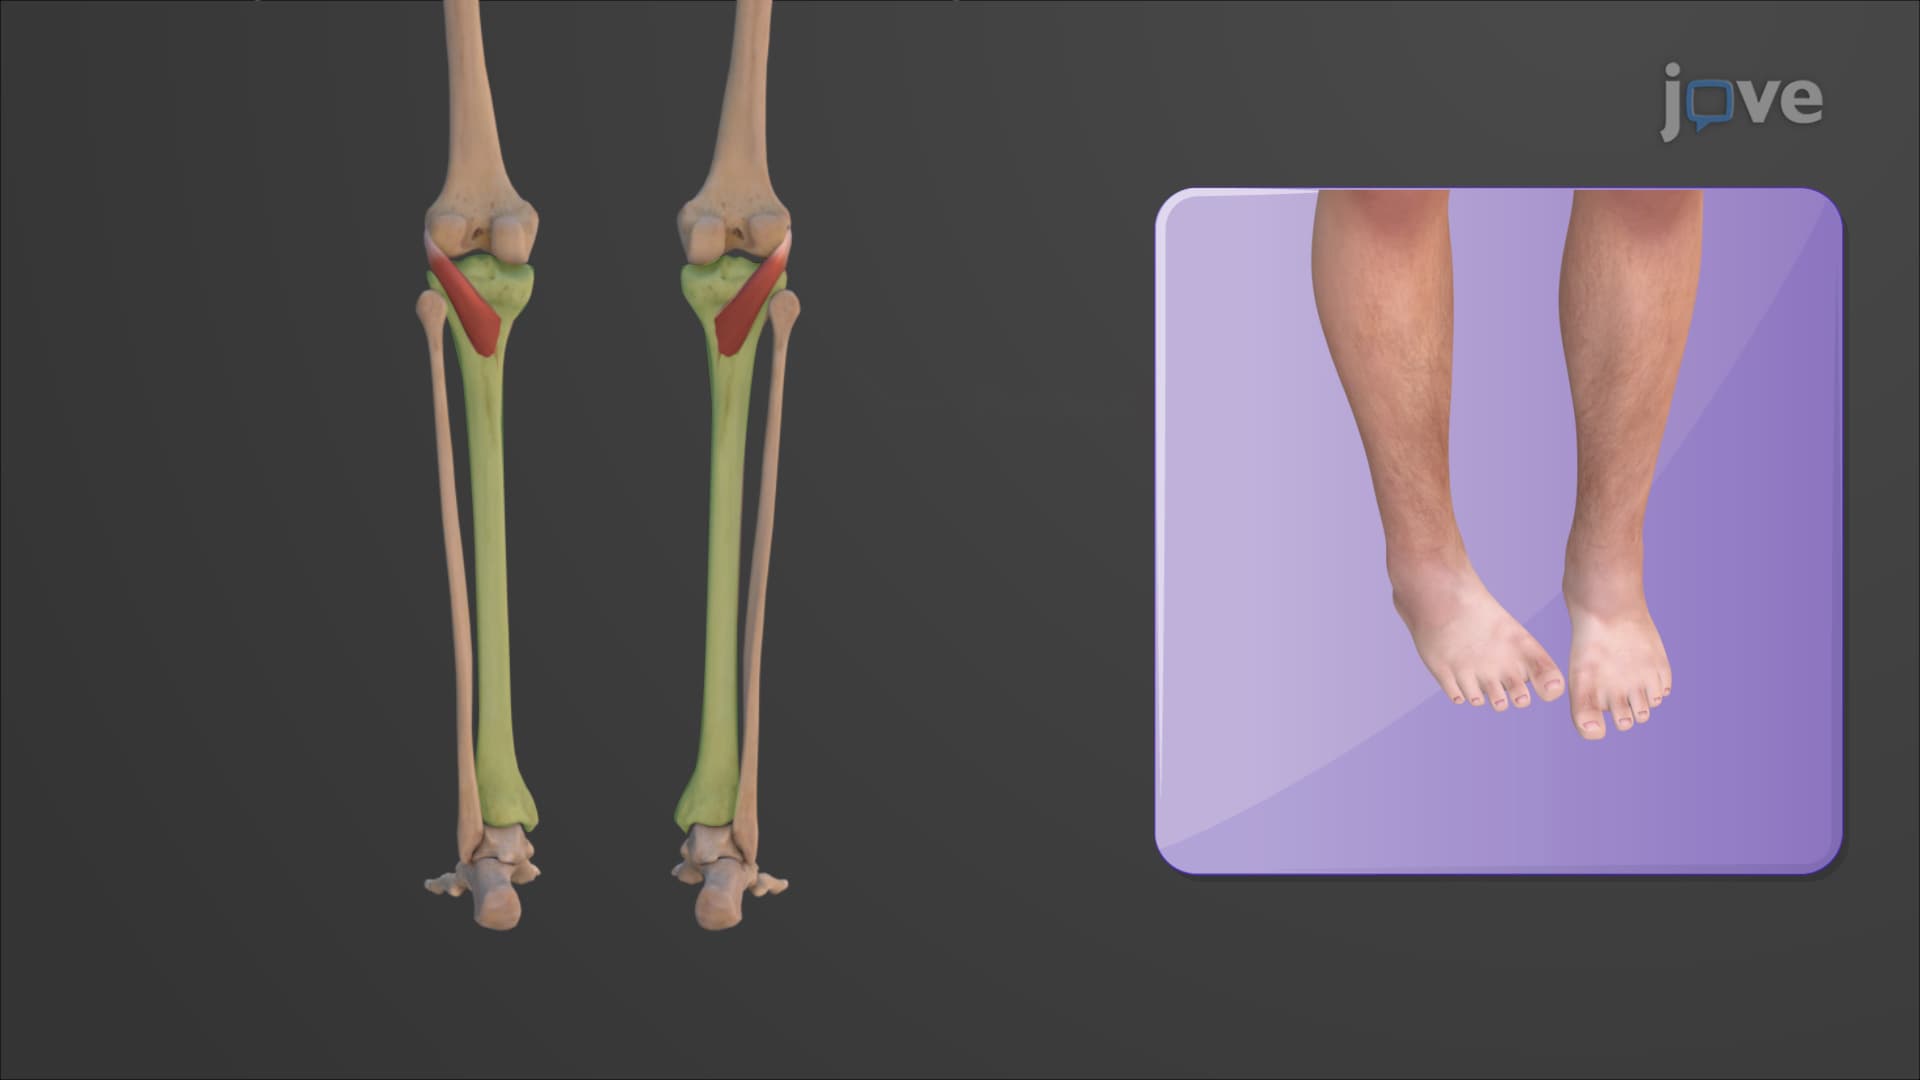
    Muscles of the Leg that Move the Foot and Toes01:28

    Muscles of the Leg that Move the Foot and Toes

    The human leg comprises an intricate system of muscles that facilitate the movement of feet and toes. Within this system, the muscles are categorized into the anterior, lateral, and posterior compartments, each with a unique set of muscles carrying out specific functions.
    Anterior Compartment
    The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles.

    Articles linked to this work by shared authors, journal, and citation graph.

    Improved immune responses and safety of foot-and-mouth disease vaccine containing immunostimulating components in pigs.

    Journal of veterinary science·2020

    New foot-and-mouth disease vaccine, O JC-R, induce complete protection to pigs against SEA topotype viruses occurred in South Korea, 2014-2015.

    Journal of veterinary science·2019

    Needleless intradermal vaccination for foot-and-mouth disease induced granuloma-free effective protection in pigs.

    Journal of veterinary science·2019

    Development of an epitope-blocking-enzyme-linked immunosorbent assay to differentiate between animals infected with and vaccinated against foot-and-mouth disease virus.

    Journal of virological methods·2007

    Enhanced immune response with foot and mouth disease virus VP1 and interleukin-1 fusion genes.

    Journal of veterinary science·2006

    Development of synthetic peptide ELISA based on nonstructural protein 2C of foot and mouth disease virus.

    Journal of veterinary science·2005

    Strategic Ability Updating in Concurrent Games by Coalitional Commitment.

    IEEE transactions on systems, man, and cybernetics. Part B, Cybernetics : a publication of the IEEE Systems, Man, and Cybernetics Society·2015

    Meta-Analysis of the First Facial Expression Recognition Challenge.

    IEEE transactions on systems, man, and cybernetics. Part B, Cybernetics : a publication of the IEEE Systems, Man, and Cybernetics Society·2012

    Adjustable model-based fusion method for multispectral and panchromatic images.

    IEEE transactions on systems, man, and cybernetics. Part B, Cybernetics : a publication of the IEEE Systems, Man, and Cybernetics Society·2012

    Face Feature Weighted Fusion Based on Fuzzy Membership Degree for Video Face Recognition.

    IEEE transactions on systems, man, and cybernetics. Part B, Cybernetics : a publication of the IEEE Systems, Man, and Cybernetics Society·2012

    A New Adaptive Fast Cellular Automaton Neighborhood Detection and Rule Identification Algorithm.

    IEEE transactions on systems, man, and cybernetics. Part B, Cybernetics : a publication of the IEEE Systems, Man, and Cybernetics Society·2012

    Human-arm-and-hand-dynamic model with variability analyses for a stylus-based haptic interface.

    IEEE transactions on systems, man, and cybernetics. Part B, Cybernetics : a publication of the IEEE Systems, Man, and Cybernetics Society·2012

    Validation of the Accuracy of Robotic Arm-Assisted Total Hip Arthroplasty After Rotational Acetabular Osteotomy: A Propensity-Matched Controlled Study.

    Arthroplasty today·2026

    A multifactorial assessment based on muscle synergies to evaluate the effects of hip exoskeleton assistance in functional tasks.

    Human movement science·2026

    Sensorless Contact Force Estimation and Adaptive Variable-Damping Compliant Control for Biomimetic Robotic Arm.

    Biomimetics (Basel, Switzerland)·2026

    On-Limb Orbiting Robot: Proprioceptive Diameter Estimation and Orthogonal Grip-Orbit Control.

    Biomimetics (Basel, Switzerland)·2026

    TSIE: Robust Blind Locomotion Learning for Bipedal Robots via Terrain and State Implicit-Explicit Estimation.

    Biomimetics (Basel, Switzerland)·2026

    A new integrated hybrid technique for risk assessment in human-robot collaboration.

    Frontiers in robotics and AI·2026
    See all related articles
    JoVE
    x logofacebook logolinkedin logoyoutube logo
    ABOUT JoVE
    OverviewLeadershipBlogJoVE Help Center
    AUTHORS
    Publishing ProcessEditorial BoardScope & PoliciesPeer ReviewFAQSubmit
    LIBRARIANS
    TestimonialsSubscriptionsAccessResourcesLibrary Advisory BoardFAQ
    RESEARCH
    JoVE JournalMethods CollectionsJoVE Encyclopedia of ExperimentsArchive
    EDUCATION
    JoVE CoreJoVE BusinessJoVE Science EducationJoVE Lab ManualFaculty Resource CenterFaculty Site
    Terms & Conditions of Use
    Privacy Policy
    Policies
    Jove
    Visualize
    Contact Us