Camera displacement via constrained minimization of the algebraic error
Related Experiment Video
Updated: Jun 26, 2026
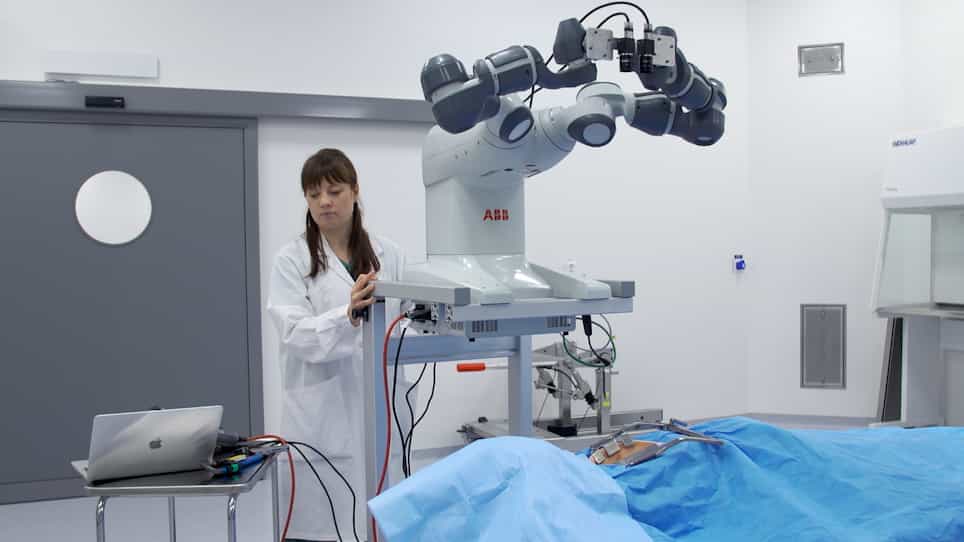
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
1Department of Electrical and Electronic Engineering, University of Hong Kong, Hong Kong. chesi@eee.hku.hk

Abstract:
This paper proposes a new approach to estimate the camera displacement of stereo vision systems via minimization of the algebraic error over the essential matrices manifold. The proposed approach is based on the use of homogeneous forms and linear matrix inequality (LMI) optimizations, and has the advantages of not presenting local minima and not introducing approximations of nonlinear terms. Numerical investigations carried out with both synthetic and real data show that the proposed approach provides significantly better results than SVD methods as well as minimizations of the algebraic error over the essential matrices manifold via both gradient descent and simplex search algorithms.
Related Concept Videos
 01:28
Lagrange Multipliers: Two Constraints
 01:30
Vector Functions and Motion: Problem Solving
 01:29
Lagrange Multipliers: One Constraint
 01:15
Distance Corrections
 01:23
Linear Approximations
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...