Related Experiment Video
Updated: Jun 26, 2026
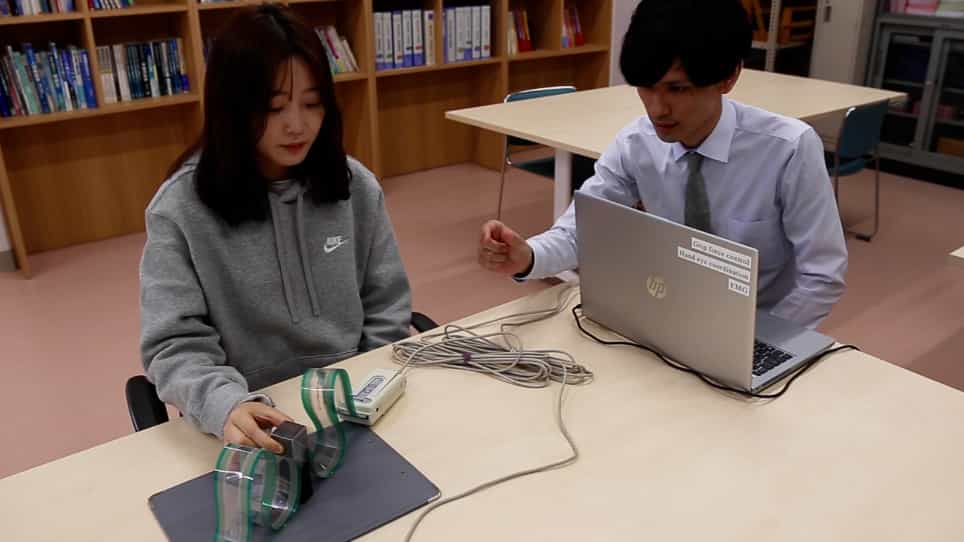

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Effects of grasping force magnitude on the coordination of digit forces in multi-finger prehension
Xun Niu1, Mark L Latash, Vladimir M Zatsiorsky
1Biomechanics Lab, Department of Kinesiology, 39 Rec. Bldg, The Pennsylvania State University, University Park, PA, 16802, USA. xun100@psu.edu

Abstract:
The study addresses three main questions: (1) Does the magnitude of the grasping force affect the prehension synergies, i.e., conjoint changes of finger forces and moments? (2) Do individual finger forces scale with the total grasping forces ('scale-invariance hypothesis')? (3) How specification of the grasping force magnitude affects the inverse optimization of digit forces. Subjects (n = 7) grasped with minimal force an instrumented handle and maintained it at rest in the air. Then, the subjects doubled the initial grasping force. The forces and moments exerted by individual digits were recorded with six-component sensors. External torques that the subjects should resist (9 in total) varied among the trials from 0 to 0.46 Nm both in clockwise and counterclockwise directions. After the force doubling, the moments of the normal forces (M (n)) increased in the pronation effort tasks (PR-tasks) and decreased in the supination effort tasks (SU-tasks). The changes in the moments of the tangential forces (M (t)) were opposite to the M (n) changes; the moments increased in the SU-tasks and decreased in the PR-tasks. The opposite effects of force doubling on the M (t)s in the SU-tasks and PR-tasks were a consequence of the unidirectional changes of the thumb tangential forces: in all the tasks the contribution of the thumb tangential force to the total tangential force increased after the grasping force doubling (and the total contribution of the four fingers decreased). The decrease of the virtual finger (VF) tangential force was mainly due to the decrease of the index finger force (VF is an imagined finger that exerts the same force and moment as all the fingers together). In the non-zero torque tasks the individual finger forces did not scale proportionally with the grasping force, the sharing percentage of the individual finger forces in the VF normal force changed with the grasping force increase. The root mean square differences between the actual finger sharing percentages in the VF force and the sharing percentages predicted from optimization procedures in which different cost functions were used were in all cases smaller after the doubling than before the doubling. Hence the answers to the three questions formulated above are: (1) the alteration of the grasping force magnitude induces complex coordinated changes of all digit forces and moments; (2) the scale invariance hypothesis is confirmed only for the zero-torque tasks and rejected for the non-zero tasks, and (3) the specification of the grasping force magnitude at the level of twice the initial grasping force-which essentially restricts the control task to the object tilt prevention-improves the accuracy of the employed optimization procedures.

Related Concept Videos
 01:29
Moment of a Force: Problem Solving
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi radialis,...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:07
Frictional Force