Related Experiment Video
Updated: Jun 25, 2026

Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Local predictability and nonhyperbolicity through finite Lyapunov exponent distributions in two-degrees-of-freedom
Juan C Vallejo1, Ricardo L Viana, Miguel A F Sanjuán
1Nonlinear Dynamics, Chaos and Complex Systems Group, Departamento de Física, Universidad Rey Juan Carlos, Tulipán s/n, 28933 Móstoles, Madrid, Spain.

Abstract:
By using finite Lyapunov exponent distributions, we get insight into both the local and global properties of a dynamical flow, including its nonhyperbolic behavior. Several distributions of finite Lyapunov exponents have been computed in two prototypical four-dimensional phase-space Hamiltonian systems. They have been computed calculating the growth rates of a set of orthogonal axes arbitrarily pointed at given intervals. We analyze how such distributions serve or not for tracing the orbit nature and local flow properties such as the unstable dimension variability, as the axes are allowed or not to tend to the largest stretching direction. The relationship between the largest and closest to zero exponent distribution is analyzed. It shows a linear dependency at short intervals, related to the number of degrees of freedom of the system. Finally, the hyperbolicity indexes, associated to the shadowing times, are calculated. They provide interesting information at very local scales, even when there are no Gaussian distributions and the values cannot be regarded as random variables.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:28
Stability
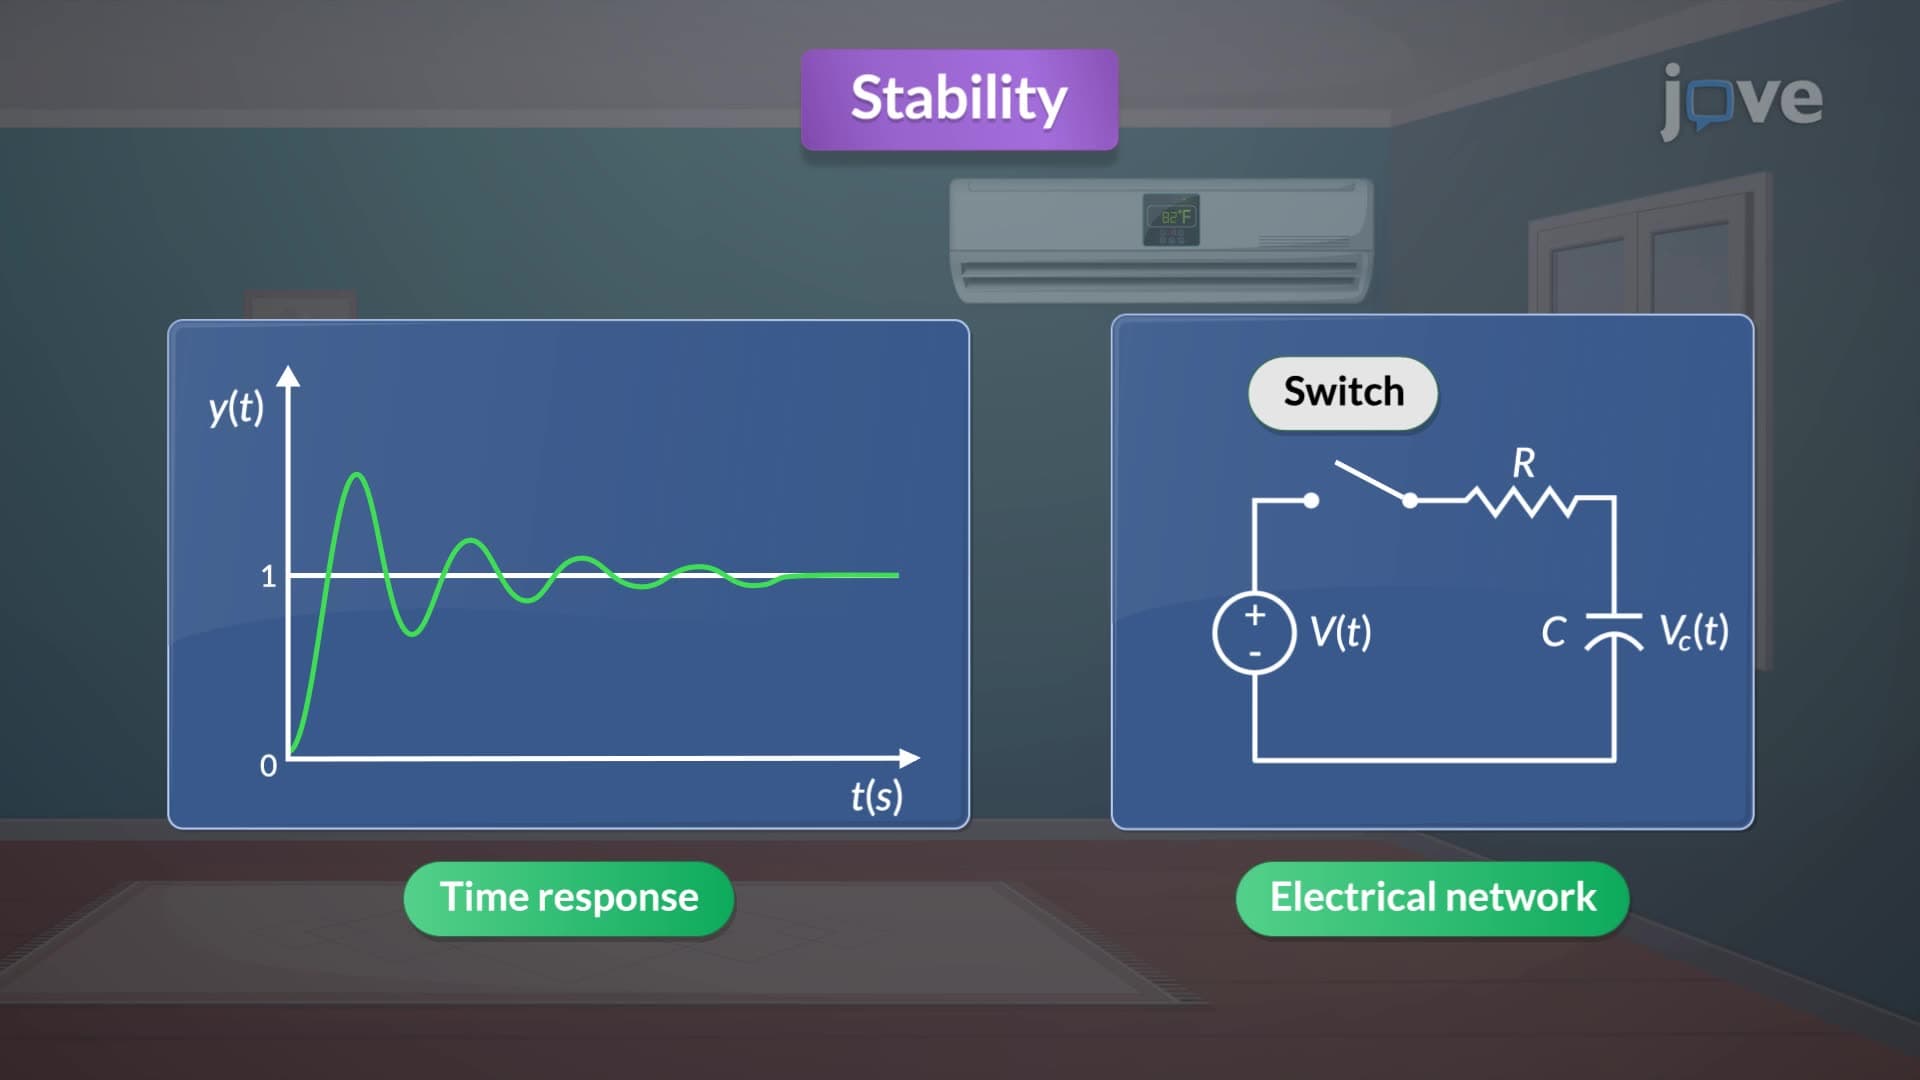
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as: