Haptic alignment of the hands in three dimensions
Related Experiment Video
Updated: Jun 25, 2026
Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
1Center for the Ecological Study of Perception and Action, Department of Psychology, U-20, University of Connecticut, 406 Babbidge Road, Storrs, CT 06269-1020, USA. matthew.butwill@uconn.edu

Abstract:
The problem of constancy of perception over variations in sensory input applies as much to proprioception as it does to vision and audition. The authors conducted an experiment in which blindfolded participants (N = 6) attempted to produce a constant relation between the left and the right hands' attitudes (roll, pitch, and yaw) at different distances and directions relative to the body. The measure of perceptual constancy over the changing 3-dimensional configurations of the arms' 14 joint degrees of freedom was the hands' deviations from the required attitudes when participants perceived that they satisfied the required attitudes. Two slant spinors quantified the attitudes of the hands relative to the body or the laboratory reference frame. A vergence spinor quantified the attitude of the right hand relative to that of the left hand. The scalar components of the spinors were found to be idiosyncratic to, and reasonably constant for, individual participants, as were the bivector components (revealed through spherical graphical and statistical procedures). Achieving particular attitudinal relations to the body and between contralateral limb segments are individual-specific perception-action skills. They are constrained by haptic invariants approximated by the slant and vergence spinors.
More Related Videos
 08:27
Three-Dimensional Finger Motion Tracking during Needling: A Solution for the Kinematic Analysis of Acupuncture Manipulation
Published on: October 28, 2021
 13:44
Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011
Related Concept Videos
 01:33
Somatosensation
 01:30
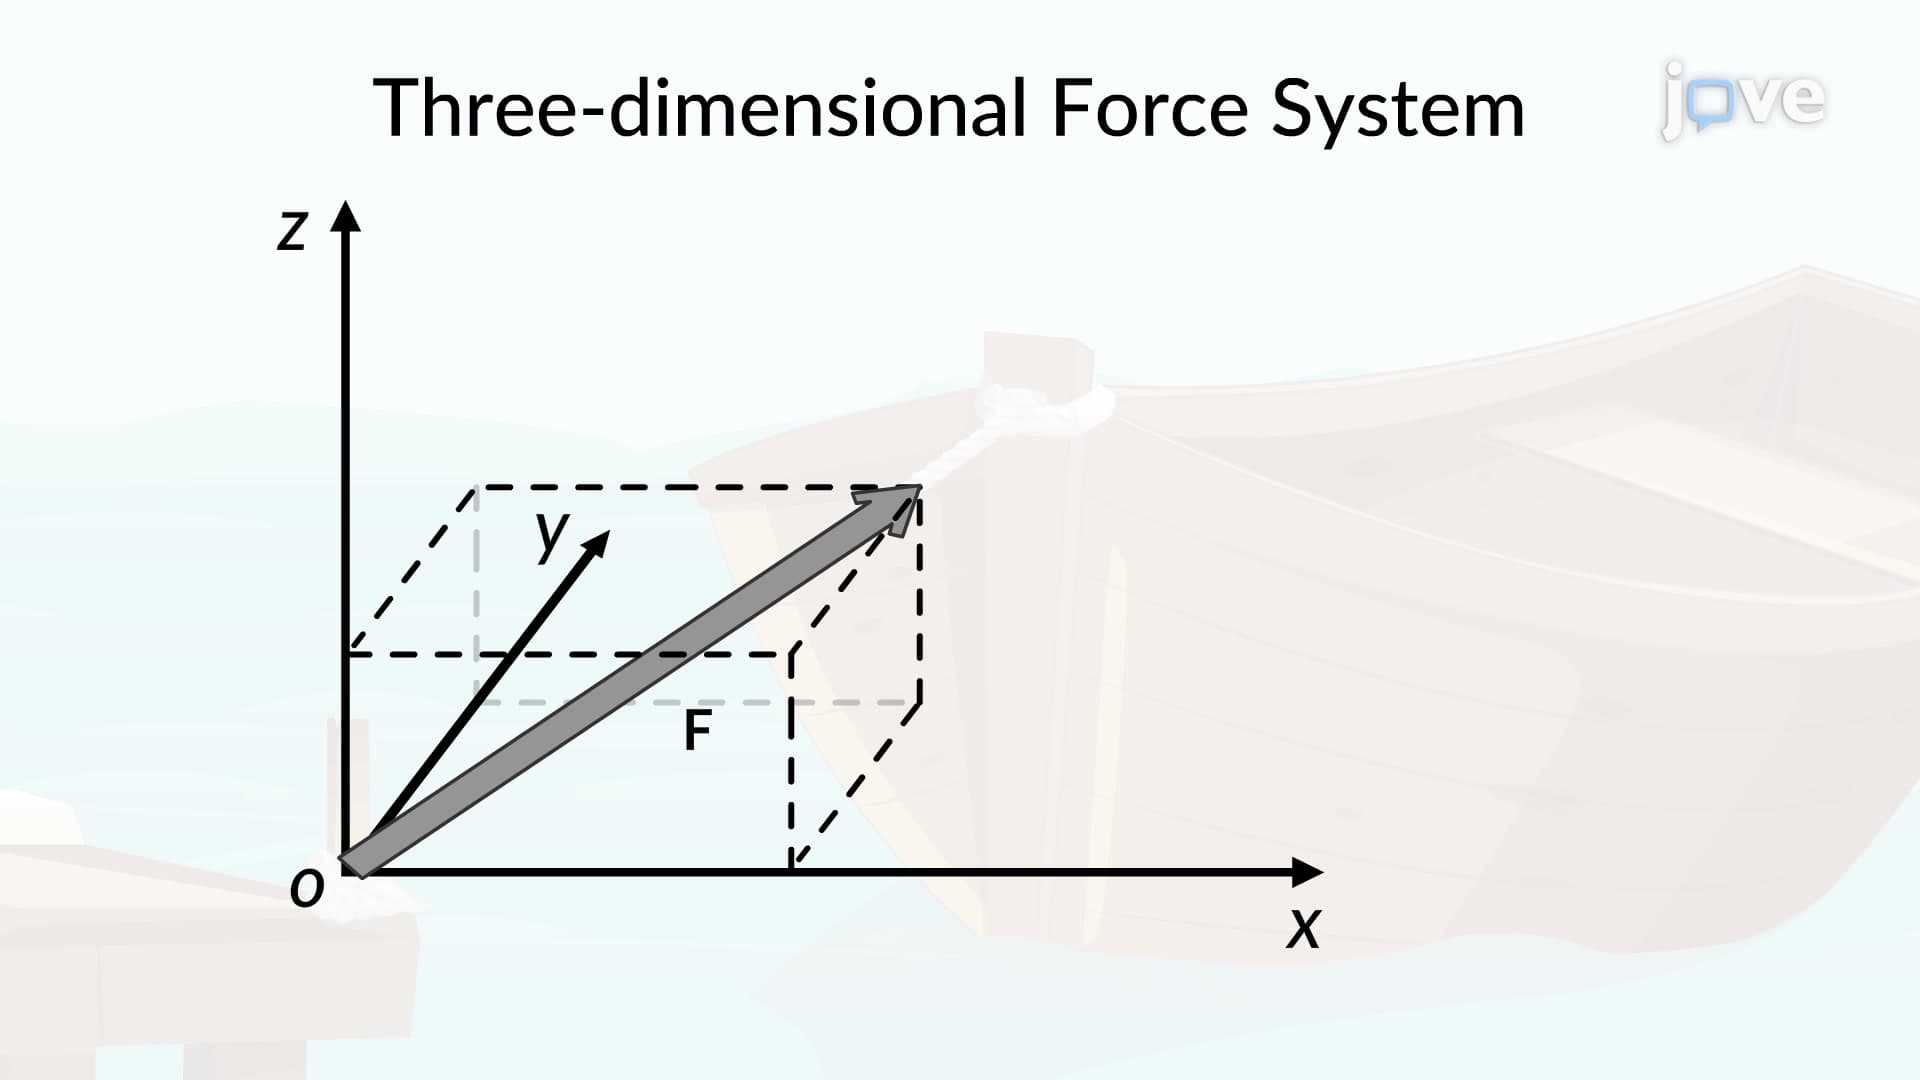
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...