Determination of rigid body registration marker error from edge error
Related Experiment Video
Updated: Jun 25, 2026
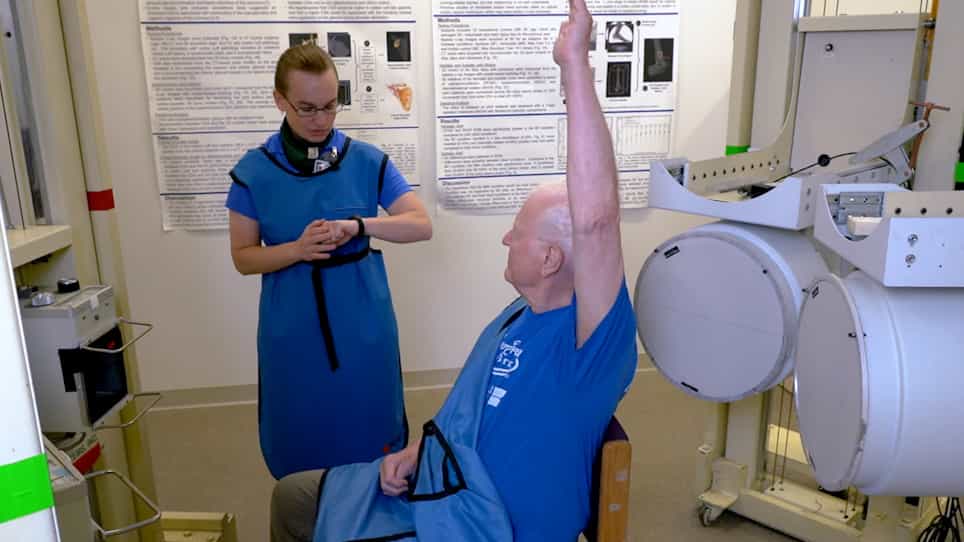
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
1Division of Research, Department of Orthopaedic Surgery and Rehabilitation, The University of Texas Medical Branch, 301 University Blvd., Galveston, TX 77555-0174, USA. clanders@utmb.edu

Abstract:
Registration markers affixed to rigid bodies (fixed to bone as opposed to skin) are commonly used when tracking 3D rigid body motion. The measured positions of registration markers are subject to unavoidable errors, both systematic and non-systematic. Prior studies have investigated the error propagated to such derived properties as rigid body positions and helical axes, while others have focused on the error associated with a specific position tracking system under restricted conditions. Theoretical and simulation-based error propagation requires knowledge of the variation due to individual registration markers; however, the variation in registration marker position measurement has previously been either assumed or determined from static cases. The objective of this paper is the introduction of a method for determining individual marker variation irrespective of change in rigid body position or motion by utilizing the distances between the markers (edge lengths), which are invariant under rotation and translation. Simulations were used to validate and characterize the introduced technique, demonstrating that the predictions improve with greater edge length and additional markers, converge on reference values where the edge length is at least 4 times the magnitude of the maximum vertex variation, and that under ideal conditions the confidence interval about the predicted variation is within 7% of the maximum variation associated with that marker set. The introduced technique was tested on the results of a motion tracking experiment to demonstrate the wide disparity in vertex variation between static and non-static measurements of the same registration markers, where the non-static variation exceeded the static variation by an average factor of 12.7.
Related Concept Videos
 00:49
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:18
Errors in Taping
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
 01:16
Statically Indeterminate Problem Solving
 01:17
Common Leveling Mistakes and Errors