Related Experiment Video
Updated: Jun 25, 2026
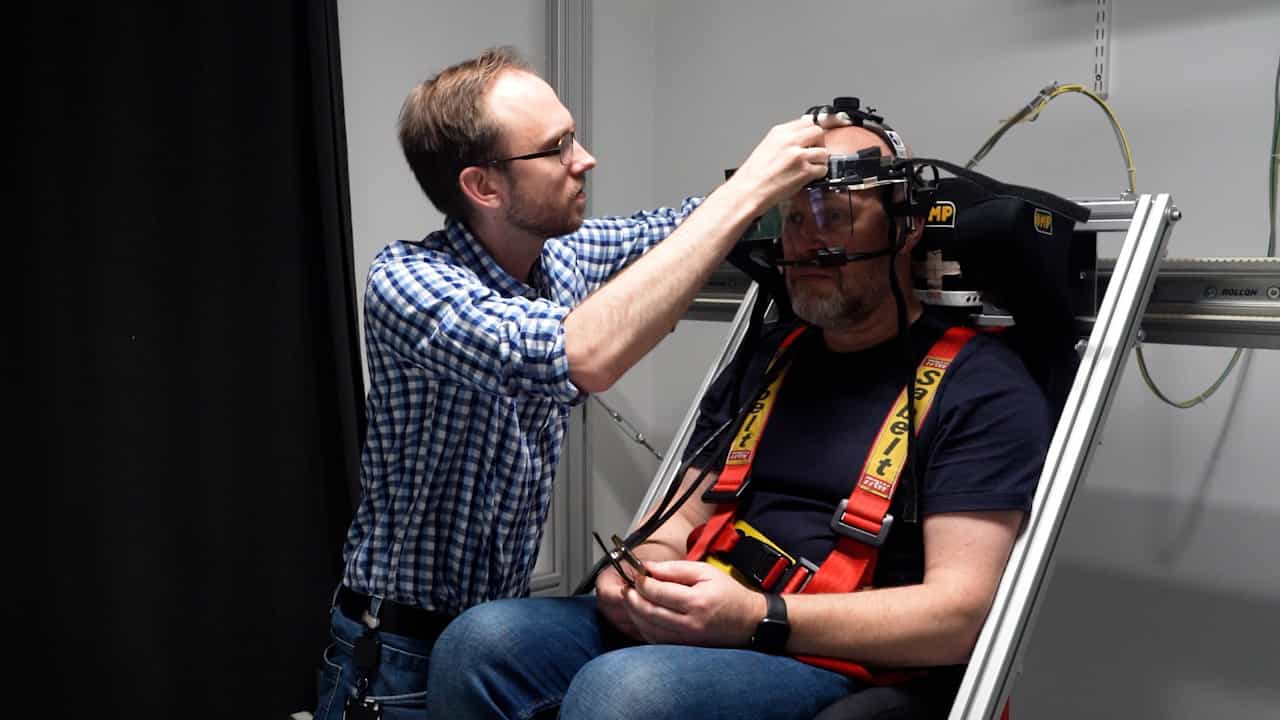

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Tilt aftereffects and tilt illusions induced by fast translational motion: evidence for motion streaks
1School of Psychology, University of Sydney, NSW, Australia. deboraha@psych.usyd.edu.au

Abstract:
Fast-moving visual features are thought to leave neural 'streaks' that can be detected by orientation-selective cells. Here, we tested whether 'motion streaks' can induce classic tilt aftereffects (TAEs) and tilt illusions (TIs). For TAEs, participants adapted to random arrays of small Gaussian blobs drifting at 9.5 deg/s. Following adaptation to directions of 15, 30, 45, 60, 75, and 90 degrees (clockwise from vertical) subjective vertical was measured for a briefly presented test grating. For TIs, the same motions were presented in an annular surround and subjective vertical was measured for a simultaneously presented central grating. All motions were 50% coherent, with half the blobs following random-walk paths and half following a fixed direction. Strong and weak streaks were compared by varying streak length (the number of fixed-walk frames), rather than by manipulating speed, so that speed and coherence were matched in all conditions. Strong motion streaks produced robust TAEs and TIs, similar in magnitude and orientation tuning to those induced by tilted lines. These effects were weak or absent in weak streak conditions, and when motion was too slow to form streaks. Together, these results indicate that motion streaks produced by temporal integration of fast translating features do effectively adapt orientation-selective cells and may therefore be exploited to improve perception of motion direction as described in the 'motion streaks' model.
Related Concept Videos
 00:56
Doppler Effect - I
 01:27
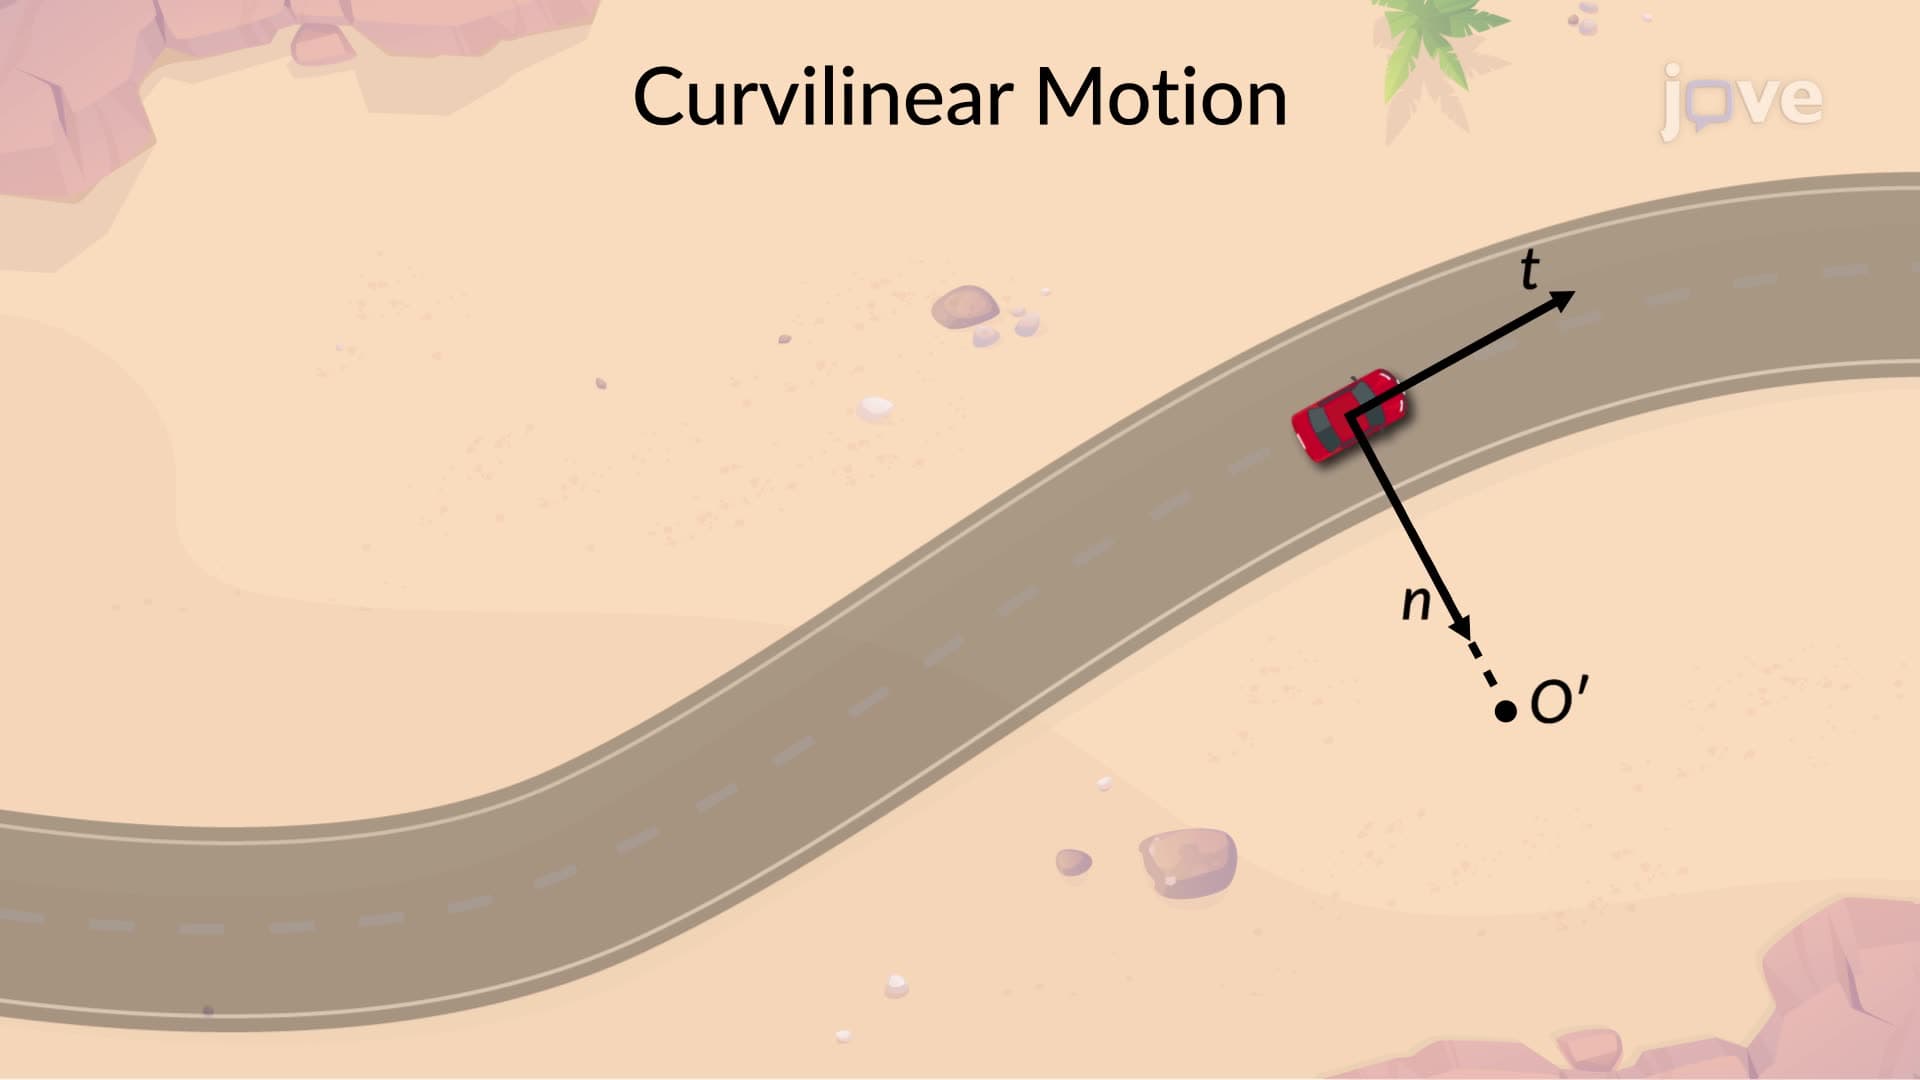
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Motion Analysis - Acceleration