A haptic unit designed for magnetic-resonance-guided biopsy
1Mechatronics in Medicine Laboratory, Department of Mechanical Engineering, Imperial College London, London, UK.

Abstract:
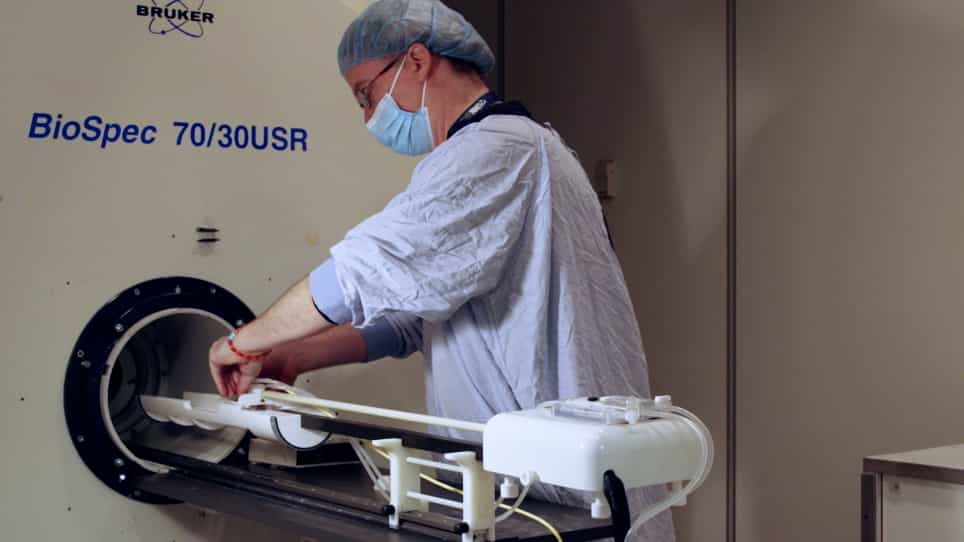
The magnetic fields present in the magnetic resonance (MR) environment impose severe constraints on any mechatronic device present in its midst, requiring alternative actuators, sensors, and materials to those conventionally used in traditional system engineering. In addition the spatial constraints of closed-bore scanners require a physical separation between the radiologist and the imaged region of the patient. This configuration produces a loss of the sense of touch from the target anatomy for the clinician, which often provides useful information. To recover the force feedback from the tissue, an MR-compatible haptic unit, designed to be integrated with a five-degrees-of-freedom mechatronic system for MR-guided prostate biopsy, has been developed which incorporates position control and force feedback to the operator. The haptic unit is designed to be located inside the scanner isocentre with the master console in the control room. MR compatibility of the device has been demonstrated, showing a negligible degradation of the signal-to-noise ratio and virtually no geometric distortion. By combining information from the position encoder and force sensor, tissue stiffness measurement along the needle trajectory is demonstrated in a lamb liver to aid diagnosis of suspected cancerous tissue.