Related Experiment Video
Updated: Jun 23, 2026

A Two-interval Forced-choice Task for Multisensory Comparisons
Published on: November 9, 2018
Denoising forced-choice detection data
1Departamento de Metodología, Facultad de Psicología, Universidad Complutense, Madrid, Spain. miguel@psi.ucm.es

Abstract:
Observers in a two-alternative forced-choice (2AFC) detection task face the need to produce a response at random (a guess) on trials in which neither presentation appeared to display a stimulus. Observers could alternatively be instructed to use a 'guess' key on those trials, a key that would produce a random guess and would also record the resultant correct or wrong response as emanating from a computer-generated guess. A simulation study shows that 'denoising' 2AFC data with information regarding which responses are a result of guesses yields estimates of detection threshold and spread of the psychometric function that are far more precise than those obtained in the absence of this information, and parallel the precision of estimates obtained with yes-no tasks running for the same number of trials. Simulations also show that partial compliance with the instructions to use the 'guess' key reduces the quality of the estimates, which nevertheless continue to be more precise than those obtained from conventional 2AFC data if the observers are still moderately compliant. An empirical study testing the validity of simulation results showed that denoised 2AFC estimates of spread were clearly superior to conventional 2AFC estimates and similar to yes-no estimates, but variations in threshold across observers and across sessions hid the benefits of denoising for threshold estimation. The empirical study also proved the feasibility of using a 'guess' key in addition to the conventional response keys defined in 2AFC tasks.
Related Concept Videos
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:20
Deconvolution
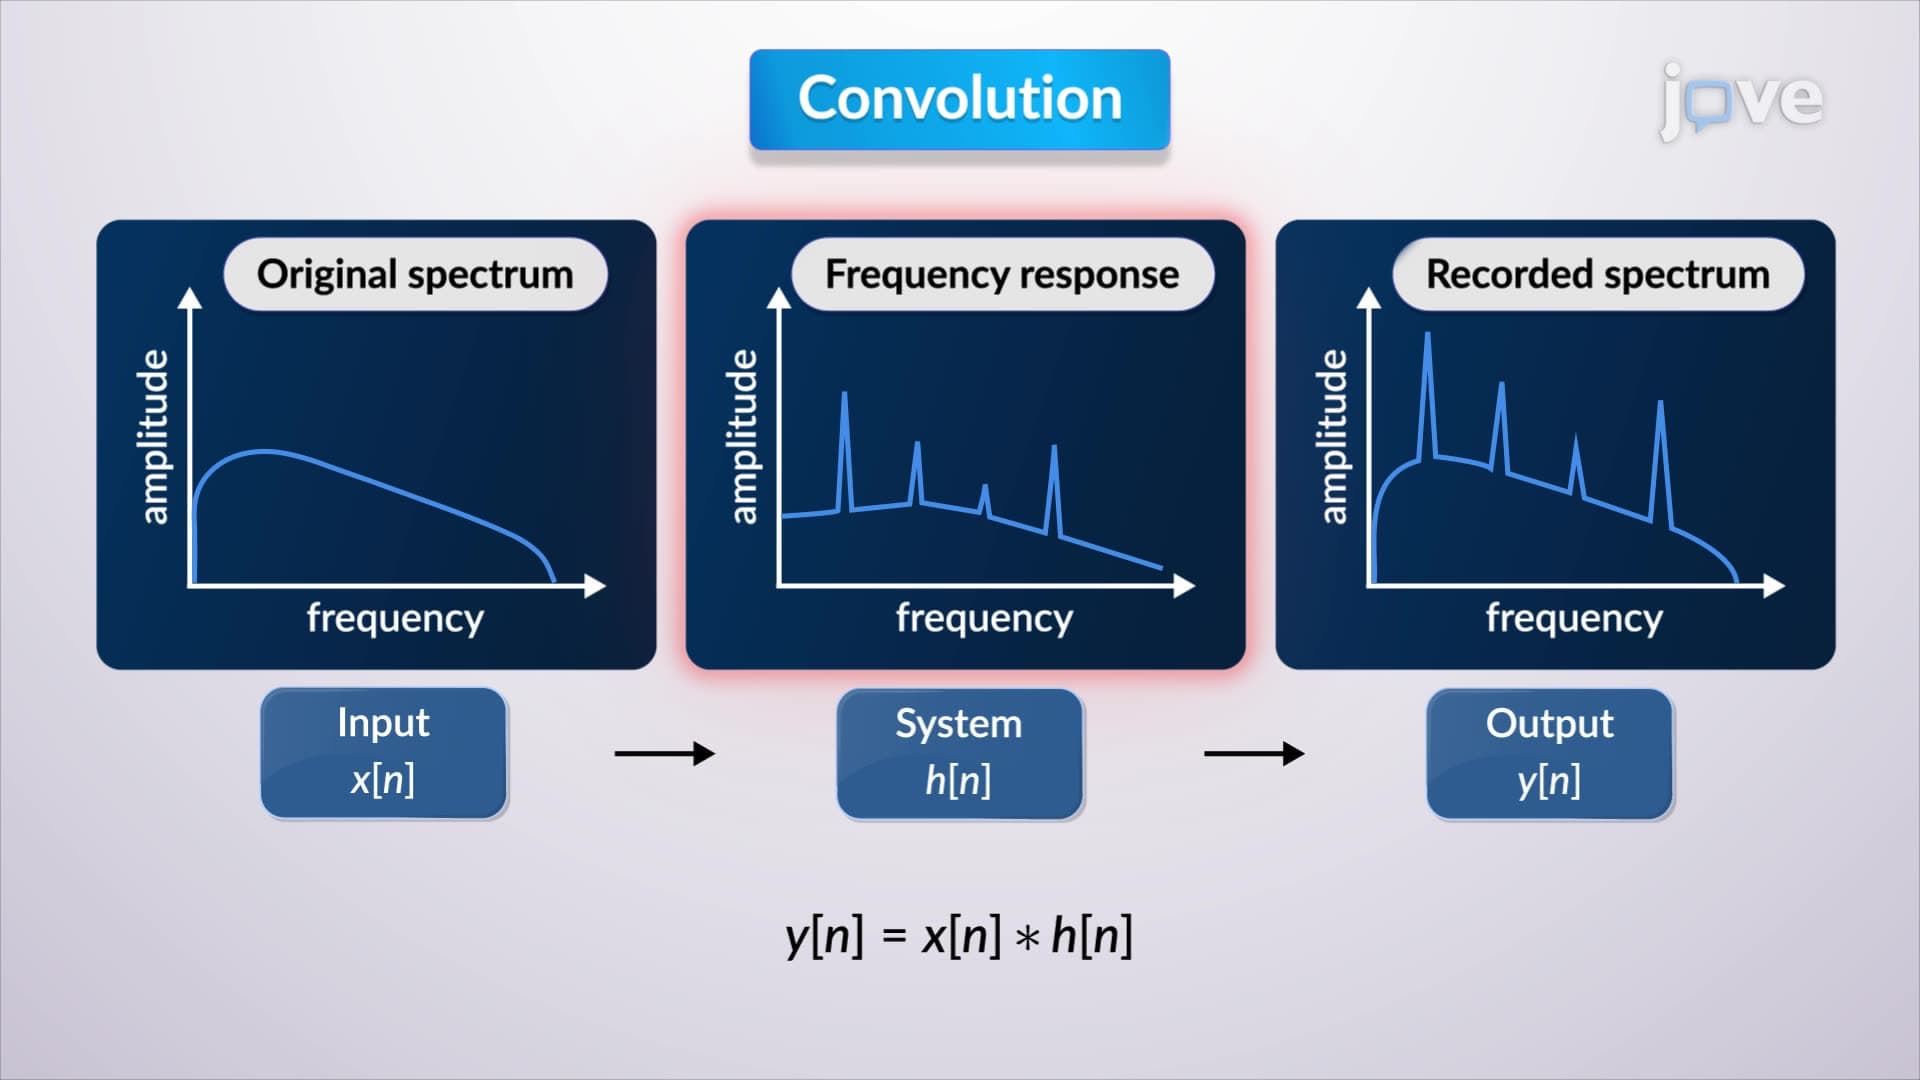
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:19
Expected Frequencies in Goodness-of-Fit Tests
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:00
Detection of Gross Error: The Q Test