Related Experiment Video
Updated: Jun 23, 2026


Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Robust dynamic sliding-mode control using adaptive RENN for magnetic levitation system
Faa-Jeng Lin1, Syuan-Yi Chen, Kuo-Kai Shyu
1Department of Electrical Engineering, National Central University, Jhong-Li, Taoyuan 320, Taiwan. linfj@ee.ncu.edu.tw

Abstract:
In this paper, a robust dynamic sliding mode control system (RDSMC) using a recurrent Elman neural network (RENN) is proposed to control the position of a levitated object of a magnetic levitation system considering the uncertainties. First, a dynamic model of the magnetic levitation system is derived. Then, a proportional-integral-derivative (PID)-type sliding-mode control system (SMC) is adopted for tracking of the reference trajectories. Moreover, a new PID-type dynamic sliding-mode control system (DSMC) is proposed to reduce the chattering phenomenon. However, due to the hardware being limited and the uncertainty bound being unknown of the switching function for the DSMC, an RDSMC is proposed to improve the control performance and further increase the robustness of the magnetic levitation system. In the RDSMC, an RENN estimator is used to estimate an unknown nonlinear function of lumped uncertainty online and replace the switching function in the hitting control of the DSMC directly. The adaptive learning algorithms that trained the parameters of the RENN online are derived using Lyapunov stability theorem. Furthermore, a robust compensator is proposed to confront the uncertainties including approximation error, optimal parameter vectors, and higher order terms in Taylor series. Finally, some experimental results of tracking the various periodic trajectories demonstrate the validity of the proposed RDSMC for practical applications.
Related Concept Videos
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:18
Magnetic Force
The magnetic force acting on a moving charge...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
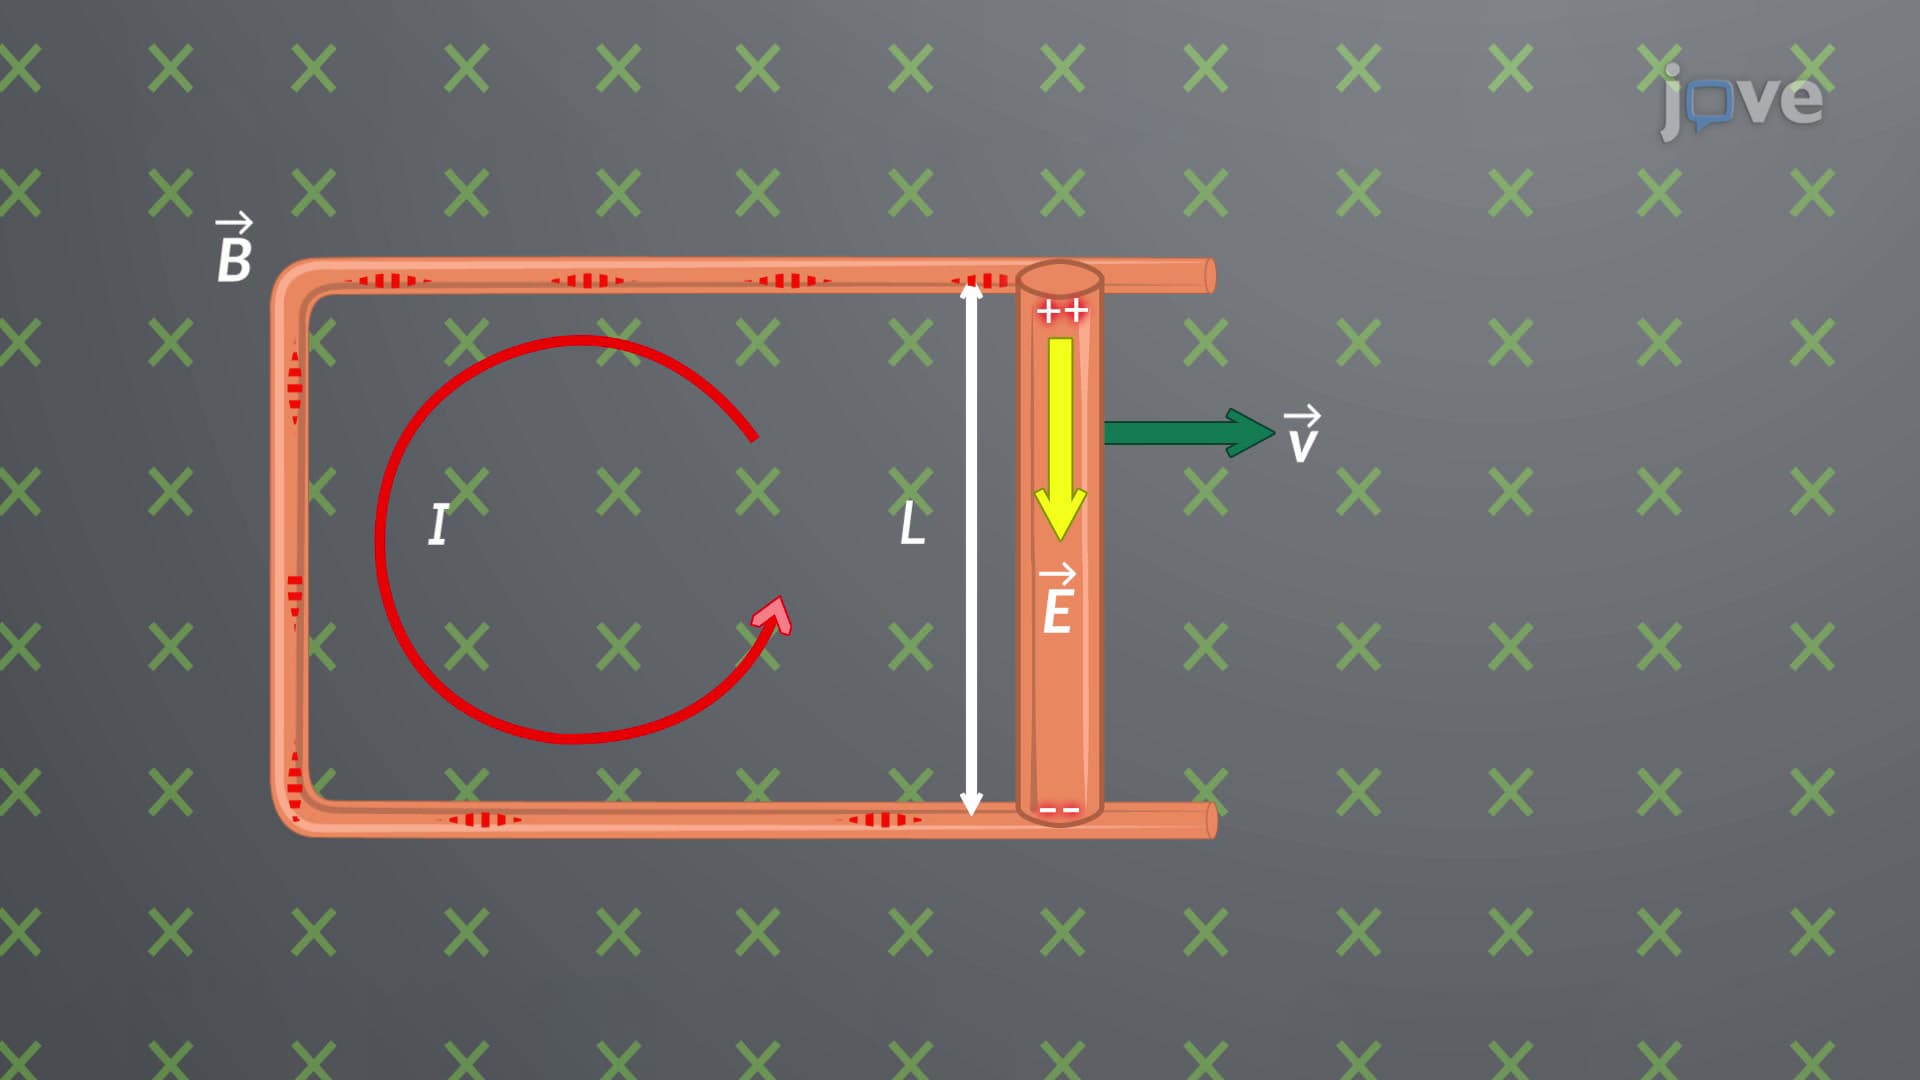 01:22
Motional Emf