CYCLOPS: A mobile robotic platform for testing and validating image processing and autonomous navigation algorithms in support of artificial vision prostheses
Related Experiment Video
Updated: Jun 21, 2026
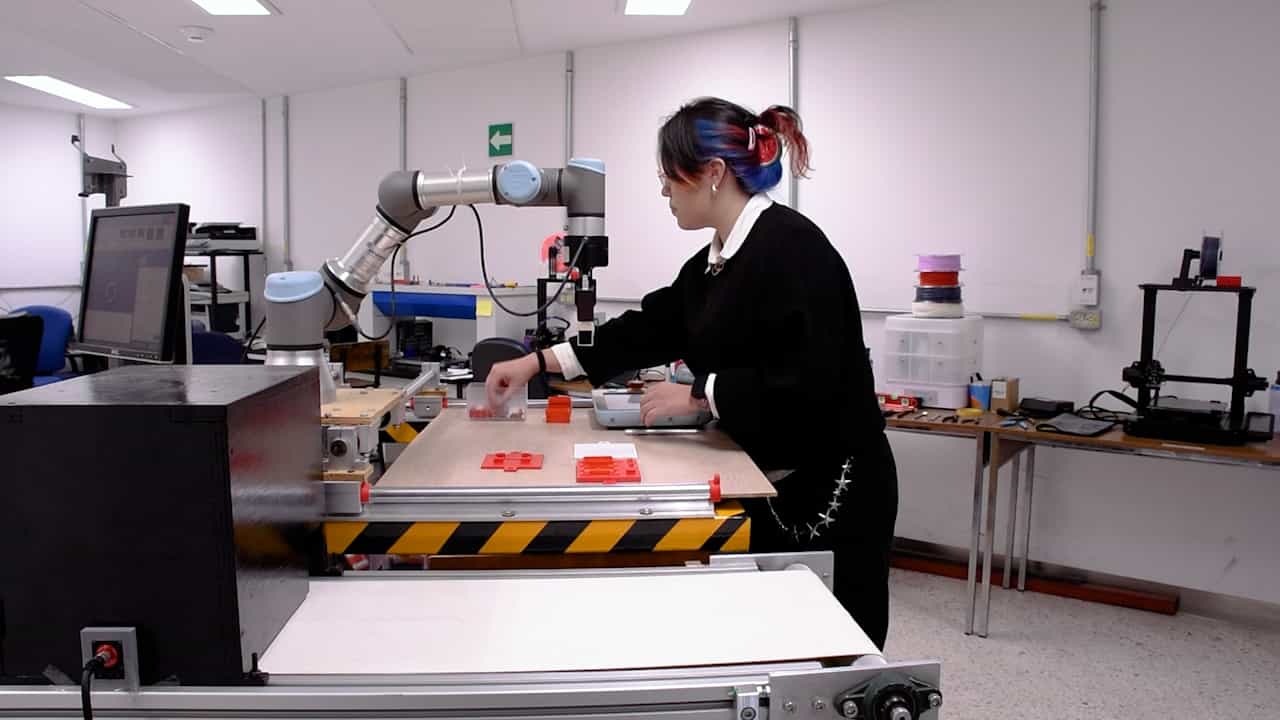
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Wolfgang Fink1, Mark A Tarbell
1California Institute of Technology, Pasadena, 91125, USA. wfink@autonomy.caltech.edu

Abstract:
While artificial vision prostheses are quickly becoming a reality, actual testing time with visual prosthesis carriers is at a premium. Moreover, it is helpful to have a more realistic functional approximation of a blind subject. Instead of a normal subject with a healthy retina looking at a low-resolution (pixelated) image on a computer monitor or head-mounted display, a more realistic approximation is achieved by employing a subject-independent mobile robotic platform that uses a pixelated view as its sole visual input for navigation purposes. We introduce CYCLOPS: an AWD, remote controllable, mobile robotic platform that serves as a testbed for real-time image processing and autonomous navigation systems for the purpose of enhancing the visual experience afforded by visual prosthesis carriers. Complete with wireless Internet connectivity and a fully articulated digital camera with wireless video link, CYCLOPS supports both interactive tele-commanding via joystick, and autonomous self-commanding. Due to its onboard computing capabilities and extended battery life, CYCLOPS can perform complex and numerically intensive calculations, such as image processing and autonomous navigation algorithms, in addition to interfacing to additional sensors. Its Internet connectivity renders CYCLOPS a worldwide accessible testbed for researchers in the field of artificial vision systems. CYCLOPS enables subject-independent evaluation and validation of image processing and autonomous navigation systems with respect to the utility and efficiency of supporting and enhancing visual prostheses, while potentially reducing to a necessary minimum the need for valuable testing time with actual visual prosthesis carriers.