Related Experiment Videos
On passivity and passification of stochastic fuzzy systems with delays: the discrete-time case
Jinling Liang1, Zidong Wang, Xiaohui Liu
1Department of Mathematics, Southeast University, Nanjing 210096, China. jinlliang@gmail.com

Abstract:
Takagi-Sugeno (T-S) fuzzy models, which are usually represented by a set of linear submodels, can be used to describe or approximate any complex nonlinear systems by fuzzily blending these subsystems, and so, significant research efforts have been devoted to the analysis of such models. This paper is concerned with the passivity and passification problems of the stochastic discrete-time T-S fuzzy systems with delay. We first propose the definition of passivity in the sense of expectation. Then, by utilizing the Lyapunov functional method, the stochastic analysis combined with the matrix inequality techniques, a sufficient condition in terms of linear matrix inequalities is presented, ensuring the passivity performance of the T-S fuzzy models. Finally, based on this criterion, state feedback controller is designed, and several criteria are obtained to make the closed-loop system passive in the sense of expectation. The results acquired in this paper are delay dependent in the sense that they depend on not only the lower bound but also the upper bound of the time-varying delay. Numerical examples are also provided to demonstrate the effectiveness and feasibility of our criteria.
Related Concept Videos
 01:18
Second Order systems II
If ζ...
 01:31
Classification of Systems-II
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
First Order Systems
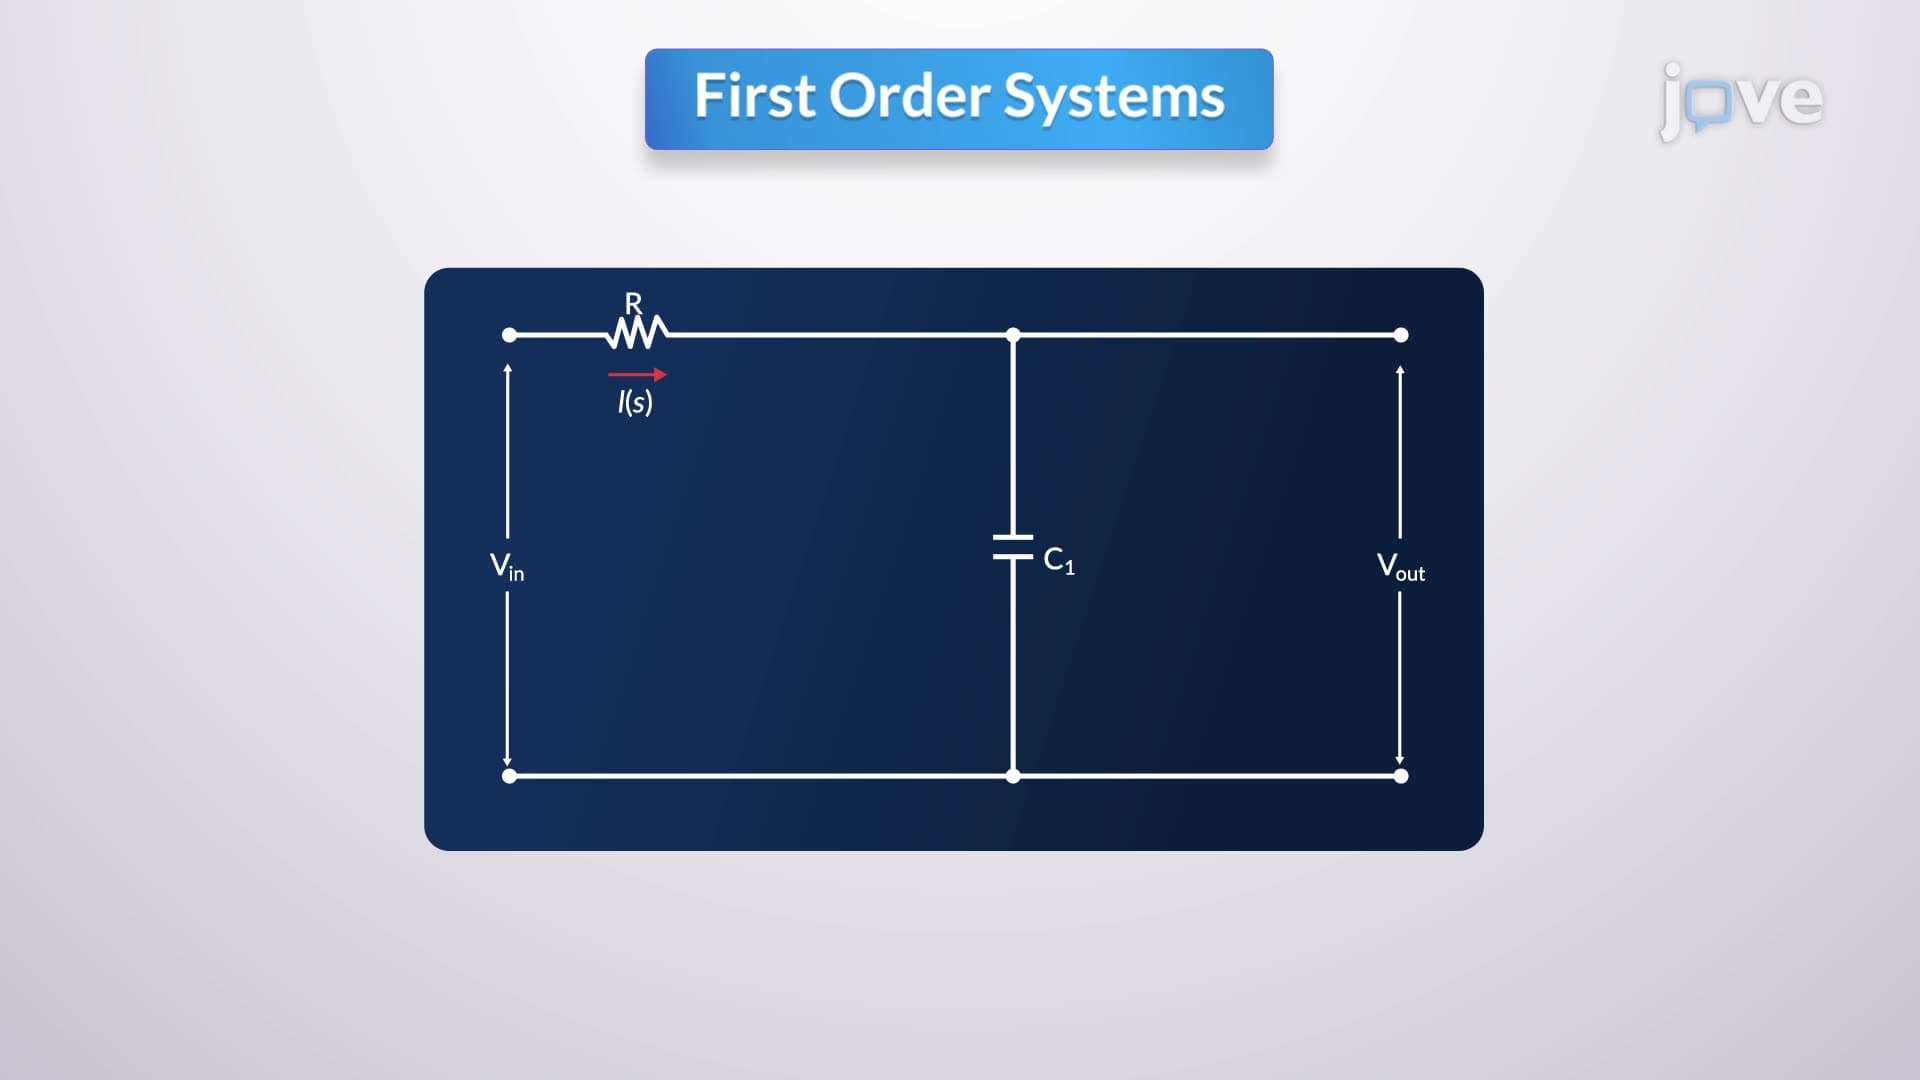
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...