Related Experiment Video
Updated: Jun 18, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Modeling of the steady-state disturbance term in isometric force using components of the power spectrum
Joseph P Stitt1, Karl M Newell
1Materials Research Institute, The Pennsylvania State University, University Park, PA 16802, USA. JStitt@psu.edu

Abstract:
The analysis of isometric force may provide early detection of certain types of neuropathology such as Parkinson's disease. Our long term goal is to determine if there are detectable differences between model parameters of healthy and unhealthy individuals. The participants in this study were twenty four healthy adults ages 18 through 24, both male and female. The experiments involved the participants exerting isometric force over a range from 5% to 65% of maximal voluntary contraction. The analysis involved the steady-state portion of the recorded time series. Five components of the power spectral density were extracted and used as features to classify the participants into two categories: (1) high strength; (2) low strength based upon the values of the five extracted spectral components. Even though the participants were all healthy and young the features exhibited enough differences to successfully classify 80% of the subjects into the proper category. This finding suggests that the 5-component model should be capable of discriminating between healthy individuals and those who are in an early stage of neurodegenerative disease.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:07
Damped Oscillations
Although friction and other non-conservative...
 01:06
Forced Oscillations
 01:18
Second Order systems II
If ζ...
 01:21
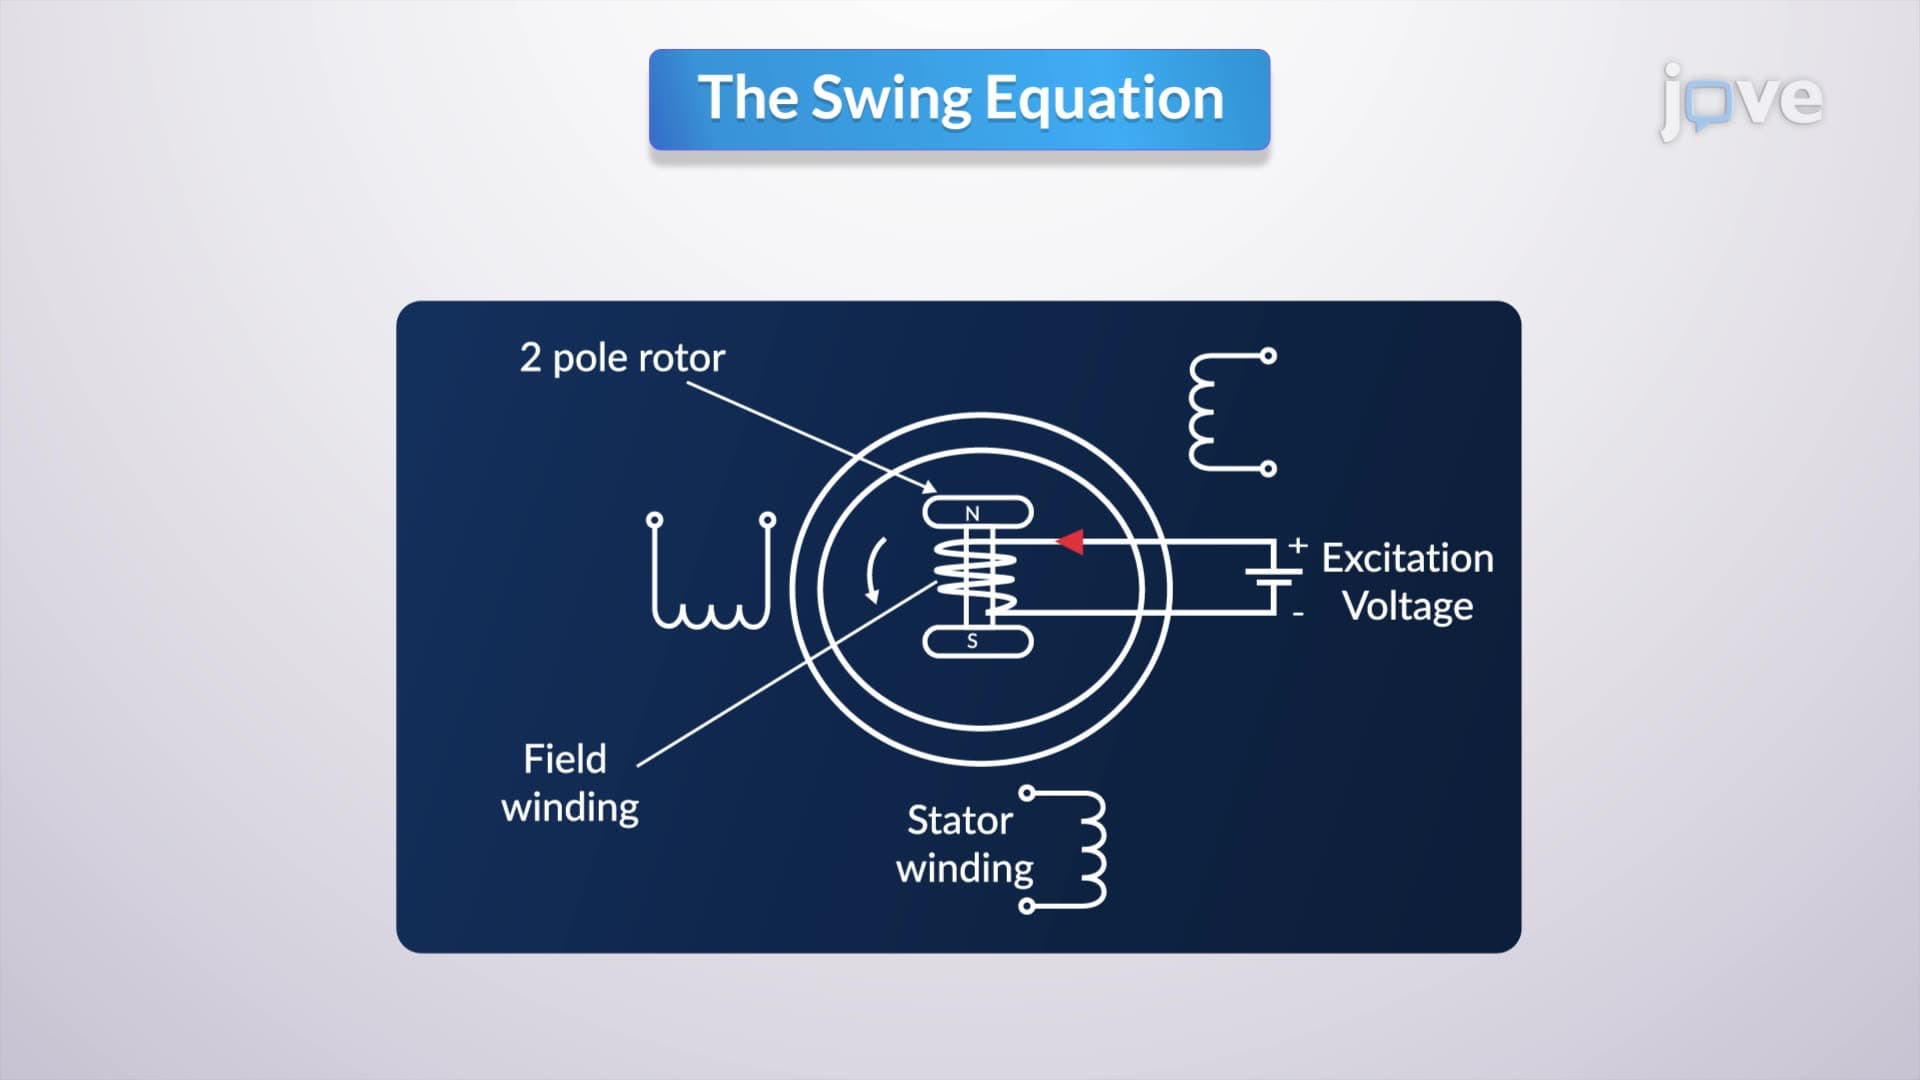
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...
 01:23
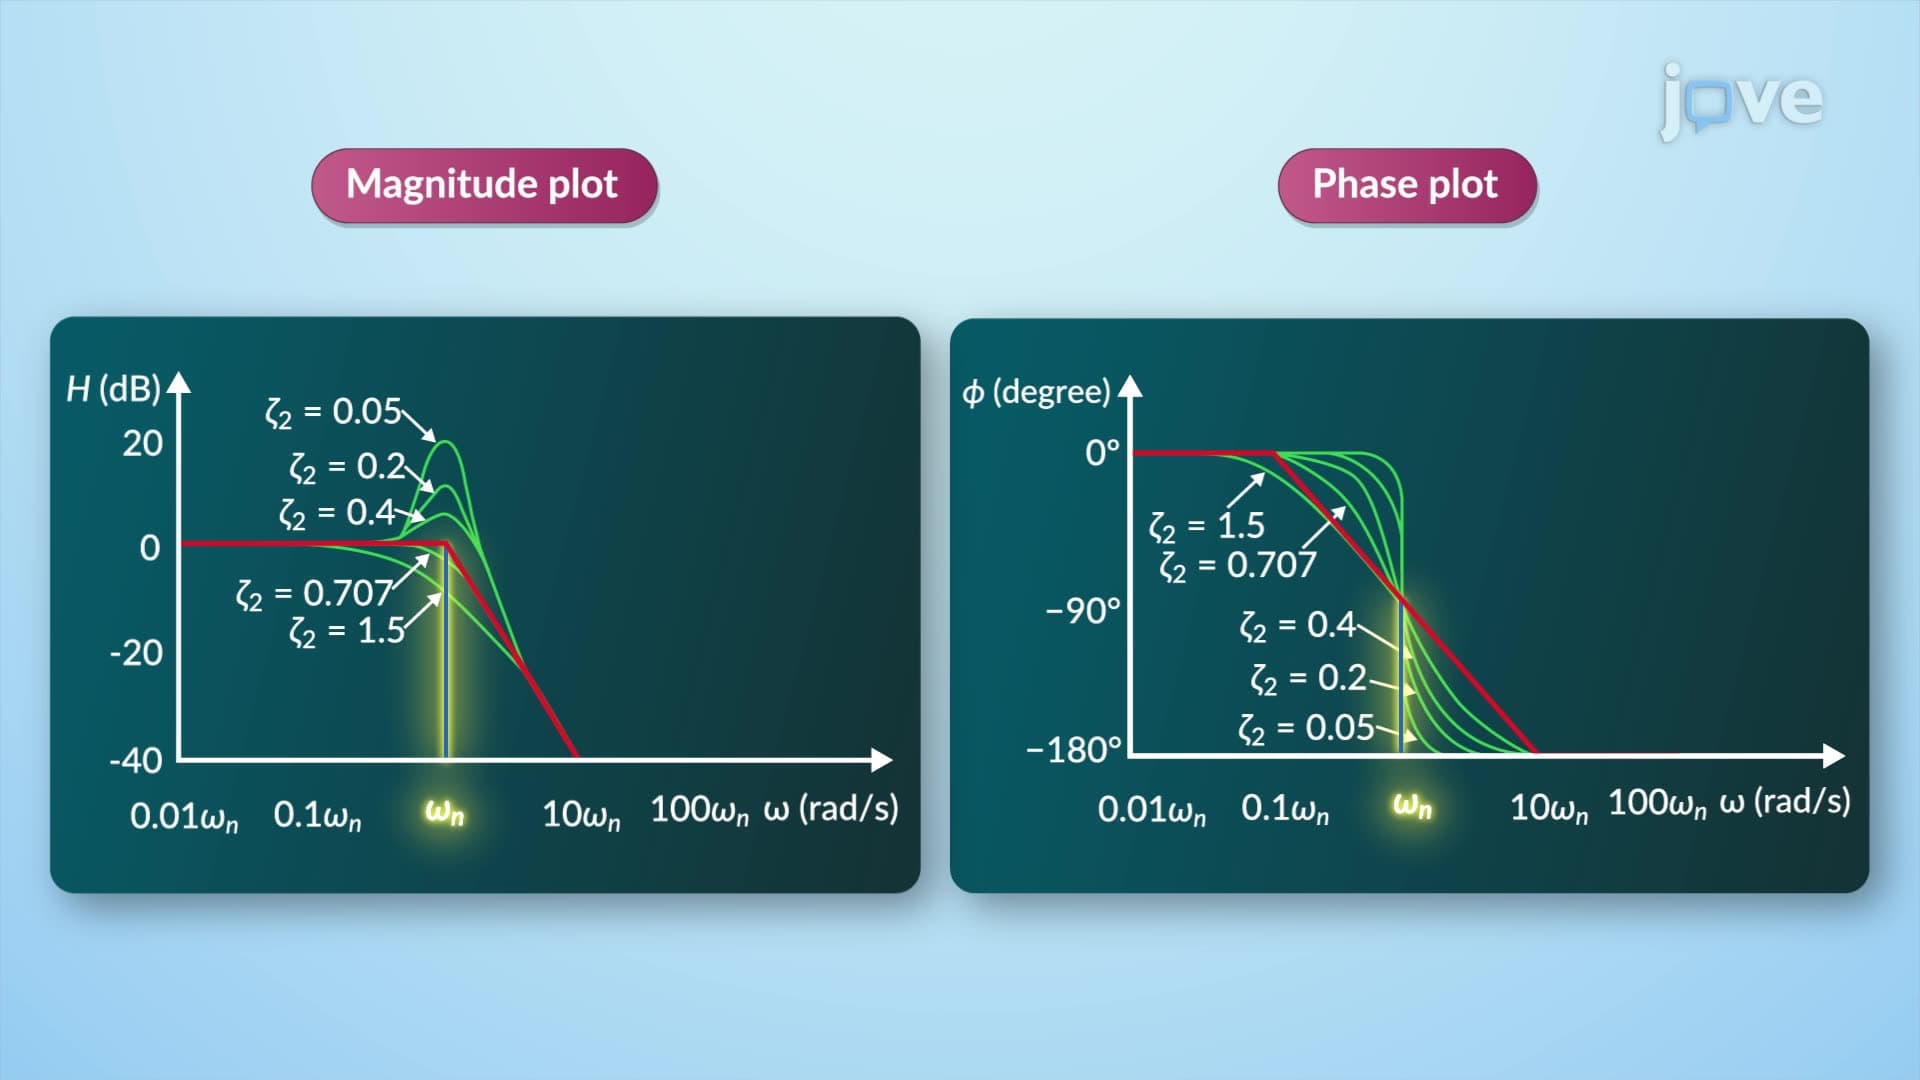
Transfer function and Bode Plots-II