Related Experiment Video
Updated: Jun 17, 2026
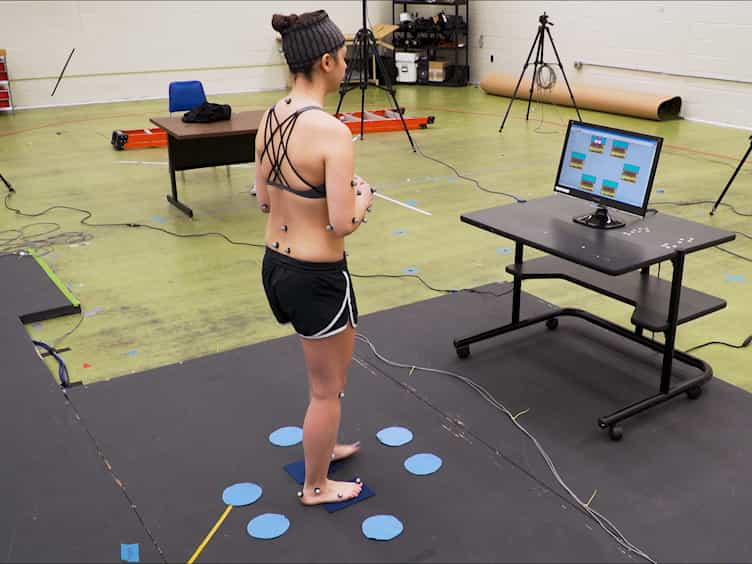

The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
Diminishing the effects of reduced frequency of knowledge of results on generalized motor program learning
1The University of Tennessee, Knoxville.

Abstract:
Several recent studies have shown that, compared with presenting knowledge of results (KR) on every practice trial, withholding KR on some practice trials enhances the learning of generalized motor programs (GMPs; Wulf, Lee, & Schmidt, 1994; Wulf & Schmidt, 1989; Wulf, Schmidt, & Deubel, 1993). In this study, whether this effect may result from an uncertainty on the part of participants about when KR is to be presented was determined by examining the GMP learning of two 67% relative-frequency KR groups-one that received advance information regarding the delivery of each KR (67% AKR) during practice trials and another that received no advance information (67% KR)-as well as that of a 100% KR group. The task required participants to produce 3 movement patterns that shared the same relative and absolute timing and relative amplitude but differed in terms of absolute amplitude. KR was provided by displaying the root-mean-square error (RMSE) score and by graphically superimposing the participant-produced pattern on that of the goal movement. The results revealed no group differences in measures of GMP development or parameterization effectiveness during practice and no-KR retention. However, during no-KR transfer with a novel absolute amplitude, the 67% KR group demonstrated a more accurate and stable GMP than the 67% AKR and 100% KR groups. Possible explanations for why advance knowledge about KR delivery diminishes GMP development are discussed.
Related Concept Videos
 01:24
Generalization, Discrimination, and Extinction
Generalization occurs when a behavior reinforced in one context is performed in similar situations. For instance, a student who studies diligently for calculus and receives excellent grades might apply the same study habits to psychology and history, expecting similar results. Generalization shows how learning in one setting can influence behavior in...
 01:22
Muscle Stimulation Frequency
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...