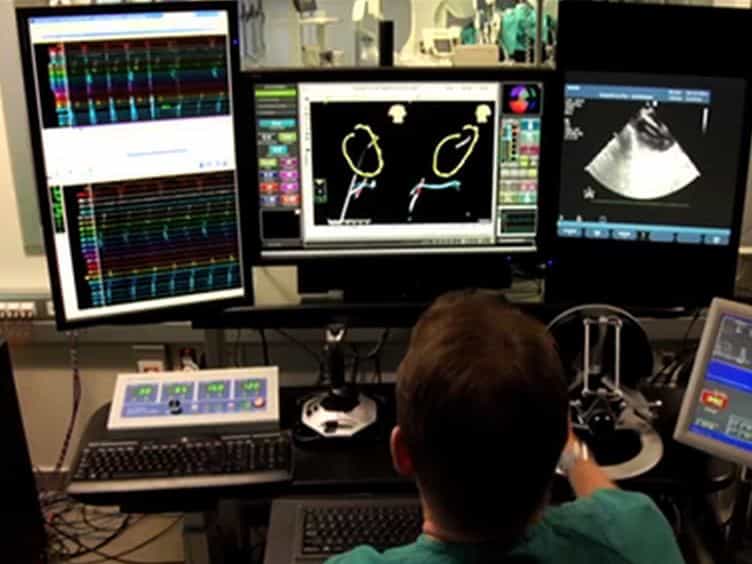
Design and fabrication of a robotic mechanism for remote steering and positioning of interventional devices
Related Experiment Video
Updated: Jun 16, 2026
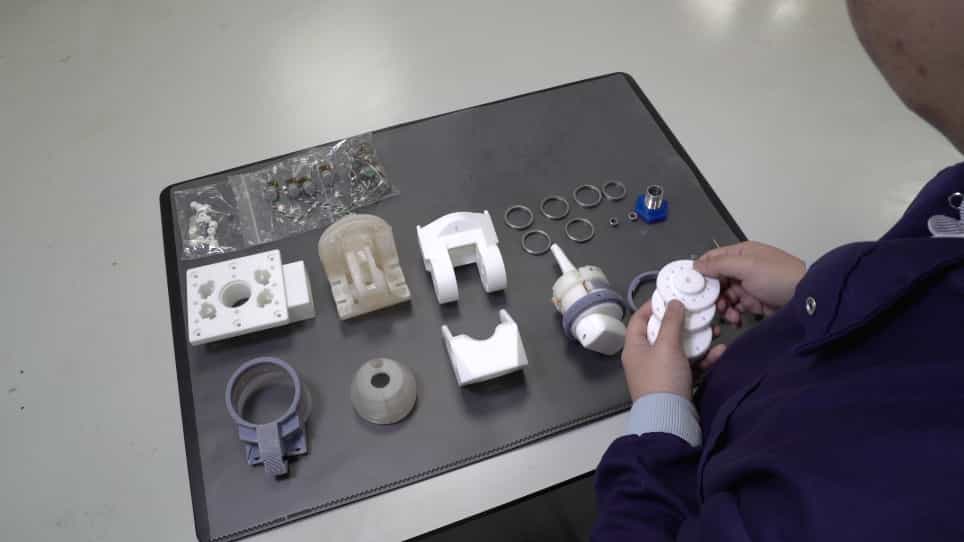
Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Govindarajan Srimathveeravalli1, Thenkurussi Kesavadas, Xinyan Li
1Department of Mechanical and Aerospace Engineering, State University of New York, Buffalo, NY 14260, USA. gks2@buffalo.edu

Background:
Recently, robotic systems have been introduced as a method for assisting endovascular interventional procedures. A few commercial and research solutions are available. In a survey it was found that none of the current systems satisfied all basic design requirements set forth for a good robot-assisted therapy platform.
Methods:
A human motion analysis study was performed to identify design specifications for safe motion and force limits for endovascular surgery. Based on design requirements from surveyed systems and motion analysis, a new, teleoperated, haptically enabled system called System for Endovascular Teleoperated Access (SETA) was constructed. SETA is capable of simultaneously manipulating any guidewire and catheter in the range of 0.014-0.13 inches.
Results:
SETA's slave was evaluated for precision positioning, using in vitro vascular phantoms. It was also evaluated by a cohort of neurovascular surgeons and fellows (n = 8), using the VIST vascular simulator. A qualitative survey of the participants and a quantitative analysis of metrics procedure time and contrast used found that SETA was equivalent to manual intervention on this platform.
Conclusions:
SETA provided good performance in the in vitro studies, and will soon be evaluated in a series of in vivo animal model studies.