Look to Move and Grasp: A Gaze-Only VR Framework for Robot Teleoperation
Related Experiment Video
Updated: Oct 31, 2026
Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011

Abstract:
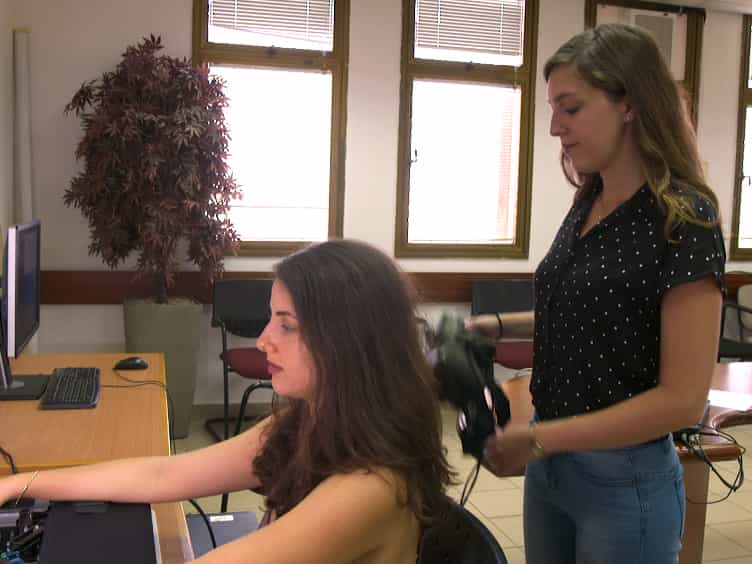
While robots hold immense potential, conventional teleoperation interfaces predominantly rely on manual input, creating substantial barriers for users who cannot readily use their hands. Gaze interaction in virtual reality (VR) offers a natural, hands-free alternative that eliminates the need for physical movements. In this work, we propose a gaze-only VR teleoperation framework designed to provide a hands-free interaction paradigm. The framework incorporates three gaze-based methods for robot locomotion and two methods for robot manipulation. To systematically evaluate the usability, interaction efficiency, and user experience of the proposed approach, we conducted a user study. The results demonstrate that the gaze-driven methods enable effective control of both robot locomotion and manipulation, exhibiting favorable ease of use and feasibility in teleoperation tasks. This study validates the feasibility of gaze-driven robotic teleoperation within VR environments, providing a promising hands-free solution that contributes to the development of more efficient forms of human-robot interaction.