Related Experiment Video
Updated: Oct 29, 2026
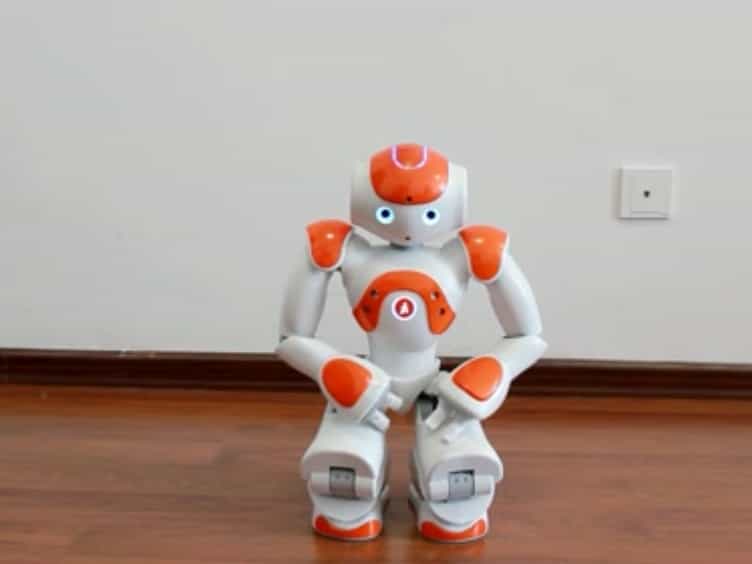
SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
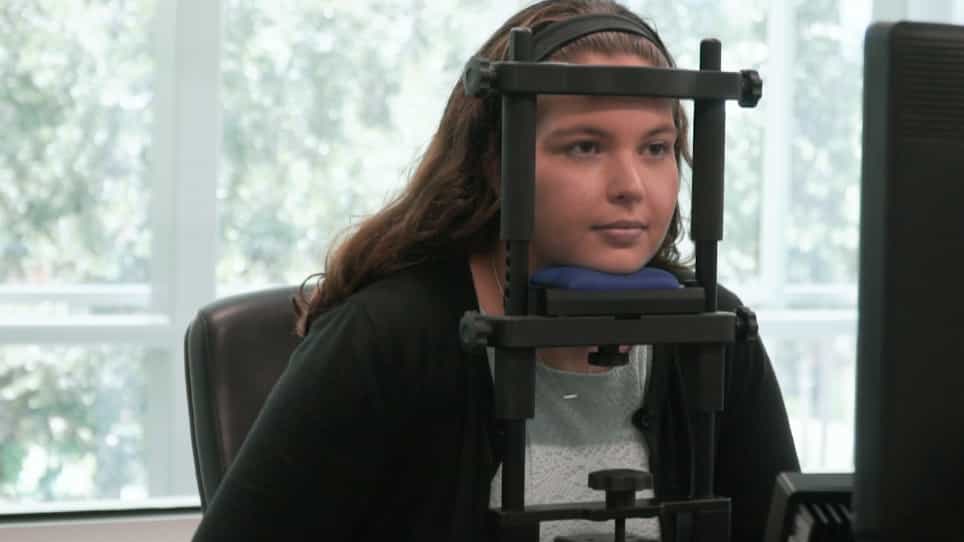
Semantically enhanced eye-tracking controls in human-robot interaction: a comparison study
Ruitong Tian1, Hengxu You1, Fang Xu1
1Department of Civil Engineering, Engineering School of Sustainable Infrastructure & Environment, University of Florida, Gainesville, FL, USA.

Abstract:
Operators controlling robotic systems for sequential manipulation tasks present cognitive loads that vary with how they specify intent to the robot. Limited evidence exists on how semantically mediated voice and gaze interfaces differ in operator performance, visual attention, and perceived workload. This study presents findings of a within-subjects experiment (N = 30) with three control modalities (hand gesture, voice, and eye-tracking). Eye-tracking produced shorter, more consistent completion times (M = 17.10 s, SD = 3.95), indicating stable and efficient performance. Voice Control was associated with more structured but variable action ordering and higher NASA-TLX Mental Demand and Effort scores, consistent with demands from spatial-to-verbal intention translation. Gaze metrics indicated distinct attentional strategies: eye-tracking showed lower spatial entropy and fewer fixations, while voice control exhibited broader workspace scanning. These findings suggest an association between attention-control channel coupling and cognitive resource allocation in semantically enhanced human-robot interaction, informing ergonomic hands-free interface design.